diff --git a/.github/workflows/release.yml b/.github/workflows/release.yml
index 7bc123bea..b8fb01326 100644
--- a/.github/workflows/release.yml
+++ b/.github/workflows/release.yml
@@ -27,6 +27,7 @@ jobs:
app-name: lightcraft
app-title: LightCraft
craft-fonts-ref: a71c20e30af613287c504f7e685ca8fad77752bc
+ web-craft-fonts: true
version: ${{ inputs.version }}
secrets:
APPLE_CERTIFICATE: ${{ secrets.APPLE_CERTIFICATE }}
diff --git a/.github/workflows/sonarcloud.yml b/.github/workflows/sonarcloud.yml
new file mode 100644
index 000000000..ecee45a6d
--- /dev/null
+++ b/.github/workflows/sonarcloud.yml
@@ -0,0 +1,20 @@
+name: SonarCloud
+
+on:
+ push:
+ branches: [main]
+ pull_request:
+ types: [opened, synchronize, reopened]
+
+permissions:
+ contents: read
+
+concurrency:
+ group: sonarcloud-${{ github.ref }}
+ cancel-in-progress: true
+
+jobs:
+ sonarcloud:
+ # Tracked at @main so org-wide CI improvements propagate without PR churn.
+ uses: storytold/craft-common-actions/.github/workflows/sonarcloud.yml@main
+ secrets: inherit
diff --git a/AGENTS.md b/AGENTS.md
index c9f54b71d..959d2808f 100644
--- a/AGENTS.md
+++ b/AGENTS.md
@@ -62,6 +62,7 @@ of it. Full standard: `../craftrules/standards/never-crash.md`
- **Layering** (`plan/architecture.md` §3, enforced by `cargo xtask layers`): nothing below L5 depends on egui/eframe/winit/rfd.
- **Everything is a command** (`crates/engine`): id, label, menu path, shortcut, params, enabled(), run(). UI, CLI, control channel and MCP all dispatch by id. Every slider is a `develop` control spec.
- **Resolution independence:** settings use normalized image coordinates and relative radii; previews and exports must match.
+- **Time goes through `chrono`** (workspace dependency). Never hand-roll UTC/calendar conversion (days-to-date algorithms, leap-year math); a crate owns only its output format string. The one exception is range extension: past the years chrono can represent, shift the date by whole 400-year Gregorian cycles (146,097 days, after which the calendar repeats), let chrono compute the month and day, and add the cycles back to the year (splitting seconds into hours, minutes and seconds is plain arithmetic).
- **Quality gates** before every commit: `cargo xtask ci` (fmt, clippy -D warnings, tests, layers, assets, wasm).
- **Commits:** one task id per commit (`M2.3: local Laplacian highlights/shadows`). Only green states. End messages with the attribution line required by the environment.
diff --git a/CLAUDE.md b/CLAUDE.md
index 00a2314aa..d2d538d65 100644
--- a/CLAUDE.md
+++ b/CLAUDE.md
@@ -67,6 +67,7 @@ of it. Full standard: `../craftrules/standards/never-crash.md`
label, cancel)` for its whole run. It adopts the cancel flag the job already checks (`Cancel::Flag`), or uses
`Cancel::No` when the job can't stop. No progress window, panel or progress toast of its own; its tests assert the row.
- **Resolution independence:** settings use normalized image coordinates and relative radii; previews and exports must match.
+- **Time goes through `chrono`** (workspace dependency). Never hand-roll UTC/calendar conversion (days-to-date algorithms, leap-year math); a crate owns only its output format string. The one exception is range extension: past the years chrono can represent, shift the date by whole 400-year Gregorian cycles (146,097 days, after which the calendar repeats), let chrono compute the month and day, and add the cycles back to the year (splitting seconds into hours, minutes and seconds is plain arithmetic).
- **Quality gates** before every commit: `cargo xtask ci` (fmt, clippy -D warnings, tests, layers, assets, wasm).
- **Commits:** one task id per commit (`M2.3: local Laplacian highlights/shadows`). Only green states. End messages with the attribution line required by the environment.
diff --git a/Cargo.lock b/Cargo.lock
index a49ec38db..216fdeca4 100644
--- a/Cargo.lock
+++ b/Cargo.lock
@@ -936,6 +936,15 @@ dependencies = [
"zeroize",
]
+[[package]]
+name = "chrono"
+version = "0.4.45"
+source = "registry+https://github.com/rust-lang/crates.io-index"
+checksum = "1aa79e62e7697b8e29b513a68abacf485adcd1fe8284a4316c5ae868e6633327"
+dependencies = [
+ "num-traits",
+]
+
[[package]]
name = "cipher"
version = "0.4.4"
@@ -3078,8 +3087,9 @@ dependencies = [
[[package]]
name = "lightcraft"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
+ "chrono",
"eframe",
"egui",
"lightcraft-codecs",
@@ -3103,8 +3113,9 @@ dependencies = [
[[package]]
name = "lightcraft-catalog"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
+ "chrono",
"crc32fast",
"lightcraft-develop",
"lightcraft-geom",
@@ -3120,7 +3131,7 @@ dependencies = [
[[package]]
name = "lightcraft-cli"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"dhat",
"lightcraft-codecs",
@@ -3136,7 +3147,7 @@ dependencies = [
[[package]]
name = "lightcraft-codecs"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"avif-serialize",
"bytemuck",
@@ -3167,7 +3178,7 @@ dependencies = [
[[package]]
name = "lightcraft-color"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-geom",
"proptest",
@@ -3176,7 +3187,7 @@ dependencies = [
[[package]]
name = "lightcraft-denoise"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"faer-core",
"lightcraft-denoise-core",
@@ -3193,7 +3204,7 @@ dependencies = [
[[package]]
name = "lightcraft-denoise-core"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-raster",
"miniz_oxide 0.8.9",
@@ -3208,7 +3219,7 @@ dependencies = [
[[package]]
name = "lightcraft-develop"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-color",
"lightcraft-geom",
@@ -3220,9 +3231,10 @@ dependencies = [
[[package]]
name = "lightcraft-engine"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"ab_glyph",
+ "chrono",
"craft-docpath",
"harfrust",
"jxl-oxide",
@@ -3263,7 +3275,7 @@ dependencies = [
[[package]]
name = "lightcraft-faces"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-testkit",
"matrixmultiply",
@@ -3278,7 +3290,7 @@ dependencies = [
[[package]]
name = "lightcraft-fetch"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"log",
"rustls",
@@ -3289,7 +3301,7 @@ dependencies = [
[[package]]
name = "lightcraft-geocode"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"miniz_oxide 0.8.9",
"serde",
@@ -3297,7 +3309,7 @@ dependencies = [
[[package]]
name = "lightcraft-geom"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"proptest",
"serde",
@@ -3305,7 +3317,7 @@ dependencies = [
[[package]]
name = "lightcraft-gpu"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"bytemuck",
"lightcraft-color",
@@ -3325,7 +3337,7 @@ dependencies = [
[[package]]
name = "lightcraft-heif"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"heic-rs",
"rayon",
@@ -3333,14 +3345,14 @@ dependencies = [
[[package]]
name = "lightcraft-inpaint"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"rayon",
]
[[package]]
name = "lightcraft-lensdb"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-develop",
"lightcraft-geom",
@@ -3349,7 +3361,7 @@ dependencies = [
[[package]]
name = "lightcraft-mcp"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-codecs",
"lightcraft-engine",
@@ -3360,7 +3372,7 @@ dependencies = [
[[package]]
name = "lightcraft-merge"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-codecs",
"lightcraft-color",
@@ -3376,8 +3388,9 @@ dependencies = [
[[package]]
name = "lightcraft-meta"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
+ "chrono",
"lightcraft-geom",
"lightcraft-tiff",
"proptest",
@@ -3388,7 +3401,7 @@ dependencies = [
[[package]]
name = "lightcraft-pipeline"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"image",
"lightcraft-color",
@@ -3406,7 +3419,7 @@ dependencies = [
[[package]]
name = "lightcraft-preview"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"jpeg-encoder",
"lightcraft-raster",
@@ -3418,7 +3431,7 @@ dependencies = [
[[package]]
name = "lightcraft-raster"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"libc",
"lightcraft-color",
@@ -3430,7 +3443,7 @@ dependencies = [
[[package]]
name = "lightcraft-raw"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"dhat",
"jpeg-encoder",
@@ -3454,7 +3467,7 @@ dependencies = [
[[package]]
name = "lightcraft-scenes"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"image",
"lightcraft-color",
@@ -3465,7 +3478,7 @@ dependencies = [
[[package]]
name = "lightcraft-segment"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"candle-core",
"candle-nn",
@@ -3479,7 +3492,7 @@ dependencies = [
[[package]]
name = "lightcraft-slideshow"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"lightcraft-raster",
"serde",
@@ -3488,15 +3501,15 @@ dependencies = [
[[package]]
name = "lightcraft-sysmem"
-version = "0.10.0"
+version = "0.11.0"
[[package]]
name = "lightcraft-testkit"
-version = "0.10.0"
+version = "0.11.0"
[[package]]
name = "lightcraft-tiff"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"proptest",
"serde",
@@ -3505,7 +3518,7 @@ dependencies = [
[[package]]
name = "lightcraft-ui-egui"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"craft-ui",
"egui",
@@ -3534,7 +3547,7 @@ dependencies = [
[[package]]
name = "lightcraft-web"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"crc32fast",
"eframe",
@@ -7004,7 +7017,7 @@ checksum = "e450f9b2ed1dff33c94c12589a87338689467b9c4f5d8a5710bd09a847d2c8a7"
[[package]]
name = "xtask"
-version = "0.10.0"
+version = "0.11.0"
dependencies = [
"brotli",
"flate2",
diff --git a/Cargo.toml b/Cargo.toml
index c76095d2d..0a0d78e5f 100644
--- a/Cargo.toml
+++ b/Cargo.toml
@@ -3,7 +3,7 @@ resolver = "3"
members = ["crates/*", "apps/*", "xtask"]
[workspace.package]
-version = "0.10.0"
+version = "0.11.0"
edition = "2024"
license = "MIT OR Apache-2.0"
rust-version = "1.90"
@@ -49,6 +49,8 @@ sha2 = "0.10"
serde = { version = "1", features = ["derive", "rc"] }
serde_json = { version = "1", features = ["float_roundtrip"] }
log = "0.4"
+# All date/time conversion goes through chrono (no hand-rolled calendar code beyond the 400-year range extension; AGENTS.md).
+chrono = { version = "0.4.45", default-features = false, features = ["std"] }
rayon = "1"
proptest = "1"
bytemuck = { version = "1", features = ["derive"] }
diff --git a/README.md b/README.md
index 42b164d6c..15f8a7d83 100644
--- a/README.md
+++ b/README.md
@@ -14,7 +14,8 @@
English ·
- 简体中文
+ 简体中文 ·
+ 繁體中文
@@ -212,7 +213,8 @@ Then tone it with Color Grading for selenium, sepia or split-tone prints.
A library that stays out of your way: **All Photos**, **Recently Added**, **Picks**, **By Date**, **Albums** nested in
**Folders**, and **Recently Deleted**. Rate with 0 –5 , flag with P / X /
U , colour-label with 6 –9 . Search understands fields:
-`rating:>3 flag:pick iso:>800 camera:x2 date:2026-04 keyword:mountains`. Every view sorts by capture date,
+`rating:>3 flag:pick iso:>800 camera:x2 date:2026-04 keyword:mountains person:"Jane Doe"`; plain words also match
+the people named on faces, and quotes keep several words together. Every view sorts by capture date,
import date, edit date, name, rating, size or at random (a stable shuffle; View → Sort → Reshuffle for a new one). The justified **Photo Grid** and **Square Grid** views are virtualized,
so they stay smooth whether you have forty photos or forty thousand.
@@ -451,7 +453,7 @@ CRAFT_FONTS_DIR=../craft-fonts cargo run --release -p lightcraft
Without it LightCraft builds and runs the same, but Chinese and Japanese text have no glyphs. Fonts are never committed to this
repo — the standard for what goes there lives with it: see the [craft-fonts README](https://github.com/storytold/craft-fonts#readme).
-**Interface language:** **Edit → Language** (English, 简体中文, 繁體中文(台灣), 日本語, Português (Brasil), Español, Deutsch, Русский, Français, Українська, Polski, Čeština, Italiano, ქართული) or **Settings → General →
+**Interface language:** **Edit → Language** (English, 简体中文, 繁體中文(台灣), 日本語, Português (Brasil), Español, Deutsch, Русский, Français, Українська, Polski, Čeština, Italiano, ქართული, Svenska, Suomi, Bahasa Indonesia, Tiếng Việt) or **Settings → General →
Language**; the choice applies immediately and persists. See [docs/localization.md](docs/localization.md).
**Logs:** the desktop app writes its log to standard error and to `logs/lightcraft.log` in its settings folder
diff --git a/README.zh-hans.md b/README.zh-hans.md
index 58e1d627f..824913f14 100644
--- a/README.zh-hans.md
+++ b/README.zh-hans.md
@@ -14,7 +14,8 @@
English ·
- 简体中文
+ 简体中文 ·
+ 繁體中文
diff --git a/README.zh-hant.md b/README.zh-hant.md
new file mode 100644
index 000000000..a17505f3f
--- /dev/null
+++ b/README.zh-hant.md
@@ -0,0 +1,629 @@
+
+
+
+
+
+
+
+
+
+LightCraft
+
+Your photos. Your pixels. Your machine.
+
+
+ English ·
+ 简体中文 ·
+ 繁體中文
+
+
+
+ 照片庫與 raw 顯影;以淨室(clean-room)方式、用純 Rust 重新實作的開源 Adobe Lightroom。
+
+
+
+
+
+
+
+
+ getartcraft.com 上的 LightCraft ArtCraft ·
+ 所有 Crafting Apps
+
+
+
+ 安瑟·亞當斯,《提頓山脈與蛇河》(1942)。公眾領域,美國國家檔案館。於 LightCraft 中顯影。
+
+> [!NOTE]
+> **ArtCraft 是一個由各行各業的創作者組成的社群。** 數位藝術、生成藝術、音樂、
+> 遊戲 — 只要你在創作,你就是我們的一員。**[來 Discord 打聲招呼吧](https://discord.gg/artcraft)。**
+
+
+ 編輯 ·
+ 色彩分級 ·
+ 編輯前/後對比 ·
+ 遮色片 ·
+ 預設集 ·
+ 照片庫 ·
+ 代理與 MCP ·
+ 效能 ·
+ 功能狀態 ·
+ 快速開始 ·
+ 路線圖 ·
+ 下載 ·
+ Crafting Apps
+
+
+
+
+
+
+### ☀️ 光線
+**曝光、對比、亮部、陰影、白色色階、黑色色階**,搭配邊緣感知的局部色調映射(對對數亮度做引導式濾波)。
+把亮部拉到 −100,就能救回一片過曝的天空,而且不會出現用簡單曲線時常見的灰色光暈。
+
+### 🎨 色彩
+依**色溫**與**色調**調整**白平衡**(raw 用 K 值,JPEG 用相對值),附帶預設、自動,以及點一下就能中和的**滴管**。
+保護膚色的**自然飽和度**、**飽和度**、8 段式**混色器**(色相/飽和度/明度),以及附帶混合與平衡的
+三區**色彩分級**色輪。所有運算都在 OkLCh 這個現代感知色彩空間中完成。
+
+
+
+
+### ✨ 效果
+讓細節更細緻的**紋理**、讓中間調更有力的**清晰度**、**去朦朧**(暗通道先驗加引導式細化;
+推到負值可增添氛圍感)、裁切後附帶亮部優先、圓度與羽化的**暗角**,以及解析度無關、可調大小與粗糙度的
+底片**顆粒**。
+
+### 📈 色調曲線
+可移動分界點的參數曲線(區域曲線),**再加上** RGB、紅、綠、藍的點曲線。曲線在結構上就是單調的,
+所以不會意外出現色調反轉。
+
+
+
+
+
+
+ RGB 點曲線上一條平緩的 S 形曲線,就在「光線」滑桿正下方。安瑟·亞當斯,1942(公眾領域)。
+
+
+
+ 「色彩」面板中的陰影、中間調與亮部色輪。桃樂絲·蘭格,《移民母親》(1936)。公眾領域,美國國會圖書館。
+
+
+\\ 偷看原圖,按 Y 並排比較,或按 Shift +Y 分割檢視。
+下面每一張都是 LightCraft 的真實截圖,由代理透過[控制通道](#built-for-agents)自動擷取。
+
+
+
+《提頓山脈與蛇河》。 亮部 −45、陰影 +38、清晰度 +28、去朦朧 +18。安瑟·亞當斯,1942(公眾領域)。 《移民母親》。 陰影 +42、紋理 +18、分離色調分級、暗角。桃樂絲·蘭格,1936(公眾領域)。
+
+《地出》。 去朦朧 +22、亮部 −30、更暖的白平衡、自然飽和度 +22。NASA/比爾·安德斯,阿波羅 8 號,1968(公眾領域)。 《藍色大理石》。 亮部 −38、黑色色階 −20、去朦朧 +15、自然飽和度 +30。NASA,阿波羅 17 號,1972(公眾領域)。
+
+
+
+ 疊加在線性「天空」遮色片之上的放射狀「陽光光暈」遮色片(色溫 +40、曝光 +0.50)。照片來自 LightCraft 程式產生的示範照片庫。
+
+
+
+ 預設集欄與 8 段式混色器並排。照片來自示範照片庫。
+
+
+
+
+
+
+### ✂️ 裁切、拉直與幾何
+自由或鎖定的長寬比(1:1、4:5、5:7、2:3、4:3、16:9、16:10、原始比例),拖曳旋轉拉直時會始終把最大的裁切框
+保持在畫面內,三分法/格線/黃金比例裁切疊加,翻轉與 90° 旋轉,再加上手動的垂直、水平、旋轉、長寬比、
+縮放與偏移變換。
+
+
+
+
+### ⚫️ 黑白
+一鍵(V )轉為單色,搭配 8 段式**黑白混色**,可壓暗天空或讓樹葉發亮。
+之後再用色彩分級調出硒調色、深褐色調或分離色調的沖印效果。
+
+
+
+
+一個 16:9 的裁切框拉直了 +2.5°,附三分法裁切疊加。安瑟·亞當斯,1942(公眾領域)。 分割檢視:左邊是彩色原圖,右邊是附清晰度、暗角與顆粒的黑白。示範照片庫。
+
+
+0 –5 評分,用 P / X /
+U 加旗標,用 6 –9 加色彩標籤。搜尋支援欄位語法:
+`rating:>3 flag:pick iso:>800 camera:x2 date:2026-04 keyword:mountains`。每個檢視都能依拍攝日期、
+匯入日期、編輯日期、名稱、評分、大小或隨機排序(一種穩定的亂序;「檢視 → 排序 → 重新隨機排序」可換一個順序)。
+左右對齊的**照片格狀檢視**與**方格檢視**都經過虛擬化處理,
+所以無論是四十張還是四萬張照片都一樣流暢。
+
+
+
+照片格狀檢視,相簿以巢狀收在資料夾裡,附評分與旗標。示範照片庫。 四張公眾領域展示照片的方格檢視。
+
+資訊面板:檔案、尺寸、評分、標題、圖說、著作權與相機中繼資料。NASA/比爾·安德斯,《地出》,阿波羅 8 號,1968(公眾領域)。
+
+
+✅ 現已可用 · 🚧 進行中 · ⬜ 尚未開始
+
+G 格狀檢視 · D 詳細檢視 · E 編輯 · C 裁切 · M 遮色片 ·
+Shift +P 預設集 · \\ 原圖 · Y 編輯前/後 · Z 縮放 ·
+J 顯示溢色 · ⌘Z 復原 · ⌘/ 全部快速鍵。
+
+## How it's built
+
+一個引擎優先的 Cargo 工作區,由一群小而經過測試的 crate 組成,並強制分層(`cargo xtask layers`):`geom`、
+`color`、`raster`、`tiff` → `raw`、`codecs`、`meta`、`develop` → `pipeline` → `catalog` → `engine` → `ui-egui`。
+egui 前端是一個可替換的 crate;它之下沒有任何東西知道 UI 的存在。`mcp` 和各個應用程式(`lightcraft`、
+`lightcraft-cli`)則坐落在 `engine` 之上。
+
+## Contributing
+
+人類與代理遵循同一套規則,所以請先讀 [AGENTS.md](AGENTS.md)。重點如下:
+
+- **淨室。** 絕不閱讀 Adobe 的二進位檔或 GPL 的 raw/照片程式碼(darktable、RawTherapee、LibRaw、rawspeed、dcraw……);
+ 只依據公開規格與黑盒觀察來工作。
+- **絕不使用 Adobe 資產:** 不使用 Adobe 產品的圖示、截圖、預設集、描述檔、LUT 或字型。儲存庫中的每一張
+ 影像、圖示和字型都是原創、公眾領域、創用 CC、OFL 或寬鬆授權的,並在同一次提交中
+ 於 [assets/ATTRIBUTION.md](assets/ATTRIBUTION.md) 新增條目。新的字型要提交到
+ [storytold/craft-fonts](https://github.com/storytold/craft-fonts),而不是這裡。
+- **純 Rust**、強制的 crate 分層、一切皆指令,並且每次提交前 `cargo xtask ci` 都必須通過
+ (一次提交對應一個任務 ID)。
+- **絕不當機。** 非測試程式碼要回傳錯誤而不是 panic:不使用 `unwrap()`、`expect()`、`panic!` 或
+ `unsafe`,對任何來自輸入的資料都做受檢的索引存取,並且每一個當機修復都要附一個回歸測試。細節見
+ [AGENTS.md](AGENTS.md#never-crash-outranks-feature-work)。
+
+有問題、想法,或是想先討論一個 bug?來 [Discord](https://discord.gg/artcraft)。
+
+` 是版本號,`SHA256SUMS.txt` 列出了每個檔案的檢查碼。
+
+### Windows
+
+| 建置版本 | 安裝程式 | 可攜版 |
+|---|---|---|
+| x64(64 位元 Intel/AMD) | `lightcraft--windows-x64.msi` | `lightcraft--windows-x64-portable.zip` |
+| arm64(Snapdragon 及其他 ARM PC) | `lightcraft--windows-arm64.msi` | `lightcraft--windows-arm64-portable.zip` |
+| x86(32 位元) | `lightcraft--windows-x86.msi` | `lightcraft--windows-x86-portable.zip` |
+
+安裝程式與執行檔都有程式碼簽章。安裝程式會詢問安裝位置(預設為
+`C:\Program Files\LightCraft`;升級時會留在你選擇的資料夾),結束時會有一頁確認 LightCraft 已安裝,
+並可選擇立即啟動。無訊息安裝:`msiexec /i lightcraft--windows-x64.msi /qn INSTALLFOLDER="D:\Apps\LightCraft\"`。
+
+### macOS
+
+| 建置版本 | 檔案 | 備註 |
+|---|---|---|
+| 應用程式,通用版(Apple 晶片 + Intel) | `lightcraft--macos-universal.dmg` | 已簽章並經過公證 |
+| 命令列工具,通用版 | `lightcraft-cli--macos-universal.zip` | 已簽章並經過公證 |
+
+### Linux
+
+| 格式 | x86_64 | aarch64(ARM64) | 備註 |
+|---|---|---|---|
+| AppImage | `lightcraft--linux-x86_64.AppImage` | `lightcraft--linux-aarch64.AppImage` | 隨處可執行;用 [AppImageUpdate](https://github.com/AppImageCommunity/AppImageUpdate)(`.zsync` 檔案)自我更新 |
+| Flatpak | `lightcraft--linux-x86_64.flatpak` | `lightcraft--linux-aarch64.flatpak` | 沙箱化;`flatpak install --user ` |
+| Debian/Ubuntu | `lightcraft--linux-x86_64.deb` | `lightcraft--linux-aarch64.deb` | |
+| Fedora/RHEL/openSUSE | `lightcraft--linux-x86_64.rpm` | `lightcraft--linux-aarch64.rpm` | |
+| 壓縮檔 | `lightcraft--linux-x86_64.tar.gz` | `lightcraft--linux-aarch64.tar.gz` | 解壓到任意位置即可使用 |
+
+RISC-V(riscv64):`lightcraft--linux-riscv64.tar.gz`,僅提供壓縮檔(glibc 2.39 或更新版本,例如 Ubuntu 24.04+)。
+
+在 Wayland 桌面環境中,LightCraft 會在可用時透過 XWayland 執行,因為只有 X11 支援
+視窗的檔案拖放;設定 `LIGHTCRAFT_WAYLAND=1` 可改用原生 Wayland(更清晰的小數縮放,但無法拖放)。
+
+### FreeBSD
+
+| 建置版本 | 檔案 |
+|---|---|
+| x86_64 | `lightcraft--freebsd-x86_64.tar.gz` |
+
+### Web (WebAssembly)
+
+| 建置版本 | 檔案 | 備註 |
+|---|---|---|
+| 靜態網站 | `lightcraft-web-.zip` | 可在現代瀏覽器中執行;可託管在任何靜態伺服器上 |
+
+
+
+
+Come make things with us
+
+
+ 我們的 Discord 是各種創作者聚集的地方:畫畫的人、拍照的人、做動畫的人、剪片子的人、
+ 排版的人,還有仍在摸索自己喜歡做什麼的人。分享你在做的東西,
+ 尋求幫助,告訴我們哪裡壞了,或者告訴我們你希望這些工具能做到什麼。
+ 不管你用什麼媒材,也不管你做了多久,這裡都歡迎你。
+
+
+
+ discord.gg/artcraft getartcraft.com ·
+ The Crafting Apps ·
+ LightCraft
+
+
+Adobe、Photoshop、Illustrator、Premiere Pro、Lightroom、Acrobat、After Effects 與 InDesign 是 Adobe Inc. 在美國及/或其他國家的商標或註冊商標。LightCraft 是一個獨立的開源專案,與 Adobe Inc. 沒有任何關係,也未獲其贊助或認可;這些名稱僅用於說明它所相容的工作流程。
+
+
+ 由 ArtCraft 團隊與社群製作。
+
+
+## Star history
+
+[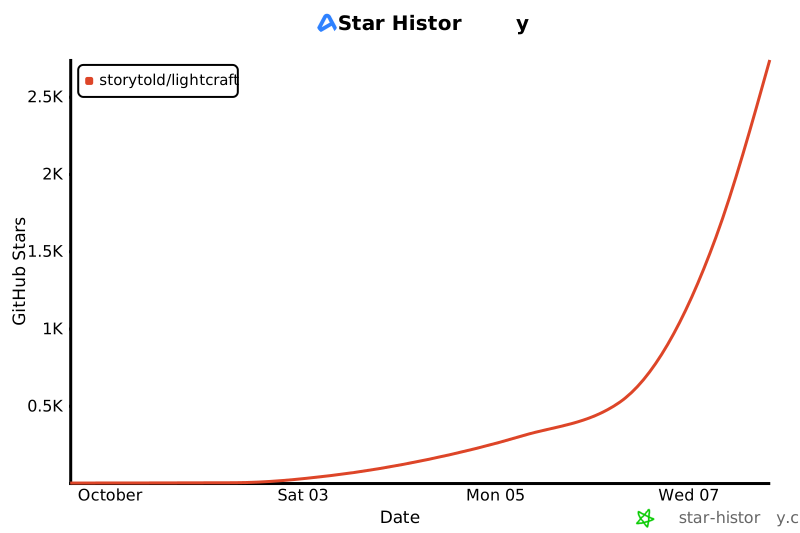](https://www.star-history.com/?repos=storytold%2Flightcraft&type=date&legend=top-left)
+
+照片庫、工具與預設集面板可以重新分組、拆分、浮動於應用程式視窗內、關閉與重新開啟。工具面板會保留目前的編輯/裁切/遮色片模式;照片檢視區與底片顯示窗格則維持在一起。拖曳面板標題到某個目標邊緣或另一個標題上即可調整。右鍵選單提供「浮動面板」、「移至群組」與「關閉面板」。既有的面板切換按鈕會在上次儲存的位置重新開啟面板;「重設面板配置」則會還原應用程式的版面配置。浮動面板會保持在目前的應用程式視窗之內。
diff --git a/ROADMAP.md b/ROADMAP.md
index f142cd226..ec392e88d 100644
--- a/ROADMAP.md
+++ b/ROADMAP.md
@@ -2,7 +2,7 @@
**Stage: alpha** · next: beta, ~14 points and ~340–600 h away
-> **Last reviewed:** 2026-10-10 · **Last updated:** 2026-10-15 · **Change:** minor (RAW: 83% of Adobe's models decode, 38% verified after the camera-coverage sweep #1327) · **Target:** Adobe Lightroom Classic 15.5 / Lightroom 9.6
+> **Last reviewed:** 2026-10-10 · **Last updated:** 2026-10-16 · **Change:** minor (Minolta MRW decoded, 6 bodies verified; RAW: 83% of Adobe's models decode, 38% verified after the camera-coverage sweep #1327; German catalog 91% → 97%: interface strings and What's New lines translated) · **Target:** Adobe Lightroom Classic 15.5 / Lightroom 9.6
One-page summary of how close LightCraft is to Adobe Lightroom. Agents: read this, then pick work
from [docs/gaps.md](docs/gaps.md). The full assessment, method and evidence are in
@@ -49,7 +49,7 @@ Hours are calibrated on this repo's PR history; see
| UI/UX fidelity | ~70% | ~85% | 32–54 h | [ui-parity](docs/ui-parity.md) |
| File formats (non-raw) | ~70% | ~85% | 30–55 h | [file-format-parity](docs/file-format-parity.md) |
| Hardware | ~40% | ~50% | 40–80 h | [hardware-parity](docs/hardware-parity.md) |
-| Localization | ~55% of the 12 key languages | 7 of 12 present | 130–210 h (+145–255 h new scripts) | [localization-parity](docs/localization-parity.md) |
+| Localization | ~64% of the 12 key languages | 8 of 12 present | 130–210 h (+135–239 h new scripts) | [localization-parity](docs/localization-parity.md) |
| Performance | ~70% | ~80% | 30–50 h | [target-app-parity](docs/target-app-parity.md#by-dimension) |
| Stability | ~60% | — | 30–60 h | [target-app-parity](docs/target-app-parity.md#by-dimension) |
| Platforms | ~60% | macOS, Windows, Linux, FreeBSD, web | 25–45 h | [target-app-parity](docs/target-app-parity.md#by-dimension) |
@@ -78,7 +78,7 @@ Weights and evidence: [target-app-parity.md](docs/target-app-parity.md#features)
## Languages
-Measured from `crates/ui-egui/locales` (share of 2,304 catalog messages translated); none is `full`
+Measured from `crates/ui-egui/locales` (share of 2,304 catalog messages translated; German counts 3,644 of 3,754, because its What's New lines add keys); none is `full`
while lower-layer errors stay English. Detail: [localization-parity.md](docs/localization-parity.md).
| Language | Code | Translated | Status |
@@ -90,13 +90,13 @@ while lower-layer errors stay English. Detail: [localization-parity.md](docs/loc
| Arabic | ar | 0% | none (no RTL / shaping) |
| French | fr | 88% | partial |
| Portuguese (Brazil) | pt-br | 85% | partial |
-| Indonesian | id | 0% | none |
+| Indonesian | id | 100% (What's New in English) | partial |
| Japanese | ja | 87% | partial |
-| German | de | 91% | partial |
+| German | de | 97% (3,644/3,754) | partial |
| Korean | ko | 0% | none (no Hangul face) |
| Vietnamese | vi | 0% | none |
-Also shipped: Traditional Chinese (87%), Russian (74%), Ukrainian (99%), Italian (92%), Georgian (100%).
+Also shipped: Traditional Chinese (87%), Russian (74%), Ukrainian (99%), Italian (92%), Georgian (100%), Finnish (79%).
## Upcoming
@@ -117,6 +117,9 @@ Ranked toward beta; detail in [docs/roadmap.md](docs/roadmap.md), gaps in [docs/
- 2026-10-14: Camera-coverage sweep verifies 30 more models on 40 CC0 files, with file and sensor
hashes pinned (`docs/raw/coverage.py`: 515 → 545 verified). Eleven candidates excluded after rechecking
identity, provenance and camera-image agreement. Phone and drone DNG tone differences remain tracked in #1277.
+- 2026-10-18: Minolta / Konica Minolta MRW decodes from sensor data (12-bit packed and 16-bit words,
+ RGGB and GBRG, as-shot WB from `WBG`); DiMAGE 7, 7Hi, A1, A2, A200 and Dynax / Maxxum 7D verified on
+ CC0 files. 551 models verified, 201 preview-only; headline numbers unchanged.
- 2026-10-14: 97 Canon CR2, Pentax and Ricoh models verified, one CC0 raw.pixls.us file each pinned and
checked against the camera JPEG (`crates/raw/tests/canon_pentax_corpus.rs`). 334 models verified, ~50% of
photographers on a verified body; headline numbers unchanged.
@@ -183,17 +186,21 @@ Ranked toward beta; detail in [docs/roadmap.md](docs/roadmap.md), gaps in [docs/
| Date | Change | Summary |
|---|---|---|
+| 2026-10-19 | minor | Indonesian interface (`id`): every plain and formats message, plus 69 command labels, locale, menu command and tests; What's New left in English; Localization ~55% → ~64% (mean of the 12 key languages), 8 of 12 present |
| 2026-10-12 | minor | Italian interface (`it`, #1192): 2,201 of 2,398 messages, locale, menu command and tests; headline numbers unchanged |
| 2026-10-13 | minor | Sony ILCA-99M2 camera colour profile in the log; numbers unchanged |
| 2026-10-14 | minor | Localization ~52% → ~55% (mean of the 12 key languages): de, es, fr, ja and uk catalogs filled |
+| 2026-10-16 | minor | German 91% → 97% (217 interface strings and 862 What's New lines added); headline numbers unchanged |
| 2026-10-14 | minor | 21 Sony and Leica models verified (258 models, 18%); headline numbers unchanged |
| 2026-10-12 | minor | UI/UX remaining 34–58 h → 32–54 h (canvas tools by keyboard); headline numbers unchanged |
| 2026-10-14 | minor | 17 uncompressed Olympus and Samsung models verified on one CC0 file each (254 models verified, 18%); headline numbers unchanged |
| 2026-10-12 | minor | Mamiya MEF decoded and imported: ZD verified (241); headline numbers unchanged |
| 2026-10-12 | minor | Epson ERF decoded: 3 more verified models (240); headline numbers unchanged |
| 2026-10-12 | minor | Georgian (`ka`) interface language added (every catalog message) |
+| 2026-10-17 | minor | Finnish (`fi`) interface language added: 2,610 of 3,308 messages (79%), locale, menu command and tests; headline numbers unchanged |
| 2026-10-14 | minor | Full-resolution zoom (gap 4) closed: soft proofing gets zoom windows; headline numbers unchanged |
| 2026-10-12 | minor | UI/UX remaining 40–70 h → 34–58 h (accessibility audit landed); headline numbers unchanged |
+| 2026-10-18 | minor | Minolta MRW decodes from sensor data; 6 Konica Minolta bodies verified; headline numbers unchanged |
| 2026-10-14 | minor | Camera-coverage sweep (#1327): 30 models verified on 40 CC0 files (coverage.py 515 → 545 verified); sensor verification does not establish colour parity (#1277); headline numbers unchanged |
| 2026-10-12 | minor | 22 more CR3 bodies verified, EOS R6 Mark III white balance: RAW decoding 77% → 83%, RAW ~56% → ~60%; mainstream 49% → 51%, essentials 64% → 65%; full unchanged at ~61% |
| 2026-10-12 | minor | 117 Nikon and Fujifilm bodies verified (354 models, 24%); headline numbers unchanged |
diff --git a/SECURITY.md b/SECURITY.md
new file mode 100644
index 000000000..6d7340dd5
--- /dev/null
+++ b/SECURITY.md
@@ -0,0 +1,54 @@
+# Security Policy
+
+LightCraft reads camera raw files, image formats, metadata and sidecars, imports other photo catalogs, downloads and runs machine-learning models, and exposes CLI, JSON control, and MCP automation. Treat files, paths, metadata, catalogs, model files, automation requests, and command parameters as potentially malicious.
+
+## Reporting a vulnerability
+
+Please give the repository maintainers a reasonable opportunity to investigate and coordinate a fix before publishing exploitable details, proof-of-concept code, or weaponized files.
+
+This repository does not currently document a dedicated private security email or private reporting channel. Contact the repository maintainers through the repository owner/maintainer channels already listed in the project, provide only a minimal non-exploitable summary in public, and ask for an appropriate private transfer method before sharing sensitive details. Do not open a public issue containing a working exploit, secret, sensitive crash dump, or malicious attachment.
+
+If no private channel can be established, withhold weaponized material and report the smallest safe description that allows maintainers to make contact.
+
+## What to include
+
+A useful report includes:
+
+- affected LightCraft version, commit, or release artifact;
+- operating system, architecture, build profile (desktop or web), and relevant feature flags;
+- the affected component or path;
+- security impact and required attacker access;
+- exact reproduction steps;
+- expected behavior and actual behavior;
+- crash logs, backtraces, sanitizer output, or resource measurements when applicable;
+- whether the problem reproduces from a clean checkout;
+- any known workaround or containment.
+
+Remove credentials, personal paths, private photos, and unrelated system information from logs.
+
+## Malicious test files
+
+Do not attach a potentially harmful or non-redistributable file to a public issue. Initially provide its format, size, cryptographic hash, observed effect, provenance category (for example, synthetic or fuzz-generated), and the command needed to reproduce the problem. Coordinate a private transfer method with maintainers before sending the sample.
+
+Test files accepted into the repository must be minimized, free of personal or proprietary data, legally redistributable, and documented with the expected failure behavior. A fixed parser defect should receive a permanent regression test whenever safe and practical.
+
+## Scope
+
+Security reports may cover:
+
+- camera raw, DNG, TIFF, HEIF, JPEG and other image decoding, and EXIF/XMP metadata and sidecar parsing;
+- decompression bombs, oversized dimensions, integer overflow, memory exhaustion, recursion, or hangs;
+- the LightCraft catalog, and importing other catalogs and libraries (such as Lightroom catalogs);
+- import/export and filesystem path handling, including traversal, symlinks, and unsafe overwrite or move behavior;
+- downloading, verifying, unpacking and running machine-learning models (denoise, faces, masks);
+- engine command validation and serialization/deserialization;
+- the desktop control channel, the MCP server, and the MCP-to-app connection;
+- the WebAssembly build;
+- GPU resource validation or driver-facing input handling;
+- dependencies, CI, packaging, signing, checksums, and release artifact integrity.
+
+General bugs without a security impact should use the project's normal issue and contribution process.
+
+## Current limitations
+
+The control channel (`lightcraft --control PORT`) listens on loopback only and has no authentication, so any local process can drive the app while it is enabled; only enable it when you need it ([control-protocol.md](docs/control-protocol.md)).
diff --git a/apps/lightcraft/Cargo.toml b/apps/lightcraft/Cargo.toml
index 26122c3e6..95e080974 100644
--- a/apps/lightcraft/Cargo.toml
+++ b/apps/lightcraft/Cargo.toml
@@ -26,6 +26,7 @@ lightcraft-raster = { workspace = true }
eframe = { workspace = true, features = ["default_fonts", "wgpu", "glow", "accesskit", "wayland", "x11"] }
egui = { workspace = true }
serde_json = { workspace = true }
+chrono = { workspace = true }
# probing the window's renderer before it opens (`window_gpu`)
pollster = { workspace = true }
log = { workspace = true }
diff --git a/apps/lightcraft/src/control_server.rs b/apps/lightcraft/src/control_server.rs
index 537c75bd1..777831942 100644
--- a/apps/lightcraft/src/control_server.rs
+++ b/apps/lightcraft/src/control_server.rs
@@ -39,22 +39,33 @@ pub fn start(port: u16, ctx: egui::Context) -> Receiver {
fn accept_loop(listener: TcpListener, tx: Sender, ctx: egui::Context) {
let open = Arc::new(AtomicUsize::new(0));
- for mut stream in listener.incoming().flatten() {
- if open.fetch_add(1, Ordering::SeqCst) >= MAX_CONNECTIONS {
- open.fetch_sub(1, Ordering::SeqCst);
- let _ = writeln!(stream, "{}", json!({"ok": false, "error": "too many control connections"}));
- continue;
- }
- let tx = tx.clone();
- let ctx = ctx.clone();
- let open = Arc::clone(&open);
- std::thread::spawn(move || {
- serve(stream, &tx, &ctx);
- open.fetch_sub(1, Ordering::SeqCst);
- });
+ for stream in listener.incoming().flatten() {
+ let _ = spawn_connection(stream, tx.clone(), ctx.clone(), Arc::clone(&open), IDLE_TIMEOUT);
}
}
+/// Admit and serve one connection, releasing its slot when serving ends.
+fn spawn_connection(
+ mut stream: TcpStream,
+ tx: Sender,
+ ctx: egui::Context,
+ open: Arc,
+ idle_timeout: Duration,
+) -> Option> {
+ if open.fetch_add(1, Ordering::SeqCst) >= MAX_CONNECTIONS {
+ open.fetch_sub(1, Ordering::SeqCst);
+ let _ = writeln!(stream, "{}", json!({"ok": false, "error": "too many control connections"}));
+ return None;
+ }
+ Some(std::thread::spawn(move || {
+ serve(stream, &tx, &ctx, idle_timeout);
+ open.fetch_sub(1, Ordering::SeqCst);
+ }))
+}
+
+/// Five minutes allows pauses between automation commands without retaining abandoned slots forever.
+const IDLE_TIMEOUT: Duration = Duration::from_secs(5 * 60);
+
/// How long a request waits for its reply.
const REPLY_TIMEOUT: Duration = Duration::from_secs(60);
/// A request the app has not picked up while it drew no frame for this long is given up: the
@@ -66,9 +77,17 @@ const NO_FRAMES_AFTER: Duration = Duration::from_secs(5);
pub const HIDDEN_WINDOW_ERROR: &str = "the app drew no frame for 5 s, so the request was not run: its window is probably not visible \
(on Wayland a window on a hidden workspace or minimized is not redrawn, which pauses the app). Bring the window on screen and send it again";
-fn serve(stream: TcpStream, tx: &Sender, ctx: &egui::Context) {
- let Ok(read) = stream.try_clone() else { return };
- serve_lines(read, stream, |method, params| {
+/// Reads and writes go through the one `stream` (`&TcpStream` is `Read` and `Write`): no
+/// `try_clone`. On Windows a cloned socket handle is inheritable, so every program the app starts
+/// while a client is connected (a link in the browser, Show in Explorer, an external editor) kept a
+/// copy of the connection: closing it then reached the client only when that program exited, as a
+/// reset instead of a clean close.
+fn serve(stream: TcpStream, tx: &Sender, ctx: &egui::Context, idle_timeout: Duration) {
+ if let Err(e) = stream.set_read_timeout(Some(idle_timeout)) {
+ log::warn!("control connection closed: could not set idle read timeout: {e}");
+ return;
+ }
+ serve_lines(&stream, &stream, |method, params| {
let (req, rrx) = ControlRequest::new(method, params);
let state = Arc::clone(&req.state);
tx.send(req).ok()?;
@@ -157,7 +176,10 @@ fn read_bounded_line(reader: &mut impl BufRead, buf: &mut Vec, max: usize) -
buf.clear();
// `take` bounds the bytes buffered for one line: a peer can't make us allocate more than `max`.
let limit = u64::try_from(max).unwrap_or(u64::MAX).saturating_add(1);
- let n = reader.take(limit).read_until(b'\n', buf).map_err(|e| e.to_string())?;
+ let n = reader.take(limit).read_until(b'\n', buf).map_err(|e| match e.kind() {
+ std::io::ErrorKind::WouldBlock | std::io::ErrorKind::TimedOut => "control connection idle read timed out; closing the connection".to_string(),
+ _ => e.to_string(),
+ })?;
if n == 0 {
return Ok(false);
}
@@ -209,6 +231,95 @@ fn serve_lines(read: R, mut out: W, mut handle: impl FnMut(St
mod tests {
use super::*;
+ /// Own the client and worker together: even a failing timeout assertion closes the socket
+ /// before joining, so the regression cannot leave a worker stuck in a read.
+ struct Connection {
+ client: BufReader,
+ requests: Receiver,
+ worker: Option>,
+ }
+
+ impl Connection {
+ fn new(open: &Arc, idle: Duration) -> Self {
+ let listener = TcpListener::bind(("127.0.0.1", 0)).unwrap();
+ let client = TcpStream::connect(listener.local_addr().unwrap()).unwrap();
+ client.set_read_timeout(Some(Duration::from_secs(3))).unwrap();
+ let (stream, _) = listener.accept().unwrap();
+ let (tx, requests) = channel();
+ let worker = spawn_connection(stream, tx, egui::Context::default(), Arc::clone(open), idle).unwrap();
+ Self { client: BufReader::new(client), requests, worker: Some(worker) }
+ }
+
+ fn join(&mut self) {
+ if let Some(worker) = self.worker.take() {
+ worker.join().unwrap();
+ }
+ }
+ }
+
+ impl Drop for Connection {
+ fn drop(&mut self) {
+ let _ = self.client.get_ref().shutdown(std::net::Shutdown::Both);
+ while let Ok(req) = self.requests.try_recv() {
+ let _ = req.reply.send(json!({"ok": false, "error": "test closing"}));
+ }
+ self.join();
+ }
+ }
+
+ #[test]
+ fn idle_connections_release_their_slots_without_dispatching() {
+ for input in ["", "{\"method\":\"engine.execute\""] {
+ let open = Arc::new(AtomicUsize::new(0));
+ let mut connection = Connection::new(&open, Duration::from_millis(100));
+ assert_eq!(open.load(Ordering::SeqCst), 1);
+ connection.client.get_mut().write_all(input.as_bytes()).unwrap();
+ let mut reply = String::new();
+ let closed = connection.client.read_to_string(&mut reply);
+ assert!(closed.is_ok(), "idle connection stayed open: {closed:?}");
+ connection.join();
+ assert_eq!(open.load(Ordering::SeqCst), 0, "the production worker releases its slot");
+ assert!(connection.requests.try_recv().is_err(), "incomplete input never runs");
+ let reply: Value = serde_json::from_str(&reply).unwrap();
+ assert_eq!(reply["ok"], false);
+ assert!(reply["error"].as_str().unwrap().contains("idle read timed out"));
+
+ // A subsequent connection is admitted through the same accounting path.
+ let mut next = Connection::new(&open, Duration::from_secs(1));
+ next.client.get_mut().shutdown(std::net::Shutdown::Write).unwrap();
+ let mut eof = String::new();
+ next.client.read_to_string(&mut eof).unwrap();
+ next.join();
+ assert!(eof.is_empty());
+ assert_eq!(open.load(Ordering::SeqCst), 0);
+ }
+ }
+
+ #[test]
+ fn persistent_requests_and_slow_replies_outlive_the_idle_read_timeout() {
+ let open = Arc::new(AtomicUsize::new(0));
+ let mut connection = Connection::new(&open, Duration::from_millis(100));
+ for id in [1, 2] {
+ writeln!(connection.client.get_mut(), "{}", json!({"id": id, "method": "engine.commands"})).unwrap();
+ let req = connection.requests.recv_timeout(Duration::from_secs(3)).unwrap();
+ assert_eq!(req.method, "engine.commands");
+ assert!(req.take());
+ // A dispatched command waits for its reply, not for socket input.
+ std::thread::sleep(Duration::from_millis(250));
+ req.reply.send(json!({"ok": true, "result": id})).unwrap();
+ let mut reply = String::new();
+ connection.client.read_line(&mut reply).unwrap();
+ let reply: Value = serde_json::from_str(&reply).unwrap();
+ assert_eq!(reply, json!({"id": id, "ok": true, "result": id}));
+ }
+ connection.client.get_mut().shutdown(std::net::Shutdown::Write).unwrap();
+ let mut eof = String::new();
+ connection.client.read_to_string(&mut eof).unwrap();
+ connection.join();
+ assert!(eof.is_empty());
+ assert_eq!(open.load(Ordering::SeqCst), 0);
+ }
+
/// Issue #718: an app that draws no frames (a hidden Wayland window) gets the request given
/// up with a reason, quickly, and the app then skips it instead of running it late.
#[test]
@@ -337,6 +448,37 @@ mod tests {
assert!(read_bounded_line(&mut &[b'a'; 11][..], &mut buf, 10).is_err());
}
+ /// A program the app starts while a client is connected doesn't keep the connection open:
+ /// when the server closes it, the client sees that at once, not when the program exits.
+ #[cfg(windows)]
+ #[test]
+ fn a_program_started_meanwhile_does_not_hold_the_connection_open() {
+ let listener = TcpListener::bind(("127.0.0.1", 0)).unwrap();
+ let addr = listener.local_addr().unwrap();
+ let (tx, _rx) = channel::();
+ let server = std::thread::spawn(move || {
+ let (s, _) = listener.accept().unwrap();
+ serve(s, &tx, &egui::Context::default(), IDLE_TIMEOUT);
+ });
+ let mut c = TcpStream::connect(addr).unwrap();
+ c.set_read_timeout(Some(Duration::from_secs(20))).unwrap();
+ // the connection is being served: start a program that lives about 4 s
+ std::thread::sleep(Duration::from_millis(200));
+ let mut child = std::process::Command::new("cmd").args(["/c", "ping -n 5 127.0.0.1 >nul"]).spawn().unwrap();
+ std::thread::sleep(Duration::from_millis(200));
+ // junk makes the server answer once and close
+ c.write_all(b"hello\n").unwrap();
+ let t0 = std::time::Instant::now();
+ let mut text = String::new();
+ let read = c.read_to_string(&mut text);
+ let waited = t0.elapsed();
+ server.join().unwrap();
+ let _ = child.wait();
+ assert!(read.is_ok(), "the close must be clean, not a reset: {read:?}");
+ assert!(text.contains("closing the connection"), "{text}");
+ assert!(waited < Duration::from_secs(2), "the client saw the close only after {waited:?}, when the program exited");
+ }
+
#[test]
fn tcp_connection_is_closed_after_junk() {
// End to end over a real loopback socket (the transport the app uses).
diff --git a/apps/lightcraft/src/logging.rs b/apps/lightcraft/src/logging.rs
index 718392f35..6239aded6 100644
--- a/apps/lightcraft/src/logging.rs
+++ b/apps/lightcraft/src/logging.rs
@@ -113,28 +113,36 @@ fn matches(name: &str, target: &str) -> bool {
}
/// `2026-10-08T07:59:17.728Z` (UTC, milliseconds). A clock before 1970 reads as the epoch.
+/// A clock far past chrono's year range still converts (the calendar repeats every 400 years), so
+/// logging never panics and never silently resets to the epoch for a convertible instant.
pub fn timestamp(t: SystemTime) -> String {
let since = t.duration_since(std::time::UNIX_EPOCH).unwrap_or_default();
- let secs = since.as_secs();
- let (days, rem) = (secs / 86_400, secs % 86_400);
- let (y, m, d) = civil_from_days(days);
- format!("{y:04}-{m:02}-{d:02}T{:02}:{:02}:{:02}.{:03}Z", rem / 3600, rem % 3600 / 60, rem % 60, since.subsec_millis())
+ // Pre-1970 is clamped to the epoch by `unwrap_or_default` above. `as_secs` is `u64`; a value
+ // past `i64::MAX` seconds saturates rather than falling back to the epoch.
+ let secs = i64::try_from(since.as_secs()).unwrap_or(i64::MAX);
+ let (y, t) = utc_parts(secs, since.subsec_nanos());
+ // `{:04}` rather than `%Y`, which writes a `+` before years past 9999.
+ format!("{y:04}-{}", t.format("%m-%dT%H:%M:%S%.3fZ"))
}
-/// Days since 1970-01-01 to a proleptic Gregorian (year, month, day) (Howard Hinnant's
-/// `civil_from_days`, unsigned because `timestamp` clamps at the epoch). Saturating, so no clock
-/// value can overflow it.
-fn civil_from_days(days: u64) -> (u64, u64, u64) {
- let z = days.saturating_add(719_468);
- let era = z / 146_097;
- let doe = z % 146_097;
- let yoe = (doe - doe / 1460 + doe / 36_524 - doe / 146_096) / 365;
- let doy = doe - (365 * yoe + yoe / 4 - yoe / 100);
- let mp = (5 * doy + 2) / 153;
- let d = doy - (153 * mp + 2) / 5 + 1;
- let m = if mp < 10 { mp + 3 } else { mp - 9 };
- let y = era.saturating_mul(400).saturating_add(yoe).saturating_add(u64::from(m <= 2));
- (y, m, d)
+/// Unix seconds (+ nanos) → (proleptic Gregorian year, the same wall-clock instant moved into
+/// chrono's range by whole 400-year cycles). The calendar repeats every 400 years (146_097 days),
+/// so month, day and time of day come from chrono and only the year is carried, which keeps every
+/// `i64` exact. Replaces the old hand-rolled `civil_from_days`; chrono is the only calendar logic.
+fn utc_parts(secs: i64, nanos: u32) -> (i64, chrono::NaiveDateTime) {
+ use chrono::Datelike;
+ let (days, sod) = (secs.div_euclid(86_400), secs.rem_euclid(86_400));
+ let (cycles, rest) = (days.div_euclid(146_097), days.rem_euclid(146_097));
+ // `rest + 719_163` (1970-01-01 is CE day 719_163) is always a valid CE day, and `sod` < 86_400.
+ let date = i32::try_from(rest + 719_163).ok().and_then(chrono::NaiveDate::from_num_days_from_ce_opt);
+ let time = u32::try_from(sod).ok().and_then(|s| chrono::NaiveTime::from_num_seconds_from_midnight_opt(s, nanos.min(999_999_999)));
+ match (date, time) {
+ (Some(d), Some(t)) => {
+ let y = i128::from(d.year()) + i128::from(cycles) * 400;
+ (i64::try_from(y).unwrap_or(if y < 0 { i64::MIN } else { i64::MAX }), d.and_time(t))
+ }
+ _ => (1970, chrono::NaiveDateTime::default()), // unreachable
+ }
}
fn numbered(dir: &Path, n: usize) -> PathBuf {
@@ -483,6 +491,20 @@ mod tests {
assert_eq!(timestamp(UNIX_EPOCH + Duration::from_secs(4_107_542_400)), "2100-03-01T00:00:00.000Z");
// Before the epoch (a clock set wrong) clamps instead of panicking.
assert_eq!(timestamp(UNIX_EPOCH - Duration::from_secs(5)), "1970-01-01T00:00:00.000Z");
+ // Past chrono's year range still converts via the 400-year cycle (the old code did too,
+ // through `civil_from_days`): never a silent reset to the epoch. Platform-safe: Windows'
+ // SystemTime can't hold this instant, so it is only checked where it exists.
+ // `u64::MAX / 2` seconds == `i64::MAX` seconds → year 292277026596 (old output).
+ if let Some(far) = UNIX_EPOCH.checked_add(Duration::from_secs(u64::MAX / 2)) {
+ assert_eq!(timestamp(far), "292277026596-12-04T15:30:07.000Z");
+ }
+ // Years past 9999 keep the plain zero-padded year (no `+`).
+ assert_eq!(timestamp(UNIX_EPOCH + Duration::from_secs(253_402_300_800)), "10000-01-01T00:00:00.000Z");
+ // 10_000_000_000_000 s is far beyond chrono's range; old output is year 318857.
+ // Windows' SystemTime holds only up to about year 30828, so this is checked where it fits.
+ if let Some(far) = UNIX_EPOCH.checked_add(Duration::from_secs(10_000_000_000_000)) {
+ assert_eq!(timestamp(far), "318857-05-20T17:46:40.000Z");
+ }
}
#[test]
diff --git a/assets/ATTRIBUTION.md b/assets/ATTRIBUTION.md
index 7f8a8a719..30eea5654 100644
--- a/assets/ATTRIBUTION.md
+++ b/assets/ATTRIBUTION.md
@@ -33,7 +33,11 @@ covers a whole directory), or if a licence file referenced in the Licence column
| `crates/ui-egui/locales/uk.json`, `crates/ui-egui/locales/uk-formats.json` | Ukrainian interface catalogs | @dmatviichuk with Codex; PhotoCraft, FilmCraft and VectorCraft translation contributors for reused labels | original translations from English source; 337 initial English-key matches reviewed from [PhotoCraft 69c41f3](https://github.com/storytold/photocraft/blob/69c41f3523e147eb215da8c7b4c29b18b35d1c63/crates/ui-egui/src/i18n/uk.tsv), [FilmCraft 4854c27](https://github.com/storytold/filmcraft/blob/4854c277536fe8118257362304b6a7d82d8e704b/crates/ui-egui/src/i18n/uk.tsv), [VectorCraft 4b44265](https://github.com/storytold/vectorcraft/blob/4b44265965fdd6ffedfd6182a892c1a6c360d344/crates/ui-egui/src/i18n/uk.tsv) | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`, also the source repositories' licences) | 2026-10-09 | adapted to LightCraft photo-development context, completed catalogs, reviewed spelling and placeholders |
| `crates/ui-egui/locales/cs.json`, `crates/ui-egui/locales/cs-formats.json` | Czech interface catalogs | @Losminek with AI assistance (Codex) | original work: translations of English source phrases, reviewed against the app UI conventions; no external translation material | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`) | 2026-10-11 | catalog coverage, Czech dates and count-neutral wording; independent scope/terminology review; native-speaker proofreading pending |
| `crates/ui-egui/locales/it.json`, `crates/ui-egui/locales/it-formats.json` | Italian interface catalogs | @GabrielePecchioli with Claude Code; PhotoCraft, VectorCraft, PdfCraft and WordCraft translation contributors for reused labels | original translations from English source; 410 initial English-key matches reviewed from [PhotoCraft da3da09](https://github.com/storytold/photocraft/blob/da3da0942c14c1159f40c652afcf33584332c733/crates/ui-egui/src/i18n/it.tsv), [VectorCraft 5432821](https://github.com/storytold/vectorcraft/blob/543282148007bcb5633c493a5374cd26b0339c8d/crates/ui-egui/src/i18n/it.tsv), [PdfCraft e8e275c](https://github.com/storytold/pdfcraft/blob/e8e275cbd40ccd0dc6b56f82b16a575571043702/crates/ui-egui/src/i18n/it.tsv) and the Italian WordCraft catalog ([storytold/wordcraft#598](https://github.com/storytold/wordcraft/pull/598)); 46 of them retranslated where the sibling's meaning didn't fit a photo app | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`, also the source repositories' licences) | 2026-10-12 | adapted to LightCraft photo-development context, count-neutral labels for Italian plural agreement, reviewed placeholders |
+| `crates/ui-egui/locales/id.json`, `crates/ui-egui/locales/id-formats.json` | Indonesian interface catalogs | @RevDonz with Claude Code; PhotoCraft, VectorCraft, FilmCraft and FigCraft translation contributors for reused labels | original translations from English source; 356 labels match the sibling apps' Indonesian wording, reviewed from [PhotoCraft c39d752](https://github.com/storytold/photocraft/blob/c39d752758155492bbaba71d802cfaa03206fb4a/crates/ui-egui/src/i18n/id.tsv), [VectorCraft 9fe0f03](https://github.com/storytold/vectorcraft/blob/9fe0f03de2bd29e8c86a1179f977c3e651069424/crates/ui-egui/src/i18n/id.tsv), [FilmCraft fae7f8a](https://github.com/storytold/filmcraft/blob/fae7f8a9be09bd74f95fbe08c3d98adc17fe1030/crates/ui-egui/src/i18n/id.tsv) and [FigCraft 8482c3e](https://github.com/storytold/figcraft/blob/8482c3e85bc5f2a430e2f3be2826674872f6d084/crates/ui-egui/locales/id.toml) | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`, also the source repositories' licences) | 2026-10-19 | adapted to LightCraft's photo context, count-neutral nouns, reviewed placeholders |
| `crates/ui-egui/locales/ka.json`, `crates/ui-egui/locales/ka-formats.json` | Georgian interface catalogs | Davit Matchakhelidze with Claude; WordCraft, GridCraft, PhotoCraft, FilmCraft and VectorCraft Georgian catalogs for reused labels | original translations from the English source (meaning-based, no vendor localization used); 450 English-key matches reused from the sibling Craft apps' Georgian catalogs | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`) | 2026-10-12 | adapted to LightCraft photo-library and raw-development context; count-neutral numerals; placeholders checked |
+| `crates/ui-egui/locales/sv.json`, `crates/ui-egui/locales/sv-formats.json` | Swedish interface catalogs | LightCraft contributors | original work: clean-room Swedish translations of English source phrases | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`) | 2026-10-15 | none |
+| `crates/ui-egui/locales/fi.json`, `crates/ui-egui/locales/fi-formats.json` | Finnish interface catalogs | @roopeg with Claude Code (AI-assisted; native-speaker review by @roopeg) | original work: translations of the English source phrases, using common Finnish photo-editing vocabulary; no external translation material | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`) | 2026-10-17 | count-neutral labels for Finnish partitive agreement, Finnish dates and times (`20.9.2026`, `16:04`), reviewed placeholders |
+| `crates/ui-egui/locales/vi.json`, `crates/ui-egui/locales/vi-formats.json` | Vietnamese interface catalogs | @duydev (DUY Tran Nhat) with AI assistance (Cursor) | original work: translations of English source phrases; no external translation material | MIT OR Apache-2.0 (`LICENSE-MIT`, `LICENSE-APACHE`) | 2026-10-13 | plural-neutral counts, Vietnamese dates and weekdays, reviewed placeholders |
Notes
- Fonts authored or published by Adobe (Source Sans/Serif/Code, Source Han, …) are not used, even though some are
diff --git a/contributors/people.toml b/contributors/people.toml
index 6f0bd6085..4eb002cef 100644
--- a/contributors/people.toml
+++ b/contributors/people.toml
@@ -61,3 +61,6 @@ sync_github_name = true
[people.mahmatias]
display_name = "Márcio Matias de Andrade"
sync_github_name = true
+
+[people.ronibalthazar]
+sync_github_name = true
diff --git a/crates/catalog/Cargo.toml b/crates/catalog/Cargo.toml
index 97d8868de..27273d5c4 100644
--- a/crates/catalog/Cargo.toml
+++ b/crates/catalog/Cargo.toml
@@ -17,6 +17,7 @@ serde_json = { workspace = true }
thiserror = { workspace = true }
crc32fast = { workspace = true }
log = { workspace = true }
+chrono = { workspace = true }
web-time = { workspace = true }
[dev-dependencies]
diff --git a/crates/catalog/src/dates.rs b/crates/catalog/src/dates.rs
index ca463dc55..2b71049ee 100644
--- a/crates/catalog/src/dates.rs
+++ b/crates/catalog/src/dates.rs
@@ -2,6 +2,7 @@
//! weekday and month names, shifting a time by an offset, and grouping a photo list into runs of
//! the same day / month / year (the date headers of the photo grid).
+use chrono::Datelike;
use serde::{Deserialize, Serialize};
pub use crate::stacks::iso_seconds;
@@ -11,32 +12,32 @@ pub const WEEKDAYS: [&str; 7] = ["Monday", "Tuesday", "Wednesday", "Thursday", "
pub const MONTHS: [&str; 12] =
["January", "February", "March", "April", "May", "June", "July", "August", "September", "October", "November", "December"];
-/// Unix seconds → `YYYY-MM-DDTHH:MM:SS` (proleptic Gregorian; H. Hinnant's algorithm).
+/// Unix seconds → `YYYY-MM-DDTHH:MM:SS` (UTC, proleptic Gregorian). A time outside chrono's year
+/// range still converts: the calendar repeats every 400 years, so the instant is moved into range
+/// by whole cycles and only the year is carried (matching the old `civil_from_days`), rather than
+/// resetting to the epoch. The callers here stay well inside years 0000–9999.
pub fn civil(secs: i64) -> String {
- let days = secs.div_euclid(86_400);
- let rem = secs.rem_euclid(86_400);
- let (y, m, d) = civil_from_days(days);
- format!("{y:04}-{m:02}-{d:02}T{:02}:{:02}:{:02}", rem / 3600, rem % 3600 / 60, rem % 60)
-}
-
-/// Days since 1970-01-01 → (year, month 1..=12, day 1..=31).
-pub fn civil_from_days(days: i64) -> (i64, i64, i64) {
- let z = days + 719_468;
- let era = z.div_euclid(146_097);
- let doe = z - era * 146_097;
- let yoe = (doe - doe / 1460 + doe / 36_524 - doe / 146_096) / 365;
- let doy = doe - (365 * yoe + yoe / 4 - yoe / 100);
- let mp = (5 * doy + 2) / 153;
- let d = doy - (153 * mp + 2) / 5 + 1;
- let m = if mp < 10 { mp + 3 } else { mp - 9 };
- (yoe + era * 400 + i64::from(m <= 2), m, d)
+ let (days, sod) = (secs.div_euclid(86_400), secs.rem_euclid(86_400));
+ let (cycles, rest) = (days.div_euclid(146_097), days.rem_euclid(146_097));
+ // `rest + 719_163` (1970-01-01 is CE day 719_163) is always a valid CE day, and `sod` < 86_400.
+ let date = i32::try_from(rest + 719_163).ok().and_then(chrono::NaiveDate::from_num_days_from_ce_opt);
+ let time = u32::try_from(sod).ok().and_then(|s| chrono::NaiveTime::from_num_seconds_from_midnight_opt(s, 0));
+ match (date, time) {
+ (Some(d), Some(t)) => {
+ let y = i128::from(d.year()) + i128::from(cycles) * 400;
+ let y = i64::try_from(y).unwrap_or(if y < 0 { i64::MIN } else { i64::MAX });
+ // `{:04}` rather than `%Y`, which writes a `+` before years past 9999 (the old `{y:04}` did not).
+ format!("{y:04}-{}", d.and_time(t).format("%m-%dT%H:%M:%S"))
+ }
+ _ => "1970-01-01T00:00:00".to_string(), // unreachable
+ }
}
/// Weekday name of an ISO date (`None` if it doesn't parse).
pub fn weekday(iso: &str) -> Option<&'static str> {
let days = iso_seconds(iso.get(..10)?)?.div_euclid(86_400);
- // 1970-01-01 was a Thursday
- Some(WEEKDAYS[(days + 3).rem_euclid(7) as usize])
+ let date = chrono::NaiveDate::from_num_days_from_ce_opt(i32::try_from(days.checked_add(719_163)?).ok()?)?;
+ Some(WEEKDAYS[date.weekday().num_days_from_monday() as usize])
}
/// Shift an ISO time by `secs`, keeping anything after the seconds (fractions, zone) as it was.
@@ -156,38 +157,56 @@ impl Catalog {
/// never split by a header. Empty for sort keys without a date and for [`GroupBy::None`]
/// ([`GroupBy::Auto`] means days here).
pub fn date_runs(&self, ids: &[PhotoId], key: SortKey, by: GroupBy) -> Vec {
- if by == GroupBy::None || ids.is_empty() {
+ if !groups_by_date(key, by) || ids.is_empty() {
return Vec::new();
}
- let n = by.prefix();
- let date_of = |id: &PhotoId| -> String {
- let Some(p) = self.photo(*id) else { return String::new() };
- let d = match key {
- SortKey::CaptureDate => p.captured.as_deref(),
- SortKey::ImportDate => Some(p.imported.as_str()),
- SortKey::EditDate => p.edited.as_deref(),
- _ => None,
- };
- d.filter(|d| iso_seconds(d.get(..10).unwrap_or("")).is_some()).and_then(|d| d.get(..n)).unwrap_or("").to_string()
- };
- if !matches!(key, SortKey::CaptureDate | SortKey::ImportDate | SortKey::EditDate) {
- return Vec::new();
- }
- let stacks = self.stack_index();
- let mut runs: Vec = Vec::new();
- let mut stack_key: std::collections::HashMap = Default::default();
- for (i, id) in ids.iter().enumerate() {
- let k = match stacks.get(id) {
- Some((sid, _)) => stack_key.entry(*sid).or_insert_with(|| date_of(id)).clone(),
- None => date_of(id),
- };
- match runs.last_mut() {
- Some(r) if r.key == k => r.count += 1,
- _ => runs.push(DateRun { label: group_label(&k), key: k, start: i, count: 1 }),
- }
- }
- runs
+ date_runs_of(ids, &self.stack_index(), |_, id| self.date_group(id, key, by))
}
+
+ /// The date group of photo `id` on its own for [`Catalog::date_runs`] (`2026-09-30` /
+ /// `2026-09` / `2026`; empty without a usable date): a stack's members take the group of its
+ /// first photo in the list there.
+ pub fn date_group(&self, id: PhotoId, key: SortKey, by: GroupBy) -> String {
+ let Some(p) = self.photo(id) else { return String::new() };
+ let d = match key {
+ SortKey::CaptureDate => p.captured.as_deref(),
+ SortKey::ImportDate => Some(p.imported.as_str()),
+ SortKey::EditDate => p.edited.as_deref(),
+ _ => None,
+ };
+ d.filter(|d| iso_seconds(d.get(..10).unwrap_or("")).is_some()).and_then(|d| d.get(..by.prefix())).unwrap_or("").to_string()
+ }
+}
+
+/// Whether [`Catalog::date_runs`] has runs for sort key `key` grouped `by`.
+pub fn groups_by_date(key: SortKey, by: GroupBy) -> bool {
+ by != GroupBy::None && matches!(key, SortKey::CaptureDate | SortKey::ImportDate | SortKey::EditDate)
+}
+
+/// [`Catalog::date_runs`] from each photo's own group (`group(position, id)`, see
+/// [`Catalog::date_group`]) and the stack index ([`Catalog::stack_index`]).
+pub fn date_runs_of>(
+ ids: &[PhotoId],
+ stacks: &std::collections::HashMap,
+ mut group: impl FnMut(usize, PhotoId) -> K,
+) -> Vec {
+ let mut runs: Vec = Vec::new();
+ let mut stack_key: std::collections::HashMap = Default::default();
+ for (i, id) in ids.iter().enumerate() {
+ let own;
+ let k: &str = match stacks.get(id) {
+ Some((sid, _)) => stack_key.entry(*sid).or_insert_with(|| group(i, *id).as_ref().to_string()),
+ None => {
+ own = group(i, *id);
+ own.as_ref()
+ }
+ };
+ match runs.last_mut() {
+ Some(r) if r.key == k => r.count += 1,
+ _ => runs.push(DateRun { label: group_label(k), key: k.to_string(), start: i, count: 1 }),
+ }
+ }
+ runs
}
#[cfg(test)]
@@ -199,6 +218,14 @@ mod tests {
fn calendar() {
assert_eq!(civil(0), "1970-01-01T00:00:00");
assert_eq!(civil(951_782_400), "2000-02-29T00:00:00");
+ // A year past 9999 keeps the plain zero-padded year (no `+`), as the old `{y:04}` did.
+ assert_eq!(civil(253_402_300_800), "10000-01-01T00:00:00");
+ // Beyond chrono's year range the old `civil_from_days` still converted; pin that output
+ // (never the epoch) in both directions and at the i64 extremes.
+ assert_eq!(civil(10_000_000_000_000), "318857-05-20T17:46:40");
+ assert_eq!(civil(-10_000_000_000_000), "-314918-08-13T06:13:20");
+ assert_eq!(civil(i64::MAX), "292277026596-12-04T15:30:07");
+ assert_eq!(civil(i64::MIN), "-292277022657-01-27T08:29:52");
assert_eq!(weekday("2026-09-30"), Some("Wednesday"));
assert_eq!(weekday("2026-10-01T09:00:00"), Some("Thursday"));
assert_eq!(weekday("2000-02-29"), Some("Tuesday"));
diff --git a/crates/catalog/src/model.rs b/crates/catalog/src/model.rs
index 6ac3544ee..b405e1db9 100644
--- a/crates/catalog/src/model.rs
+++ b/crates/catalog/src/model.rs
@@ -329,7 +329,7 @@ pub struct Analysis {
/// file's white balance is edited relative to its as-shot look or in Kelvin depends on the camera:
/// [`relative_wb_camera`].
pub fn relative_wb_format(format: &str) -> bool {
- ["ARW", "NEF", "NRW", "RW2", "RWL", "RAW", "RAF", "CR3", "CR2", "PEF", "SRW", "ORF", "ERF"].iter().any(|f| format.eq_ignore_ascii_case(f))
+ ["ARW", "NEF", "NRW", "RW2", "RWL", "RAW", "RAF", "CR3", "CR2", "PEF", "SRW", "ORF", "ERF", "MRW"].iter().any(|f| format.eq_ignore_ascii_case(f))
}
/// Whether a raw of `format` shot on `camera` (Exif make and model, as [`Meta::camera`] keeps them) is developed
@@ -610,6 +610,7 @@ mod edited_tests {
("a.pef", "pef", true),
("a.orf", "ORF", true),
("a.erf", "ERF", true),
+ ("a.mrw", "MRW", true),
("a.dng", "DNG", false),
] {
let mut p = Photo::new(PhotoId(1), Source::Demo { scene: 0 }, name, format, 10, 10, "2026-10-01T00:00:00");
@@ -653,6 +654,7 @@ mod edited_tests {
("SONY ILCE-1", "ARW", true),
("", "ARW", true),
("SONY ILCE-7M3", "DNG", false),
+ ("NIKON CORPORATION NIKON Z5_2", "NEF", false),
] {
let mut p = Photo::new(PhotoId(1), Source::Demo { scene: 0 }, "a.raw", format, 10, 10, "2026-10-01T00:00:00");
p.kind = MediaKind::Raw;
diff --git a/crates/catalog/src/query.rs b/crates/catalog/src/query.rs
index 7625c9ab6..a94421369 100644
--- a/crates/catalog/src/query.rs
+++ b/crates/catalog/src/query.rs
@@ -141,9 +141,40 @@ pub(crate) struct Prepared {
only: Option>,
}
+/// The tokens of a search text: split at whitespace, except inside double quotes, so
+/// `person:"Jane Doe"` is one token (issue #1449). An unclosed quote runs to the end of the text; a
+/// backslash is an ordinary character. One pass over the text, nothing allocated.
+fn search_tokens(text: &str) -> impl Iterator- {
+ let mut rest = text;
+ std::iter::from_fn(move || {
+ rest = rest.trim_start();
+ if rest.is_empty() {
+ return None;
+ }
+ let mut quoted = false;
+ let end = rest
+ .char_indices()
+ .find(|&(_, c)| {
+ quoted ^= c == '"';
+ !quoted && c.is_whitespace()
+ })
+ .map_or(rest.len(), |(i, _)| i);
+ let (tok, tail) = rest.split_at(end);
+ rest = tail;
+ Some(tok)
+ })
+}
+
+/// `s` without the double quotes around it (a missing closing quote is allowed).
+fn unquote(s: &str) -> &str {
+ s.strip_prefix('"').map_or(s, |inner| inner.strip_suffix('"').unwrap_or(inner))
+}
+
fn token_matches(p: &Photo, tok: &str) -> bool {
let t = tok.to_lowercase();
- if let Some((field, val)) = t.split_once(':') {
+ // a token that starts with a quote is a phrase, even with a colon in it
+ if let Some((field, quoted)) = t.split_once(':').filter(|_| !t.starts_with('"')) {
+ let val = unquote(quoted);
let num = |s: &str| -> Option<(char, f64)> {
let (op, rest) = match s.chars().next()? {
c @ ('>' | '<' | '=') => (c, &s[1..]),
@@ -180,18 +211,22 @@ fn token_matches(p: &Photo, tok: &str) -> bool {
"date" => p.captured.as_deref().is_some_and(|c| c.starts_with(val)),
"copy" | "virtual" => (val == "true" || val == "yes") == p.copy_of.is_some(),
"name" | "file" => p.file_name.to_lowercase().contains(val),
- // Not a known field: the colon is part of a plain word ("10:30", "Re:").
+ // Not a known field: the colon is part of a plain word ("10:30", "Re:"), its value unquoted
+ // (`re:"a b"` is the text `re:a b`).
+ _ if val.len() != quoted.len() => text_matches(p, &format!("{field}:{val}")),
_ => text_matches(p, &t),
};
}
- text_matches(p, &t)
+ text_matches(p, unquote(&t))
}
/// Whether the lower-cased word `t` is in the file name, title, caption, camera, lens, location,
-/// format or a keyword of `p`.
+/// format, a keyword or the name of a person (a named face) of `p`.
fn text_matches(p: &Photo, t: &str) -> bool {
let hay = [&p.file_name, &p.meta.title, &p.meta.caption, &p.meta.camera, &p.meta.lens, &p.meta.location, &p.format];
- hay.iter().any(|h| h.to_lowercase().contains(t)) || p.meta.keywords.iter().any(|k| k.to_lowercase().contains(t))
+ hay.iter().any(|h| h.to_lowercase().contains(t))
+ || p.meta.keywords.iter().any(|k| k.to_lowercase().contains(t))
+ || p.people().iter().any(|n| n.to_lowercase().contains(t))
}
/// Whether `p` has a named face region called `name` (case-insensitive).
@@ -409,7 +444,7 @@ impl Filter {
{
return false;
}
- self.text.split_whitespace().all(|tok| token_matches(p, tok))
+ search_tokens(&self.text).all(|tok| token_matches(p, tok))
}
}
diff --git a/crates/catalog/src/rules.rs b/crates/catalog/src/rules.rs
index a87c9effc..667509d6f 100644
--- a/crates/catalog/src/rules.rs
+++ b/crates/catalog/src/rules.rs
@@ -794,12 +794,90 @@ fn date_op(op: &str, have: Option<&str>, value: &Value) -> bool {
}
}
+/// One byte as the `filePath` rules compare it: `/` and `\` both separate, case doesn't matter.
+fn fold_path_byte(b: u8) -> u8 {
+ if b == b'\\' { b'/' } else { b.to_ascii_lowercase() }
+}
+
+/// Whether `a` and `b` are equal under [`fold_path_byte`].
+fn path_bytes_eq(a: &[u8], b: &[u8]) -> bool {
+ a.len() == b.len() && a.iter().zip(b).all(|(x, y)| fold_path_byte(*x) == fold_path_byte(*y))
+}
+
+/// `needle` inside `hay`, under [`fold_path_byte`]; allocates nothing.
+fn path_bytes_contains(hay: &[u8], needle: &[u8]) -> bool {
+ let Some((&first, rest)) = needle.split_first() else { return true };
+ // the spellings of the needle's first byte that fold to it: a plain two-way compare per byte
+ let (a, b) = match fold_path_byte(first) {
+ b'/' => (b'/', b'\\'),
+ c if c.is_ascii_lowercase() => (c, c.to_ascii_uppercase()),
+ c => (c, c),
+ };
+ let Some(starts) = hay.len().checked_sub(needle.len()).and_then(|last| hay.get(..=last)) else { return false };
+ let at = |i: usize, c: u8| (c == a || c == b) && hay.get(i + 1..i + needle.len()).is_some_and(|tail| path_bytes_eq(tail, rest));
+ // eight bytes at a time: does any of them spell the first byte (a zero byte after xor)?
+ const ONES: u64 = 0x0101_0101_0101_0101;
+ let has_zero = |v: u64| v.wrapping_sub(ONES) & !v & (ONES << 7) != 0;
+ let (chunks, tail) = starts.as_chunks::<8>();
+ let tail_from = starts.len() - tail.len();
+ for (k, chunk) in chunks.iter().enumerate() {
+ let w = u64::from_le_bytes(*chunk);
+ if (has_zero(w ^ (ONES * u64::from(a))) || has_zero(w ^ (ONES * u64::from(b)))) && chunk.iter().enumerate().any(|(j, &c)| at(k * 8 + j, c)) {
+ return true;
+ }
+ }
+ tail.iter().enumerate().any(|(j, &c)| at(tail_from + j, c))
+}
+
+/// A `filePath` rule. The common case (an ASCII path and an ASCII text) is compared in place, folding
+/// case and `\` as it goes, with nothing allocated per photo; any other text takes
+/// [`file_path_matches_slow`], so Unicode lower-casing (ß, İ, final sigma…) behaves as it always did.
+fn file_path_matches(op: &str, source: &Source, value: &Value) -> bool {
+ let path = match source {
+ Source::File { path } => path.as_str(),
+ Source::Demo { .. } => "",
+ };
+ let Value::String(want) = value else { return file_path_matches_slow(op, path, value) };
+ if !path.is_ascii() || !want.is_ascii() {
+ return file_path_matches_slow(op, path, value);
+ }
+ let (path, want) = (path.trim().as_bytes(), want.trim().as_bytes());
+ match op {
+ // the whole string, spaces included (not word by word like the other text fields)
+ "contains" => !want.is_empty() && path_bytes_contains(path, want),
+ "notContains" => want.is_empty() || !path_bytes_contains(path, want),
+ "is" => path_bytes_eq(path, want),
+ "isNot" => !path_bytes_eq(path, want),
+ "startsWith" => path.get(..want.len()).is_some_and(|head| path_bytes_eq(head, want)),
+ "endsWith" => path.len().checked_sub(want.len()).and_then(|from| path.get(from..)).is_some_and(|tail| path_bytes_eq(tail, want)),
+ "isEmpty" => path.is_empty(),
+ "isNotEmpty" => !path.is_empty(),
+ _ => false,
+ }
+}
+
+/// [`file_path_matches`] for any text: the path and the text are normalised into new strings.
+fn file_path_matches_slow(op: &str, path: &str, value: &Value) -> bool {
+ // `/` and `\` both separate, whatever platform the catalog came from; demo photos have no path
+ let path = path.replace('\\', "/");
+ let want = lower(value).replace('\\', "/");
+ match op {
+ // the whole string, spaces included (not word by word like the other text fields)
+ "contains" => !want.trim().is_empty() && path.to_lowercase().contains(want.trim()),
+ "notContains" => want.trim().is_empty() || !path.to_lowercase().contains(want.trim()),
+ _ => text_op(op, &path, &want),
+ }
+}
+
impl Rule {
pub fn matches(&self, p: &Photo, cat: &Catalog) -> bool {
let (field, op, value) = match self {
Rule::Group { group } => return group.matches(p, cat),
Rule::Field { field, op, value } => (field.as_str(), op.as_str(), value),
};
+ if field == "filePath" {
+ return file_path_matches(op, &p.source, value);
+ }
let m = &p.meta;
let want = lower(value);
let text = |have: &str| text_op(op, have, &want);
@@ -854,20 +932,6 @@ impl Rule {
"fileName" => text(&p.file_name),
"extension" => text_op(op, p.extension(), want.trim_start_matches('.')),
"duration" => num_op(op, p.duration.filter(|d| d.is_finite()), value),
- "filePath" => {
- // `/` and `\` both separate, whatever platform the catalog came from; demo photos have no path
- let path = match &p.source {
- Source::File { path } => path.replace('\\', "/"),
- Source::Demo { .. } => String::new(),
- };
- let want = want.replace('\\', "/");
- match op {
- // the whole string, spaces included (not word by word like the other text fields)
- "contains" => !want.trim().is_empty() && path.to_lowercase().contains(want.trim()),
- "notContains" => want.trim().is_empty() || !path.to_lowercase().contains(want.trim()),
- _ => text_op(op, &path, &want),
- }
- }
"format" => text(&p.format),
"title" => text(&m.title),
"caption" => text(&m.caption),
@@ -1693,4 +1757,120 @@ mod tests {
assert_eq!(field_label("filePath"), Some("File Path"));
assert_eq!(field_label("nope"), None);
}
+
+ /// The `filePath` rule exactly as it was before the in-place ASCII path: new strings per photo.
+ fn file_path_old(op: &str, source: &Source, value: &serde_json::Value) -> bool {
+ let want = lower(value);
+ let path = match source {
+ Source::File { path } => path.replace('\\', "/"),
+ Source::Demo { .. } => String::new(),
+ };
+ let want = want.replace('\\', "/");
+ match op {
+ "contains" => !want.trim().is_empty() && path.to_lowercase().contains(want.trim()),
+ "notContains" => want.trim().is_empty() || !path.to_lowercase().contains(want.trim()),
+ _ => text_op(op, &path, &want),
+ }
+ }
+
+ #[test]
+ fn file_path_rules_match_the_old_strings_for_any_path() {
+ let paths = [
+ "",
+ " ",
+ " /a/b.jpg \t",
+ "/Volumes/share/photos/Trip/IMG_0001.jpg",
+ "/Volumes/share/PHOTOS/trip/img_0001.JPG",
+ r"D:\Photos\Lake Como\IMG_0001.JPG",
+ r"d:/photos/lake como/img_0001.jpg",
+ r"\\nas\share\x.jpg",
+ "/photos/Straße/a.jpg",
+ "/photos/STRASSE/a.jpg",
+ "/photos/İstanbul/a.jpg",
+ "/photos/i̇stanbul/a.jpg",
+ "/photos/ΟΔΟΣ/a.jpg",
+ "/photos/οδος/a.jpg",
+ "/photos/ΟΔΌΣ/a.jpg",
+ "/photos/日本/東京.jpg",
+ "/p/\u{0B}x\u{0B}",
+ "/p/\u{85}x\u{85}",
+ "a",
+ ];
+ let wants = [
+ "",
+ " ",
+ "a",
+ "A",
+ "/",
+ r"\",
+ r"\photos\",
+ "/photos/",
+ "photos",
+ "PHOTOS",
+ "Lake Como",
+ " lake como ",
+ "lake como",
+ r"d:\photos\lake",
+ "IMG_0001.JPG",
+ ".jpg",
+ "straße",
+ "STRASSE",
+ "strasse",
+ "İstanbul",
+ "i̇stanbul",
+ "istanbul",
+ "ΟΔΟΣ",
+ "οδος",
+ "οδοσ",
+ "ΟΔΌΣ",
+ "東京",
+ "日本",
+ "x",
+ "\u{0B}x",
+ "/a/b.jpg",
+ "/a/b.jpg \t",
+ "\u{85}x",
+ ];
+ let ops = ["contains", "notContains", "is", "isNot", "startsWith", "endsWith", "isEmpty", "isNotEmpty", "bogus"];
+ let mut values: Vec
= wants.iter().map(|w| json!(w)).collect();
+ values.extend([json!(null), json!(5), json!(true), json!(["a", "b"])]);
+ let mut sources: Vec = paths.iter().map(|p| Source::File { path: (*p).into() }).collect();
+ sources.push(Source::Demo { scene: 0 });
+ for source in &sources {
+ for op in ops {
+ for value in &values {
+ assert_eq!(file_path_matches(op, source, value), file_path_old(op, source, value), "{source:?} {op} {value}");
+ }
+ }
+ }
+ }
+
+ #[test]
+ fn file_path_rule_through_a_rule_set_ignores_case_and_slash_direction() {
+ let mut p = photo(1);
+ p.source = Source::File { path: r"D:\Photos\Lake Como\IMG_0001.JPG".into() };
+ let r = rs(json!({"rules": [{"field": "filePath", "op": "contains", "value": "/LAKE como/"}]}));
+ assert!(r.matches(&p, &Catalog::default()));
+ }
+
+ /// Every piece of a long path, in both cases and both slash directions, wherever it starts
+ /// (the search skips eight bytes at a time, so starts and ends at every offset matter).
+ #[test]
+ fn file_path_contains_finds_every_piece_of_a_long_path() {
+ let path = r"D:\Photos\Lake Como\Wedding-Day_2026\IMG_0001 (copy).JPG";
+ let source = Source::File { path: path.into() };
+ let shout = |s: &str| s.to_uppercase();
+ let swap = |s: &str| s.replace('\\', "/");
+ for from in 0..path.len() {
+ for to in from + 1..=path.len() {
+ let piece = &path[from..to];
+ for want in [piece.to_string(), shout(piece), swap(piece), piece.replace('/', r"\"), format!("{piece}x"), format!("x{piece}")] {
+ let value = json!(want);
+ for op in ["contains", "notContains"] {
+ assert_eq!(file_path_matches(op, &source, &value), file_path_old(op, &source, &value), "{op} {want:?}");
+ }
+ }
+ }
+ }
+ }
}
diff --git a/crates/catalog/src/stacks.rs b/crates/catalog/src/stacks.rs
index 6542bfe18..84e89d124 100644
--- a/crates/catalog/src/stacks.rs
+++ b/crates/catalog/src/stacks.rs
@@ -299,14 +299,12 @@ pub fn iso_seconds(s: &str) -> Option {
if hh >= 24 || mm >= 60 || ss >= 60 {
return None;
}
- // days from civil (proleptic Gregorian)
- let y2 = if m <= 2 { y - 1 } else { y };
- let era = y2.div_euclid(400);
- let yoe = y2 - era * 400;
- let mp = (m + 9) % 12;
- let doy = (153 * mp + 2) / 5 + d - 1;
- let doe = yoe * 365 + yoe / 4 - yoe / 100 + doy;
- let days = era * 146_097 + doe - 719_468;
+ // Days since 1970-01-01 (proleptic Gregorian). A day past the month's length rolls over the
+ // way the old Hinnant arithmetic did (e.g. 2026-02-30 → 2026-03-02), which `normalize_iso`
+ // relies on to reject impossible dates.
+ let first = chrono::NaiveDate::from_ymd_opt(i32::try_from(y).ok()?, u32::try_from(m).ok()?, 1)?;
+ let date = first.checked_add_days(chrono::Days::new(u64::try_from(d - 1).ok()?))?;
+ let days = (date - chrono::NaiveDate::from_ymd_opt(1970, 1, 1)?).num_days();
Some(days * 86_400 + hh * 3600 + mm * 60 + ss)
}
diff --git a/crates/catalog/src/tests.rs b/crates/catalog/src/tests.rs
index a32b5acf5..f8b72dad8 100644
--- a/crates/catalog/src/tests.rs
+++ b/crates/catalog/src/tests.rs
@@ -836,6 +836,71 @@ fn cmp_name_ignores_case_without_allocating() {
assert_eq!(cmp_name("a", "ab"), Less);
}
+/// Search Photos finds named people in free text, and a quoted value keeps a name of several words
+/// together: `person:"Jane Doe"` (issue #1449). Malformed quotes narrow the result or change nothing.
+#[test]
+fn search_text_finds_people_and_quoted_values() {
+ use lightcraft_meta::{Rect, Region, RegionKind};
+ let region = |name: &str, kind: RegionKind| Region {
+ rect: Rect { x0: 0.4, y0: 0.4, x1: 0.6, y1: 0.6 },
+ kind,
+ name: Some(name.to_string()),
+ description: None,
+ };
+ let mut c = Catalog::new();
+ let mut add = |name: &str, regions: Vec, keywords: &[&str]| {
+ let id = c.alloc_photo_id();
+ let mut p = Photo::new(id, Source::Demo { scene: 1 }, name, "JPEG", 6000, 4000, "2026-09-30T10:00:00");
+ p.meta.regions = regions;
+ p.meta.keywords = keywords.iter().map(|k| k.to_string()).collect();
+ c.apply(Op::AddPhoto { photo: Box::new(p) }).unwrap();
+ id
+ };
+ let jane = add("a.jpg", vec![region("Jane Doe", RegionKind::Face), region("Rex", RegionKind::Pet)], &[]);
+ let both = add("b.jpg", vec![region("Jane Roe", RegionKind::Face), region("John Doe", RegionKind::Face)], &[]);
+ let zoe = add("c.jpg", vec![region("Zoë Ångström", RegionKind::Face)], &["New York"]);
+ let none = add("lunch 10:30 am.jpg", vec![], &["york minster"]);
+ let q = |text: &str| {
+ let mut ids = c.query(&Filter { text: text.into(), ..Default::default() }, &Sort::default());
+ ids.sort();
+ ids
+ };
+
+ // free text: a person's name, any case, any part of it; pets are not people
+ assert_eq!(q("jane"), vec![jane, both]);
+ assert_eq!(q("DOE"), vec![jane, both]);
+ assert_eq!(q("ångström"), vec![zoe]);
+ assert!(q("rex").is_empty(), "a pet is not a person");
+ // words are still ANDed: b.jpg has a Jane and a Doe, a quoted phrase asks for them together
+ assert_eq!(q("jane doe"), vec![jane, both]);
+ assert_eq!(q("\"jane doe\""), vec![jane]);
+
+ // fielded: the exact name, of several words when quoted
+ assert_eq!(q("person:\"Jane Doe\""), vec![jane]);
+ assert_eq!(q("who:\"jane roe\""), vec![both]);
+ assert_eq!(q("person:\"Zoë Ångström\""), vec![zoe]);
+ assert!(q("person:jane").is_empty(), "person: is the whole name, as before");
+ assert!(q("person:Jane Doe").is_empty(), "unquoted, the second word is its own token, as before");
+ assert_eq!(q("keyword:\"new york\""), vec![zoe], "other fields take quoted values too");
+ assert_eq!(q("person:\"Jane Doe\" a.jpg"), vec![jane], "tokens after a quoted one still count");
+
+ // malformed input never widens the match and never panics
+ assert_eq!(q("person:\"Jane Doe"), vec![jane], "an unclosed quote runs to the end");
+ assert!(q("person:\"Jane Doe a.jpg").is_empty(), "…and takes the rest of the text with it");
+ assert!(q("person:\"\"").is_empty());
+ assert!(q("person:").is_empty());
+ assert_eq!(q("\""), vec![jane, both, zoe, none], "a lone quote is an empty phrase, like an empty search");
+ assert_eq!(q("\"\" jane"), vec![jane, both]);
+ assert!(q("\"jane:doe\"").is_empty(), "a quoted phrase is free text even with a colon");
+ // an unknown field is plain text, its quoted value unquoted (#2099): `10:"30 am"` is the text `10:30 am`
+ assert_eq!(q("10:\"30 am\""), vec![none]);
+ assert!(q("10:\"30 pm\"").is_empty());
+ assert!(q("jane\\\"").is_empty(), "a backslash is an ordinary character");
+ let long = format!("person:\"{}", "é ".repeat(50_000));
+ assert!(q(&long).is_empty());
+ assert_eq!(q(" \t jane \u{3000} "), vec![jane, both], "any whitespace separates tokens");
+}
+
/// What the catalog remembers of its latest ops: which photos each changed and what of them, as long as that can be
/// said photo by photo.
#[test]
diff --git a/crates/engine/Cargo.toml b/crates/engine/Cargo.toml
index 091efe066..9caa8cdb0 100644
--- a/crates/engine/Cargo.toml
+++ b/crates/engine/Cargo.toml
@@ -46,6 +46,8 @@ lightcraft-segment = { workspace = true, optional = true }
# model downloads run natively only (the web build fetches no models)
[target.'cfg(not(target_arch = "wasm32"))'.dependencies]
lightcraft-fetch = { workspace = true }
+# capture-time parsing for face recognition (native only)
+chrono = { workspace = true }
[features]
# AI masks with SAM 3 (Object / Describe). Off for the web and CLI builds.
diff --git a/crates/engine/src/camera_preview.rs b/crates/engine/src/camera_preview.rs
index e56e80305..d074567a7 100644
--- a/crates/engine/src/camera_preview.rs
+++ b/crates/engine/src/camera_preview.rs
@@ -35,7 +35,11 @@ use lightcraft_raw::{
/// 8: the bundled NIKON Z 6_2 profile.
/// 9: the bundled NIKON Z 8 and NIKON D5300 profiles.
/// 10: DNG tone fit for profiles with a look table and for 1024 px (Lightroom) previews.
-pub const LOOK_VERSION: u32 = 10;
+/// 12: tone curves of low-contrast scenes (range limit 1.2, with the bright-area check for curves under 1.5, #699);
+/// a tone-only fallback for near-black scenes with too few colour pairs (#1587); DNG tone fitting uses a
+/// lens-corrected proxy when the file carries lens opcodes; validated A7CR distortion, including the lens data
+/// stored with each smart preview.
+pub const LOOK_VERSION: u32 = 12;
#[derive(Clone, Debug)]
pub(crate) struct CameraLook {
@@ -68,6 +72,7 @@ pub(crate) fn file_local_look(format: RawFormat) -> bool {
| RawFormat::Pef
| RawFormat::Srw
| RawFormat::Orf
+ | RawFormat::Mrw
| RawFormat::Erf
)
}
@@ -89,7 +94,18 @@ pub(crate) fn starting_colour(
lens: Option<&LensGeometry>,
embedded: Option<&lightcraft_develop::EmbeddedLens>,
) -> (Xy, CameraTransform, Option) {
- let (xy, t, look) = starting_colour_with(raw, |raw, t| fit_preview(raw, bytes, t, lens), |raw, t| monochrome_look(raw, bytes, t, lens));
+ let (xy, t, look) = starting_colour_with(
+ raw,
+ |raw, t| fit_preview(raw, bytes, t, lens),
+ |raw, t| monochrome_look(raw, bytes, t, lens),
+ |raw, t| {
+ if !file_local_look(raw.format) {
+ return None;
+ }
+ let (sensor, reference, clipped) = proxies(raw, bytes, t, PROXY, 0.0, lens)?;
+ fit_dark_tone(&sensor, &reference, &clipped)
+ },
+ );
if look.is_none() && dng_tone_eligible(raw, &t) {
let look = fit_dng_tone(raw, bytes, &t, embedded);
return (xy, t, look);
@@ -118,11 +134,12 @@ pub(crate) fn dng_tone_eligible(raw: &RawImage, t: &CameraTransform) -> bool {
}
/// [`starting_colour`] with the JPEG fit (the look, and whether the JPEG is black and white) and the black-and-white
-/// JPEG's tone fit passed in (tests pin the order with them).
+/// JPEG's tone fit and the near-black tone fallback passed in (tests pin the order with them).
fn starting_colour_with(
raw: &mut RawImage,
fit: impl FnOnce(&RawImage, &CameraTransform) -> (Option, bool),
monochrome: impl FnOnce(&RawImage, &CameraTransform) -> Option,
+ dark: impl FnOnce(&RawImage, &CameraTransform) -> Option,
) -> (Xy, CameraTransform, Option) {
let start = |raw: &RawImage| {
let xy = lightcraft_raw::color::as_shot_white_xy(raw);
@@ -146,9 +163,9 @@ fn starting_colour_with(
}
None => (xy, t),
};
- // only a black-and-white JPEG: a colour one that gave no look pays nothing more
+ // A black-and-white JPEG first tries its existing tone fit on the chosen colour.
let look = if black_and_white { monochrome(raw, &t) } else { None };
- (xy, t, look)
+ (xy, t, look.or_else(|| dark(raw, &t)))
}
/// The colour a raw starts from ([`starting_colour`]) as DNG colour tags, for a DNG of the raw's camera RGB (Photo
@@ -270,20 +287,21 @@ pub(crate) fn fit_preview(raw: &RawImage, bytes: &[u8], transform: &CameraTransf
// try its colour first and fit tone/chroma per photo (picture styles vary).
let profile = raw.metadata.model.as_deref().and_then(crate::camera_profiles::get);
let colour = profile.as_ref().and_then(|p| Some((p.matrix().mul(&transform.matrix.inverse()?), p.hue_sat.clone())));
- let look = match fit_look(&sensor, &reference, &clipped, colour.clone()) {
+ // Sony's Dynamic Range Optimizer (on by default) brightens the camera JPEG's darker regions,
+ // not the raw: keep the colour fitted to the JPEG, take the tone curve without DRO.
+ let dro = lightcraft_raw::embedded_preview_dynamic_range_optimized(bytes) == Some(true);
+ let look = match fit_look_with(&sensor, &reference, &clipped, colour.clone(), dro) {
Some(look) => look,
// A black-and-white JPEG has no colour to fit: the profile's colour and the JPEG's tone curve
// (`monochrome_look` does it without a profile).
None if colour.is_some() && black_and_white => {
let unclipped = without_clipped(&sensor, &clipped);
- let Some(look) = fit_tone_only(unclipped.as_ref().unwrap_or(&sensor), &reference, colour) else { return (None, true) };
+ let bright = HighlightCheck { pairs: highlights(&sensor, &reference), dro, grey: true };
+ let Some(look) = fit_tone_only_with(unclipped.as_ref().unwrap_or(&sensor), &reference, colour, &bright) else { return (None, true) };
look
}
None => return (None, black_and_white),
};
- // Sony's Dynamic Range Optimizer (on by default) brightens the camera JPEG's darker regions,
- // not the raw: keep the colour fitted to the JPEG, take the tone curve without DRO.
- let dro = lightcraft_raw::embedded_preview_dynamic_range_optimized(bytes) == Some(true);
let look = if dro { with_dro_off_tone(look) } else { look };
if lightcraft_pipeline::profiling() {
eprintln!(
@@ -302,6 +320,12 @@ pub(crate) fn fit_preview(raw: &RawImage, bytes: &[u8], transform: &CameraTransf
/// the render's highlight reconstruction.
const SENSOR_CLIP: f32 = 0.99;
+/// [`fit_look_with`] for a photo without Sony's DRO.
+#[cfg(test)]
+fn fit_look(sensor: &Rgb32f, reference: &Rgb32f, clipped: &[bool], colour: Option<(Mat3, Option)>) -> Option {
+ fit_look_with(sensor, reference, clipped, colour, false)
+}
+
/// The photo's look, refitted without the proxy pixels whose sensor values are clipped.
///
/// A clipped raw pixel no longer records the scene's colour: with one channel held at the clip
@@ -320,17 +344,19 @@ const SENSOR_CLIP: f32 = 0.99;
/// replace a look fitted away from edges). A photo that had no look gets one when the search
/// without the clipped pixels finds it, and otherwise the [`fit_partial`] look when that is clearly
/// closer to the camera JPEG than the neutral fallback.
-fn fit_look(sensor: &Rgb32f, reference: &Rgb32f, clipped: &[bool], colour: Option<(Mat3, Option)>) -> Option {
+fn fit_look_with(sensor: &Rgb32f, reference: &Rgb32f, clipped: &[bool], colour: Option<(Mat3, Option)>, dro: bool) -> Option {
let unclipped = without_clipped(sensor, clipped);
- let Some((look, attempt)) = search_ordered(sensor, reference, colour.clone(), TONE_FITS) else {
+ // from the proxies as they are: the retries' filters (clipped pixels, edges) don't remove them
+ let bright = HighlightCheck { pairs: highlights(sensor, reference), dro, grey: false };
+ let Some((look, attempt)) = search_ordered(sensor, reference, colour.clone(), TONE_FITS, &bright) else {
return unclipped
.as_ref()
- .and_then(|u| search_ordered(u, reference, colour, TONE_FITS))
+ .and_then(|u| search_ordered(u, reference, colour, TONE_FITS, &bright))
.map(|(look, _)| look)
- .or_else(|| fit_partial(unclipped.as_ref().unwrap_or(sensor), reference));
+ .or_else(|| fit_partial(unclipped.as_ref().unwrap_or(sensor), reference, &bright));
};
let Some(unclipped) = unclipped else { return Some(look) };
- let refit = fit_attempt(&unclipped, reference, &colour, attempt);
+ let refit = fit_attempt(&unclipped, reference, &colour, attempt, &bright);
if refit.is_none() && lightcraft_pipeline::profiling() {
eprintln!("[profile] camera look: no fit without the clipped pixels on the accepted attempt, keeping the fit on all pixels");
}
@@ -389,8 +415,14 @@ fn sony_dro_off_tone() -> Option {
/// curve is brighter than the photo's own (the 1″ compacts map raw values darker), the photo keeps
/// its own. Its colour (matrix, hue/saturation table and chroma curve) stays as fitted.
fn with_dro_off_tone(look: CameraLook) -> CameraLook {
- let Some(dro_off) = sony_dro_off_tone() else { return look };
- let own = look.tone.knots();
+ CameraLook { tone: dro_off(&look.tone), ..look }
+}
+
+/// The curve of [`with_dro_off_tone`]: `own` lowered to Sony's without DRO wherever that is darker,
+/// or `own` unchanged when it can't be.
+fn dro_off(own_tone: &CameraTone) -> CameraTone {
+ let Some(dro_off) = sony_dro_off_tone() else { return *own_tone };
+ let own = own_tone.knots();
let mut knots = own.map(|[x, y]| [x, y.min(dro_off.apply(x))]);
// Past its last knot a curve goes on as a shoulder whose rate comes from its last two knots
// (`CameraTone::apply`): lowering the second-last knot more than the last steepens it, and the
@@ -400,11 +432,11 @@ fn with_dro_off_tone(look: CameraLook) -> CameraLook {
let rate = ((b[1] - a[1]) / (b[0] - a[0])).clamp(0.1, 16.0) / (1.0 - b[1]).max(0.01);
let floor = last[1] - rate * (1.0 - last[1]).max(0.01) * (b[0] - a[0]);
knots[30][1] = knots[30][1].max(floor).min(last[1]);
- let Some(tone) = CameraTone::new(knots).and_then(|tone| tone.with_chroma(*look.tone.chroma())) else { return look };
- if !at_most(&tone, &look.tone) {
- return look;
+ let Some(tone) = CameraTone::new(knots).and_then(|tone| tone.with_chroma(*own_tone.chroma())) else { return *own_tone };
+ if !at_most(&tone, own_tone) {
+ return *own_tone;
}
- CameraLook { tone, ..look }
+ tone
}
/// Whether curve `a` is nowhere brighter than `b` over the scene luminances the finish stage's tone
@@ -452,10 +484,11 @@ fn fit_dng_tone(raw: &RawImage, bytes: &[u8], transform: &CameraTransform, lens:
let unclipped = without_clipped(&sensor, &clipped);
let fit_on = unclipped.as_ref().unwrap_or(&sensor);
let colour = Some((Mat3::IDENTITY, None));
+ let bright = HighlightCheck { pairs: highlights(&sensor, &reference), dro: false, grey: false };
let look = TONE_FITS.iter().find_map(|&tone| {
- [false, true]
- .into_iter()
- .find_map(|away_from_edges| fit_attempt(fit_on, &reference, &colour, Attempt { tone, profile: true, away_from_edges, dark: true }))
+ [false, true].into_iter().find_map(|away_from_edges| {
+ fit_attempt(fit_on, &reference, &colour, Attempt { tone, profile: true, away_from_edges, dark: true }, &bright)
+ })
});
let Some(look) = look else { return refuse("fit") };
let plain = match raw.color.profile.tone_curve.as_ref().and_then(crate::files::dng_tone_curve) {
@@ -928,7 +961,10 @@ fn into_lens_geometry(img: &Rgb32f, raw: &RawImage, k: usize, lens: &LensGeometr
fn sensor_proxy(raw: &RawImage, k: usize, edge: usize) -> Option {
Some(match raw.develop_binned(k, SENSOR_CLIP).ok()? {
Some(sensor) => sensor,
- None if raw.cpp == 3 && raw.cfa.is_none() => fit(&raw.develop(lightcraft_raw::Method::Bilinear).ok()?, edge, edge, Filter::Box),
+ // Lens opcodes cannot be applied to a binned mosaic: they are defined at full resolution.
+ None if (raw.cpp == 3 && raw.cfa.is_none()) || (raw.format == RawFormat::Dng && !raw.opcodes.list3.is_empty()) => {
+ fit(&raw.develop(lightcraft_raw::Method::Bilinear).ok()?, edge, edge, Filter::Box)
+ }
None => return None,
})
}
@@ -985,7 +1021,8 @@ fn local_contrast(image: &Rgb32f, i: usize) -> f32 {
/// `edge_limit`, pixels whose 3×3 neighbourhood in either proxy spans a larger luminance ratio
/// are left out: there a small geometric mismatch between the raw and its JPEG pairs unrelated
/// colours (see [`EDGE_CONTRAST`]).
-type Pairs = Vec<([f64; 3], [f64; 3])>;
+type Pair = ([f64; 3], [f64; 3]);
+type Pairs = Vec;
fn collect_pairs(sensor: &Rgb32f, reference: &Rgb32f, min_chroma: f32, edge_limit: Option, dark: bool) -> Option<(Pairs, Pairs)> {
if (sensor.width, sensor.height) != (reference.width, reference.height) || sensor.data.len() != reference.data.len() {
return None;
@@ -1147,7 +1184,8 @@ fn fit_pairs_with(sensor: &Rgb32f, reference: &Rgb32f, colour: Option<(Mat3, Opt
/// The look from [`search_ordered`] without its attempt.
#[cfg(test)]
fn fit_pairs_ordered(sensor: &Rgb32f, reference: &Rgb32f, colour: Option<(Mat3, Option)>, order: &[ToneFit]) -> Option {
- search_ordered(sensor, reference, colour, order).map(|(look, _)| look)
+ search_ordered(sensor, reference, colour, order, &HighlightCheck { pairs: highlights(sensor, reference), dro: false, grey: false })
+ .map(|(look, _)| look)
}
/// The tone fits the search tries, in order: the first whose look passes the acceptance gates is
@@ -1177,21 +1215,33 @@ struct Attempt {
/// valid when the camera JPEG's geometry differs slightly from the raw's (issue #232). The whole
/// search runs with one tone fit before the next is tried, so the conditional-median fallback
/// accepts exactly what the previous releases accepted.
-fn search_ordered(sensor: &Rgb32f, reference: &Rgb32f, colour: Option<(Mat3, Option)>, order: &[ToneFit]) -> Option<(CameraLook, Attempt)> {
+fn search_ordered(
+ sensor: &Rgb32f,
+ reference: &Rgb32f,
+ colour: Option<(Mat3, Option)>,
+ order: &[ToneFit],
+ bright: &HighlightCheck,
+) -> Option<(CameraLook, Attempt)> {
let profiles: &[bool] = if colour.is_some() { &[true, false] } else { &[false] };
order.iter().find_map(|&tone| {
profiles.iter().find_map(|&profile| {
[false, true].into_iter().find_map(|away_from_edges| {
let attempt = Attempt { tone, profile, away_from_edges, dark: false };
- fit_attempt(sensor, reference, &colour, attempt).map(|look| (look, attempt))
+ fit_attempt(sensor, reference, &colour, attempt, bright).map(|look| (look, attempt))
})
})
})
}
-fn fit_attempt(sensor: &Rgb32f, reference: &Rgb32f, colour: &Option<(Mat3, Option)>, attempt: Attempt) -> Option {
+fn fit_attempt(
+ sensor: &Rgb32f,
+ reference: &Rgb32f,
+ colour: &Option<(Mat3, Option)>,
+ attempt: Attempt,
+ bright: &HighlightCheck,
+) -> Option {
let colour = if attempt.profile { colour.clone() } else { None };
- fit_pairs_on(sensor, reference, colour, attempt.away_from_edges.then_some(EDGE_CONTRAST), attempt.tone, attempt.dark)
+ fit_pairs_on(sensor, reference, colour, attempt.away_from_edges.then_some(EDGE_CONTRAST), attempt.tone, attempt.dark, bright)
}
fn fit_pairs_on(
@@ -1201,6 +1251,7 @@ fn fit_pairs_on(
edge_limit: Option,
tone_fit: ToneFit,
dark: bool,
+ highlights: &HighlightCheck,
) -> Option {
// A known colour model needs enough signal for tone fitting, not a scene rich enough to
// learn a new colour matrix. Still reject monochrome references.
@@ -1228,6 +1279,9 @@ fn fit_pairs_on(
look.tone = tone;
}
let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ if !highlights_hold(&look.tone, highlights, colour) {
+ continue;
+ }
let (mut linear, mut perceptual, mut samples) = (0.0, 0.0, 0);
for (x, target) in pairs.iter().step_by(3) {
let corrected = displayed(colour(*x), &tone);
@@ -1342,11 +1396,11 @@ fn rank_correlation_ties(pairs: &[([f64; 3], [f64; 3])]) -> f64 {
/// and in gamma-encoded display values, and when the JPEG shows the same picture
/// ([`PARTIAL_MIN_RANK_CORRELATION`]). There is no limit on its own error: it only has to be clearly
/// closer to the camera JPEG than what the photo would get otherwise.
-fn fit_partial(sensor: &Rgb32f, reference: &Rgb32f) -> Option {
- [None, Some(EDGE_CONTRAST)].into_iter().find_map(|edge_limit| fit_partial_on(sensor, reference, edge_limit))
+fn fit_partial(sensor: &Rgb32f, reference: &Rgb32f, highlights: &HighlightCheck) -> Option {
+ [None, Some(EDGE_CONTRAST)].into_iter().find_map(|edge_limit| fit_partial_on(sensor, reference, edge_limit, highlights))
}
-fn fit_partial_on(sensor: &Rgb32f, reference: &Rgb32f, edge_limit: Option) -> Option {
+fn fit_partial_on(sensor: &Rgb32f, reference: &Rgb32f, edge_limit: Option, highlights: &HighlightCheck) -> Option {
// as for a known colour model: enough signal for the tone, but no monochrome reference
let (pairs, bright) = collect_pairs(sensor, reference, 0.005, edge_limit, false)?;
let related = rank_correlation(&pairs);
@@ -1370,6 +1424,9 @@ fn fit_partial_on(sensor: &Rgb32f, reference: &Rgb32f, edge_limit: Option)
look.tone = tone;
}
let (tone, neutral) = (ToneMap::camera(&look.tone, 0.0, 0.0, 0.0), ToneMap::new(0.0, 0.0, 0.0));
+ if !highlights_hold(&look.tone, highlights, |x| matrix.apply(x)) {
+ return None;
+ }
let encoded = |v: f64| v.max(0.0).powf(1.0 / 2.2);
let (mut before, mut after, mut before_encoded, mut after_encoded, mut samples) = (0.0, 0.0, 0.0, 0.0, 0);
for (x, target) in pairs.iter().step_by(3) {
@@ -1420,7 +1477,7 @@ fn monochrome(reference: &Rgb32f) -> bool {
/// would start from the spectral matrices or the neutral fallback with the default tone curve, about 1.3 EV darker
/// and flatter than the same body's photos shot in colour. But the JPEG still shows the camera's tone curve.
/// `transform` is the colour the photo gets otherwise (the spectral matrices or the fallback's); the look keeps it and
-/// adds the tone curve alone ([`fit_tone_only`]), as [`fit_look`] tries the photo's own colour after a profile's. The
+/// adds the tone curve alone ([`fit_tone_only_with`]), as [`fit_look_with`] tries the photo's own colour after a profile's. The
/// chroma curve stays neutral: the JPEG has no colourfulness to learn.
fn monochrome_look(raw: &RawImage, bytes: &[u8], transform: &CameraTransform, lens: Option<&LensGeometry>) -> Option {
if !file_local_look(raw.format) {
@@ -1430,10 +1487,11 @@ fn monochrome_look(raw: &RawImage, bytes: &[u8], transform: &CameraTransform, le
if !monochrome(&reference) {
return None;
}
- let unclipped = without_clipped(&sensor, &clipped);
- let look = fit_tone_only(unclipped.as_ref().unwrap_or(&sensor), &reference, None)?;
// Sony's Dynamic Range Optimizer brightens a B/W JPEG as much as a colour one
let dro = lightcraft_raw::embedded_preview_dynamic_range_optimized(bytes) == Some(true);
+ let unclipped = without_clipped(&sensor, &clipped);
+ let bright = HighlightCheck { pairs: highlights(&sensor, &reference), dro, grey: true };
+ let look = fit_tone_only_with(unclipped.as_ref().unwrap_or(&sensor), &reference, None, &bright)?;
let look = if dro { with_dro_off_tone(look) } else { look };
if lightcraft_pipeline::profiling() {
eprintln!(
@@ -1450,18 +1508,103 @@ fn monochrome_look(raw: &RawImage, bytes: &[u8], transform: &CameraTransform, le
/// space) or, without one, of the sensor proxy's own colour. Fitted like [`fit_partial`]'s, by quantile matching of
/// the luminances, on all pixels and then away from edges, and used only when the JPEG shows the same picture
/// ([`PARTIAL_MIN_RANK_CORRELATION`]) and the look cuts the held-out squared luminance error to below
-/// [`MIN_IMPROVEMENT`] of the default curve's, in linear and in gamma-encoded display values.
-fn fit_tone_only(sensor: &Rgb32f, reference: &Rgb32f, colour: Option<(Mat3, Option)>) -> Option {
- [None, Some(EDGE_CONTRAST)].into_iter().find_map(|edge_limit| fit_tone_only_on(sensor, reference, &colour, edge_limit))
+/// [`MIN_IMPROVEMENT`] of the default curve's, in linear and in gamma-encoded display values. A curve narrower than
+/// [`NARROW_TONE_RANGE`] must also keep the JPEG's bright areas ([`highlights_hold`], by luminance).
+fn fit_tone_only_with(
+ sensor: &Rgb32f,
+ reference: &Rgb32f,
+ colour: Option<(Mat3, Option)>,
+ highlights: &HighlightCheck,
+) -> Option {
+ [None, Some(EDGE_CONTRAST)].into_iter().find_map(|edge_limit| fit_tone_only_on(sensor, reference, &colour, edge_limit, highlights))
}
-fn fit_tone_only_on(sensor: &Rgb32f, reference: &Rgb32f, colour: &Option<(Mat3, Option)>, edge_limit: Option) -> Option {
+/// [`fit_tone_only_with`] for a photo without Sony's DRO, checked against its own bright areas.
+#[cfg(test)]
+fn fit_tone_only(sensor: &Rgb32f, reference: &Rgb32f, colour: Option<(Mat3, Option)>) -> Option {
+ fit_tone_only_with(sensor, reference, colour, &HighlightCheck { pairs: highlights(sensor, reference), dro: false, grey: true })
+}
+
+fn fit_tone_only_on(
+ sensor: &Rgb32f,
+ reference: &Rgb32f,
+ colour: &Option<(Mat3, Option)>,
+ edge_limit: Option,
+ highlights: &HighlightCheck,
+) -> Option {
// every pair counts: the JPEG has no colour to require
let (pairs, _) = collect_pairs(sensor, reference, f32::NEG_INFINITY, edge_limit, false)?;
- let related = rank_correlation_ties(&pairs);
+ fit_tone_only_pairs(sensor, reference, colour, edge_limit, &pairs, false, highlights)
+}
+
+/// A near-black frame may have enough luminance signal for tone but fewer than 256 colour pairs.
+/// Try only after every existing look fails. Keep the colour of the source transform,
+/// exclude clipped pixels from training, and keep their luminance at least as close to the JPEG
+/// as the default curve does. Bright JPEGs need the existing fits to constrain their highlights.
+fn fit_dark_tone(sensor: &Rgb32f, reference: &Rgb32f, clipped: &[bool]) -> Option {
+ if (sensor.width, sensor.height) != (reference.width, reference.height)
+ || sensor.data.len() != reference.data.len()
+ || clipped.len() != sensor.data.len()
+ || sensor.data.is_empty()
+ || sensor.data.iter().any(|p| !p.iter().all(|v| v.is_finite()))
+ || reference.data.iter().any(|p| !p.iter().all(|v| v.is_finite() && *v >= 0.0) || luminance_2020(*p) >= 0.85)
+ {
+ return None;
+ }
+ let dark = reference.data.iter().filter(|p| luminance_2020(**p) < 0.015).count();
+ if (dark as f64) < reference.data.len() as f64 * 0.9 {
+ return None;
+ }
+ // no JPEG pixel reaches 0.85 here, so the bright-area check has nothing to hold
+ let bright = HighlightCheck { pairs: highlights(sensor, reference), dro: false, grey: true };
+ [None, Some(EDGE_CONTRAST)].into_iter().find_map(|edge_limit| {
+ let pairs: Pairs = sensor
+ .data
+ .iter()
+ .zip(&reference.data)
+ .enumerate()
+ .filter(|(i, (input, output))| {
+ // The same signal floors as the camera toe, without colour ratios or counts.
+ !clipped.get(*i).copied().unwrap_or(true)
+ && input.iter().all(|v| *v > 0.0001 && *v < 1.5)
+ && (0.0003..0.85).contains(&luminance_2020(**output))
+ && edge_limit.is_none_or(|limit| local_contrast(sensor, *i) <= limit && local_contrast(reference, *i) <= limit)
+ })
+ .map(|(_, (input, output))| (input.map(f64::from), output.map(f64::from)))
+ .collect();
+ if pairs.len() < 256 {
+ return None;
+ }
+ let look = fit_tone_only_pairs(sensor, reference, &None, edge_limit, &pairs, true, &bright)?;
+ let (tone, neutral) = (ToneMap::camera(&look.tone, 0.0, 0.0, 0.0), ToneMap::new(0.0, 0.0, 0.0));
+ for ((input, target), clipped) in sensor.data.iter().zip(&reference.data).zip(clipped) {
+ if *clipped {
+ let target = luma(target.map(f64::from));
+ let before = luma(displayed(input.map(f64::from), &neutral));
+ let after = luma(displayed(input.map(f64::from), &tone));
+ if !after.is_finite() || (after - target).abs() > (before - target).abs() {
+ return None;
+ }
+ }
+ }
+ Some(look)
+ })
+}
+
+fn fit_tone_only_pairs(
+ sensor: &Rgb32f,
+ reference: &Rgb32f,
+ colour: &Option<(Mat3, Option)>,
+ edge_limit: Option,
+ pairs: &Pairs,
+ dark: bool,
+ highlights: &HighlightCheck,
+) -> Option {
+ let kind = if dark { "near-black scene" } else { "black-and-white JPEG" };
+ let related = rank_correlation_ties(pairs);
if related < PARTIAL_MIN_RANK_CORRELATION {
if lightcraft_pipeline::profiling() {
- eprintln!("[profile] camera look from a black-and-white JPEG: luminance rank correlation {related:.3}, not the same picture");
+ eprintln!("[profile] camera look from a {kind}: luminance rank correlation {related:.3}, not the same picture");
}
return None;
}
@@ -1471,8 +1614,19 @@ fn fit_tone_only_on(sensor: &Rgb32f, reference: &Rgb32f, colour: &Option<(Mat3,
let p = matrix.apply(x);
correction.as_ref().map_or(p, |c| c.apply(p.map(|v| v as f32)).map(f64::from))
};
- let tone = fit_tone_with_shadows(ToneFit::Quantile, &pairs, sensor, reference, edge_limit, coloured)?;
+ let tone = if dark {
+ // Split this wider set once. The camera toe's separate colour/extra split belongs to
+ // the original colour pairs and would put some of these held-out pixels into training.
+ fit_tone(
+ pairs.iter().enumerate().filter(|(i, _)| i % 3 != 0).map(|(_, (x, y))| (luma(coloured(*x).map(|v| v.max(0.0))), luma(*y))).collect(),
+ )?
+ } else {
+ fit_tone_with_shadows(ToneFit::Quantile, pairs, sensor, reference, edge_limit, coloured)?
+ };
let look = CameraLook { matrix, tone, hue_sat: hue_sat.clone() };
+ if !highlights_hold(&look.tone, highlights, coloured) {
+ return None;
+ }
let (tone, neutral) = (ToneMap::camera(&look.tone, 0.0, 0.0, 0.0), ToneMap::new(0.0, 0.0, 0.0));
let encoded = |v: f64| v.max(0.0).powf(1.0 / 2.2);
let (mut before, mut after, mut before_encoded, mut after_encoded, mut samples) = (0.0, 0.0, 0.0, 0.0, 0);
@@ -1486,7 +1640,7 @@ fn fit_tone_only_on(sensor: &Rgb32f, reference: &Rgb32f, colour: &Option<(Mat3,
}
if lightcraft_pipeline::profiling() {
eprintln!(
- "[profile] camera look from a black-and-white JPEG: holdout luminance RMS {:.5} -> {:.5} ({samples} pixels{})",
+ "[profile] camera look from a {kind}: holdout luminance RMS {:.5} -> {:.5} ({samples} pixels{})",
(before / samples.max(1) as f64).sqrt(),
(after / samples.max(1) as f64).sqrt(),
if edge_limit.is_some() { ", away from edges" } else { "" }
@@ -1780,6 +1934,89 @@ impl ToneFit {
}
}
+/// The bright areas a narrow tone curve is checked against ([`highlights_hold`]): every proxy pixel
+/// whose camera JPEG luminance is 0.85 or more, with its sensor value as developed (for a clipped
+/// pixel a lower bound of the scene). Taken from the proxies before any training filter (clipped
+/// pixels, edges, the sensor value range of [`collect_pairs`]), so no retry of the search can
+/// leave them out.
+fn highlights(sensor: &Rgb32f, reference: &Rgb32f) -> Pairs {
+ if sensor.data.len() != reference.data.len() {
+ return Vec::new();
+ }
+ sensor
+ .data
+ .iter()
+ .zip(&reference.data)
+ .filter(|(x, y)| x.iter().chain(y.iter()).all(|v| v.is_finite() && *v >= 0.0) && luminance_2020(**y) >= 0.85)
+ .map(|(x, y)| (x.map(f64::from), y.map(f64::from)))
+ .collect()
+}
+
+/// Smallest ratio between the scene luminance of the brightest and of the darkest 1/32 of the
+/// pairs a tone curve is fitted to (its last and first knot). Below it the training pairs are
+/// nearly uniform (under 0.26 EV from their darker to their brighter parts): the curve would be
+/// fitted to a sliver of the tone range and the rest of it extrapolated. Above it the acceptance
+/// gates judge the curve. This was 1.5, which rejected low-contrast scenes the curve fits very
+/// well: in a hazy ILCE-7RM4 burst the frames at 1.46–1.49 opened with the neutral fallback (no full or partial
+/// look, 18 L* darker than the camera JPEG) while the frame at 1.51 fitted at a held-out RMS of
+/// 0.013, as the others do once allowed (issue #631). Across 135 public Sony files the lowest is 4.0.
+/// A curve under [`NARROW_TONE_RANGE`] must also pass [`highlights_hold`].
+const MIN_TONE_RANGE: f32 = 1.2;
+
+/// [`MIN_TONE_RANGE`] before issue #631. A curve fitted to a narrower range than this must also
+/// render the photo's bright areas no further from the camera JPEG than the neutral fallback does
+/// ([`highlights_hold`]). Neither the fit nor the held-out gates see those areas (camera JPEG
+/// luminance 0.85 and up, left out of the training pairs by [`collect_pairs`]), and a curve fitted
+/// to a sliver of the tone range extrapolates them: in review, a synthetic frame whose curve passed
+/// the gates at a held-out RMS of 0.0004 rendered its bright sky at 0.29 where the camera JPEG has
+/// 0.93.
+const NARROW_TONE_RANGE: f32 = 1.5;
+
+/// What a narrow tone curve is checked against ([`highlights_hold`]).
+struct HighlightCheck {
+ /// The frame's [`highlights`].
+ pairs: Pairs,
+ /// The photo's curve will be lowered to Sony's without DRO ([`with_dro_off_tone`]) after the
+ /// fit, so the check looks at it lowered.
+ dro: bool,
+ /// The camera JPEG is black and white ([`fit_tone_only_with`]): the check compares luminance, as that
+ /// fit's gates do, since the JPEG has no colour to match.
+ grey: bool,
+}
+
+/// Whether a look with this `tone` and `colour` (sensor value to the finish stage's input) keeps
+/// the frame's [`highlights`] (camera JPEG luminance 0.85 and up, left out of the fit) no further
+/// from the camera JPEG than the neutral fallback does, with the tone curve as the photo will get
+/// it (lowered for DRO), in luminance alone for a black-and-white JPEG. Only asked of curves narrower than
+/// [`NARROW_TONE_RANGE`]: true for wider ones, and for frames without such pixels.
+fn highlights_hold(tone: &CameraTone, check: &HighlightCheck, colour: impl Fn([f64; 3]) -> [f64; 3]) -> bool {
+ let knots = tone.knots();
+ if knots[31][0] >= knots[0][0] * NARROW_TONE_RANGE {
+ return true;
+ }
+ // the curve as the photo will get it
+ let used = if check.dro { dro_off(tone) } else { *tone };
+ let (map, neutral) = (ToneMap::camera(&used, 0.0, 0.0, 0.0), ToneMap::new(0.0, 0.0, 0.0));
+ let (mut look, mut fallback) = (0.0, 0.0);
+ for (x, target) in &check.pairs {
+ let (rendered, base) = (displayed(colour(*x), &map), displayed(*x, &neutral));
+ if check.grey {
+ look += (luma(rendered) - luma(*target)).powi(2);
+ fallback += (luma(base) - luma(*target)).powi(2);
+ continue;
+ }
+ for c in 0..3 {
+ look += (rendered[c] - target[c]).powi(2);
+ fallback += (base[c] - target[c]).powi(2);
+ }
+ }
+ let hold = look.is_finite() && look <= fallback;
+ if !hold && lightcraft_pipeline::profiling() {
+ eprintln!("[profile] camera look: narrow tone curve renders the bright areas worse than the fallback ({look:.3} > {fallback:.3})");
+ }
+ hold
+}
+
/// The camera's tone curve from scene/JPEG luminance pairs, by quantile matching: knot `i` pairs
/// the median of the `i`-th 1/32 of the sorted scene luminances with the median of the `i`-th
/// 1/32 of the sorted JPEG luminances. A tone curve is monotone, so it maps each quantile of the
@@ -1807,7 +2044,7 @@ fn fit_tone(pairs: Vec<(f64, f64)>) -> Option {
let mid = a + (b - a) / 2;
*knot = [*xs.get(mid)? as f32, *ys.get(mid)? as f32];
}
- if knots[31][0] < knots[0][0] * 1.5 {
+ if knots[31][0] < knots[0][0] * MIN_TONE_RANGE {
return None;
}
CameraTone::new(knots)
@@ -1835,7 +2072,7 @@ fn fit_tone_conditional(mut pairs: Vec<(f64, f64)>) -> Option {
let mut ys: Vec<_> = bin.iter().map(|p| p.1).collect();
*knot = [median(&mut xs)? as f32, median(&mut ys)? as f32];
}
- if knots[31][0] < knots[0][0] * 1.5 {
+ if knots[31][0] < knots[0][0] * MIN_TONE_RANGE {
return None;
}
// Pool adjacent violating bins (isotonic regression): no reversals or arbitrary polynomial.
@@ -2558,6 +2795,7 @@ mod tests {
&mut raw,
|_, _| panic!("no JPEG fit for a raw with its own matrices"),
|_, _| panic!("no black-and-white JPEG fit for a raw with its own matrices"),
+ |_, _| panic!("no dark tone fit for a raw with its own matrices"),
);
assert_eq!(raw.color, color);
assert!(!t.matrix_is_fallback && look.is_none());
@@ -2579,6 +2817,7 @@ mod tests {
(Some(fitted.clone()), false)
},
|_, _| panic!("no black-and-white JPEG fit after an accepted fit"),
+ |_, _| panic!("no dark tone fit after an accepted fit"),
);
assert_eq!(look.map(|l| l.matrix), Some(fitted.matrix), "{model}");
assert_eq!(raw.color, lightcraft_raw::ColorData::default(), "{model}: spectral matrices left out");
@@ -2601,7 +2840,8 @@ mod tests {
let camera = lightcraft_raw::spectral::find(Some("Canon"), "Canon EOS 600D").unwrap();
let mut raw = raw_of(RawFormat::Cr2, "Canon", "Canon EOS 600D", Default::default());
- let (xy, t, look) = starting_colour_with(&mut raw, |_, _| (None, false), |_, _| panic!("a colour JPEG never takes the black-and-white step"));
+ let (xy, t, look) =
+ starting_colour_with(&mut raw, |_, _| (None, false), |_, _| panic!("a colour JPEG never takes the black-and-white step"), |_, _| None);
assert!(look.is_none());
assert_eq!(raw.color.illuminant, [17, 21]);
assert_eq!(raw.color.forward_matrix, camera.forward_matrix.map(Some));
@@ -2631,6 +2871,7 @@ mod tests {
assert!(!t.matrix_is_fallback && raw.color.forward_matrix == camera.forward_matrix.map(Some), "the spectral matrices are in");
Some(toned.clone())
},
+ |_, _| panic!("an accepted monochrome look keeps its tone"),
);
assert!(look.as_ref().is_some_and(|l| l.matrix == Mat3::IDENTITY && l.hue_sat.is_none()), "the tone curve on top");
assert!(!t.matrix_is_fallback);
@@ -2644,6 +2885,7 @@ mod tests {
assert!(t.matrix_is_fallback, "outside the table: the neutral fallback's colour");
Some(toned.clone())
},
+ |_, _| panic!("an accepted monochrome look keeps its tone"),
);
assert!(look.is_some() && t.matrix_is_fallback);
assert_eq!(raw.color, lightcraft_raw::ColorData::default());
@@ -2734,6 +2976,7 @@ mod tests {
RawFormat::Pef,
RawFormat::Srw,
RawFormat::Orf,
+ RawFormat::Mrw,
RawFormat::Erf,
];
assert!(local.into_iter().all(file_local_look));
@@ -3504,7 +3747,8 @@ mod tests {
let none = fit_look(&sensor, &reference, &vec![false; sensor.data.len()], None).unwrap();
assert_eq!((none.matrix.0, none.tone), (all.matrix.0, all.tone));
// without clipped pixels the refit keeps the accepted attempt (here: all pixels, own colour, quantile tone)
- let (_, attempt) = search_ordered(&sensor, &reference, None, TONE_FITS).unwrap();
+ let check = HighlightCheck { pairs: highlights(&sensor, &reference), dro: false, grey: false };
+ let (_, attempt) = search_ordered(&sensor, &reference, None, TONE_FITS, &check).unwrap();
assert_eq!(attempt, Attempt { tone: ToneFit::Quantile, profile: false, away_from_edges: false, dark: false });
assert!(without_clipped(&sensor, &[true; 3]).is_none(), "a mask of another size is ignored");
}
@@ -3591,6 +3835,110 @@ mod tests {
assert!(tone.apply(0.05) < tone.apply(0.2) && tone.apply(0.2) < tone.apply(0.8));
}
+ fn near_black_scene() -> (Rgb32f, Rgb32f) {
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ for (i, (input, output)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ let y = if i % 60 == 0 { 0.3 + (i % 7) as f32 * 0.01 } else { 0.006 + ((i * 7919) % 6144) as f32 / 6144.0 * 0.075 };
+ let rgb = [1.15, 1.0, 0.75];
+ *input = rgb.map(|v| v * y / luminance_2020(rgb));
+ *output = input.map(|v| v * 0.08);
+ }
+ (sensor, reference)
+ }
+
+ #[test]
+ fn a_near_black_scene_gets_tone_without_learning_colour() {
+ let (sensor, reference) = near_black_scene();
+ assert!(collect_pairs(&sensor, &reference, 0.005, None, false).is_none(), "too few midtones even for the partial look");
+ let mut raw = raw_of(RawFormat::Nef, "NIKON CORPORATION", "NIKON D610", Default::default());
+ let (_, _, look) = starting_colour_with(
+ &mut raw,
+ |_, _| (fit_look(&sensor, &reference, &vec![false; sensor.data.len()], None), false),
+ |_, _| None,
+ |_, _| fit_dark_tone(&sensor, &reference, &vec![false; sensor.data.len()]),
+ );
+ let look = look.expect("tone from the dark pixels");
+ assert_eq!(look.matrix, Mat3::IDENTITY);
+ assert!(look.hue_sat.is_none());
+ let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ let error = |tone: &ToneMap| {
+ sensor
+ .data
+ .iter()
+ .zip(&reference.data)
+ .map(|(x, y)| (luma(displayed(x.map(f64::from), tone)) - luma(y.map(f64::from))).powi(2))
+ .sum::()
+ };
+ assert!(error(&tone) < error(&ToneMap::new(0.0, 0.0, 0.0)) * 0.001);
+ assert_eq!(look.tone.apply(0.0), 0.0);
+ let mut previous = 0.0;
+ for i in 0..10_000 {
+ let y = look.tone.apply(i as f32 / 10_000.0);
+ assert!(y.is_finite() && y >= previous && y <= 1.0);
+ previous = y;
+ }
+ // Models with spectral matrices keep them before the dark tone is fitted.
+ let mut raw = raw_of(RawFormat::Cr2, "Canon", "Canon EOS 600D", Default::default());
+ let (_, t, look) = starting_colour_with(
+ &mut raw,
+ |_, _| (None, false),
+ |_, _| None,
+ |raw, t| {
+ assert!(!t.matrix_is_fallback && lightcraft_raw::color::has_matrix(&raw.color));
+ fit_dark_tone(&sensor, &reference, &vec![false; sensor.data.len()])
+ },
+ );
+ assert!(!t.matrix_is_fallback);
+ assert_eq!(look.expect("tone on top of spectral colour").matrix, Mat3::IDENTITY);
+ }
+
+ #[test]
+ fn dark_tone_holdout_never_enters_training() {
+ let (sensor, mut reference) = near_black_scene();
+ let none = vec![false; sensor.data.len()];
+ let original = fit_dark_tone(&sensor, &reference, &none).expect("dark tone");
+ // Every pixel clears the wider signal floors. Changing only its held-out third must
+ // change the measured error, but cannot change the fitted curve.
+ for p in reference.data.iter_mut().step_by(3) {
+ *p = p.map(|v| v * 1.03);
+ }
+ let changed = fit_dark_tone(&sensor, &reference, &none).expect("still clearly better than the fallback");
+ assert_eq!(changed.tone, original.tone);
+ }
+
+ #[test]
+ fn dark_tone_requires_signal_correlation_and_unclipped_highlights() {
+ let (sensor, reference) = near_black_scene();
+ let none = vec![false; sensor.data.len()];
+ let mut unrelated = reference.clone();
+ for (i, p) in unrelated.data.iter_mut().enumerate() {
+ *p = reference.data[(i * 3571) % reference.data.len()];
+ }
+ assert!(fit_dark_tone(&sensor, &unrelated, &none).is_none(), "unrelated dark JPEG");
+ let mut flat = reference.clone();
+ flat.data.fill([0.002; 3]);
+ assert!(fit_dark_tone(&sensor, &flat, &none).is_none(), "a quantized flat JPEG cannot teach tone");
+ let mut sparse = reference.clone();
+ sparse.data.iter_mut().skip(80).for_each(|p| *p = [0.0; 3]);
+ assert!(fit_dark_tone(&sensor, &sparse, &none).is_none(), "fewer than 256 usable pairs");
+ let mut bright = reference.clone();
+ bright.data[0] = [0.95; 3];
+ assert!(fit_dark_tone(&sensor, &bright, &none).is_none(), "dark pairs cannot constrain a bright highlight");
+ let mut clipped = none;
+ clipped[0] = true;
+ let original = fit_dark_tone(&sensor, &reference, &clipped).expect("tone without the clipped pixel");
+ let mut changed = sensor.clone();
+ changed.data[0] = [0.18; 3];
+ let look = fit_dark_tone(&changed, &reference, &clipped).expect("the clipped pixel is still closer to its JPEG");
+ assert_eq!(look.tone, original.tone, "clipped samples cannot change the fitted curve");
+ let mut highlight = reference.clone();
+ highlight.data[0] = [0.8; 3];
+ assert!(fit_dark_tone(&changed, &highlight, &clipped).is_none(), "the curve cannot darken a clipped highlight away from the JPEG");
+ assert!(fit_dark_tone(&sensor, &Rgb32f::new(64, 96), &clipped).is_none(), "mismatched dimensions");
+ assert!(fit_dark_tone(&sensor, &reference, &[]).is_none(), "mismatched clip mask");
+ }
+
/// An overcast, nearly colourless scene (under 5% of the pixels coloured, so no colour matrix is
/// learnt and the full look is never tried) whose camera renders it two stops brighter than the
/// neutral fallback: the partial look is the tone curve (and chroma curve) alone.
@@ -3636,7 +3984,8 @@ mod tests {
let neutral = ToneMap::new(0.0, 0.0, 0.0);
let mut reference = sensor.clone();
reference.map_in_place(|p| displayed(p.map(f64::from), &neutral).map(|v| v as f32));
- assert!(fit_partial(&sensor, &reference).is_none(), "no clear gain over the fallback");
+ let check = HighlightCheck { pairs: highlights(&sensor, &reference), dro: false, grey: false };
+ assert!(fit_partial(&sensor, &reference, &check).is_none(), "no clear gain over the fallback");
// an unrelated picture
for (i, p) in reference.data.iter_mut().enumerate() {
*p = [0.05 + (i % 7) as f32 * 0.07, 0.05 + (i % 19) as f32 * 0.02, 0.05 + (i % 29) as f32 * 0.01];
@@ -3740,6 +4089,7 @@ mod tests {
assert!(!t.matrix_is_fallback, "on the spectral matrices");
own.clone()
},
+ |_, _| None,
);
assert!(look.is_some() && !t.matrix_is_fallback);
}
@@ -3895,8 +4245,10 @@ mod tests {
}
}
let colour = Some((Mat3::IDENTITY, None));
- let look = fit_attempt(&sensor, &reference, &colour, Attempt { tone: ToneFit::Quantile, profile: true, away_from_edges: false, dark: true })
- .expect("tone fitted");
+ let check = HighlightCheck { pairs: highlights(&sensor, &reference), dro: false, grey: false };
+ let look =
+ fit_attempt(&sensor, &reference, &colour, Attempt { tone: ToneFit::Quantile, profile: true, away_from_edges: false, dark: true }, &check)
+ .expect("tone fitted");
assert_eq!(look.matrix, Mat3::IDENTITY);
assert!(look.hue_sat.is_none());
let (fitted, default) = (ToneMap::camera(&look.tone, 0.0, 0.0, 0.0), ToneMap::new(0.0, 0.0, 0.0));
@@ -3959,6 +4311,27 @@ mod tests {
assert!(plain.data.iter().all(|p| *p == [0.2; 3]));
}
+ /// Lens opcodes prevent mosaic binning. The DNG fit still gets a proxy, with the file's
+ /// full-resolution corrections applied once rather than silently losing the tone fit.
+ #[test]
+ fn dng_sensor_proxy_applies_lens_opcodes_before_downsampling() {
+ use lightcraft_raw::Opcode;
+ let bytes = crate::tests_xmp::synthetic_dng_with(None, Default::default());
+ let mut raw = lightcraft_raw::decode(&bytes).unwrap();
+ raw.data = lightcraft_raw::RawData::U16(vec![4000; raw.width * raw.height]);
+ raw.opcodes.list3 = vec![Opcode::FixVignetteRadial { k: [1.0, 0.0, 0.0, 0.0, 0.0], center: [0.5, 0.5] }];
+ assert!(raw.develop_binned(2, SENSOR_CLIP).unwrap().is_none());
+ let proxy = sensor_proxy(&raw, 2, 32).expect("a corrected CFA proxy even when binning is unavailable");
+ assert_eq!((proxy.width, proxy.height), (32, 24));
+ let center = proxy.data[12 * 32 + 16][1];
+ let corner = proxy.data[0][1];
+ assert!((1.8..2.1).contains(&(corner / center)), "one vignetting gain, not zero or two: {corner} / {center}");
+ let full = raw.develop(lightcraft_raw::Method::Bilinear).unwrap();
+ assert_eq!(proxy.data, full.data, "the same opcode interpretation as raw development");
+ let small = sensor_proxy(&raw, 2, 16).unwrap();
+ assert_eq!(small.data, fit(&full, 16, 16, Filter::Box).data, "correct first, then reduce");
+ }
+
/// Which DNGs get a tone fitted to their camera JPEG: a colour matrix, a tone curve that is absent or the
/// identity, with or without a look table; and no other raw format.
#[test]
@@ -3993,4 +4366,181 @@ mod tests {
assert!(256.0 < floor(7008.0));
assert!(1024.0 >= floor(9504.0), "a 61 MP raw too");
}
+
+ /// Pairs whose scene luminance spans `ratio` from the darkest to the brightest pixel, mapped
+ /// to the JPEG through a steep camera curve (a hazy scene the camera stretches).
+ fn low_contrast_pairs(ratio: f64) -> Vec<(f64, f64)> {
+ (0..4096).map(|i| 0.08 * ratio.powf(i as f64 / 4095.0)).map(|x| (x, (0.2 + (x - 0.08) * 3.0).min(0.95))).collect()
+ }
+
+ /// The ratio the tone fits test: scene luminance at the middle of the brightest 1/32 over that
+ /// of the darkest 1/32 (their last and first knots).
+ fn knot_range(mut scene: Vec) -> f64 {
+ scene.sort_by(f64::total_cmp);
+ let n = scene.len();
+ scene[31 * n / 32 + n / 64] / scene[n / 64]
+ }
+
+ /// Issue #631: a low-contrast scene (its darker and brighter parts under 1.5× apart) still gets
+ /// a tone curve; only a nearly uniform one doesn't. Both tone fits use the same limit.
+ #[test]
+ fn tone_fits_accept_low_contrast_scenes() {
+ for fit in [fit_tone, fit_tone_conditional] {
+ let pairs = low_contrast_pairs(1.47);
+ let range = knot_range(pairs.iter().map(|p| p.0).collect());
+ assert!((1.4..1.5).contains(&range), "the scene sits just below the old limit of 1.5: {range}");
+ let curve = fit(pairs).expect("a low-contrast scene, as in the burst of issue #631");
+ assert!((curve.apply(0.1) - 0.26).abs() < 0.01, "follows the camera curve: {}", curve.apply(0.1));
+ assert!(fit(low_contrast_pairs(1.1)).is_none(), "a nearly uniform frame");
+ }
+ }
+
+ /// The same scene end to end: colour varies, luminance spans under 1.5×, and the camera
+ /// stretches it; the look is accepted and lands on the JPEG instead of the neutral fallback.
+ #[test]
+ fn a_low_contrast_scene_gets_a_camera_look() {
+ let known = Mat3([[1.8, -0.4, -0.1], [-0.2, 1.5, -0.1], [-0.05, -0.3, 1.7]]);
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ for (i, (src, dst)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ let ev = 0.06 + (i % 31) as f32 * 0.0008;
+ *src = [ev * (0.8 + (i % 11) as f32 * 0.025), ev, ev * (0.8 + (i % 17) as f32 * 0.014)];
+ let p = known.apply_f32(*src);
+ let y = luminance_2020(p);
+ *dst = p.map(|v| v * (0.2 + (y - 0.07) * 3.0) / y);
+ }
+ let look = fit_pairs(&sensor, &reference).expect("a camera look, not the neutral fallback");
+ let range = knot_range(sensor.data.iter().map(|x| luma(look.matrix.apply(x.map(f64::from)))).collect());
+ assert!(range < 1.5, "the scene sits below the old limit of 1.5: {range}");
+ let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ let error: f64 = sensor
+ .data
+ .iter()
+ .zip(&reference.data)
+ .map(|(x, y)| {
+ let p = displayed(look.matrix.apply(x.map(f64::from)), &tone);
+ (0..3).map(|c| (p[c] - f64::from(y[c])).powi(2)).sum::() / 3.0
+ })
+ .sum::()
+ / sensor.data.len() as f64;
+ assert!(error.sqrt() < 0.02, "{}", error.sqrt());
+ }
+
+ /// Codex review of #631: a low-contrast scene's curve is fitted to its midtones only, and the
+ /// camera JPEG's bright areas (luminance 0.85 and up) are in neither the fit nor the held-out
+ /// gates. With 1.2 alone, this frame's curve passed the gates and rendered its bright sky
+ /// (camera JPEG 0.93) at about 0.28. The second review found the same through the retries'
+ /// filters: a clipped sky (left out by the refit without clipped pixels), scattered bright
+ /// pixels (left out away from edges) and sensor values over 1.5 (out of the pairs' range).
+ #[test]
+ fn a_narrow_curve_that_darkens_the_bright_areas_is_refused() {
+ let known = Mat3([[1.8, -0.4, -0.1], [-0.2, 1.5, -0.1], [-0.05, -0.3, 1.7]]);
+ for (case, sky_value, is_sky) in [
+ ("bright sky", 0.9, &(|i: usize| i < 5600) as &dyn Fn(usize) -> bool),
+ ("clipped sky", 1.0, &|i: usize| i < 5600),
+ ("scattered bright pixels", 0.9, &|i: usize| i.is_multiple_of(8)),
+ ("sky over the pairs' range", 1.6, &|i: usize| i < 5600),
+ ] {
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ let mut clipped = vec![false; sensor.data.len()];
+ for (i, (src, dst)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ if is_sky(i) {
+ // bright, nearly white in the camera JPEG
+ *src = [sky_value; 3];
+ *dst = [0.93; 3];
+ clipped[i] = case == "clipped sky";
+ continue;
+ }
+ let ev = 0.06 + (i % 31) as f32 * 0.0008;
+ *src = [ev * (0.8 + (i % 11) as f32 * 0.025), ev, ev * (0.8 + (i % 17) as f32 * 0.014)];
+ let p = known.apply_f32(*src);
+ let y = luminance_2020(p);
+ // nearly flat midtones: the fitted curve's extrapolation can't reach the sky
+ *dst = p.map(|v| v * (0.2 + (y - 0.07) * 0.05) / y);
+ }
+ let Some(look) = fit_look(&sensor, &reference, &clipped, None) else { continue };
+ let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ let correction = look.hue_sat.as_ref().and_then(HueSat::new);
+ let p = look.matrix.apply([f64::from(sky_value); 3]);
+ let p = correction.as_ref().map_or(p, |c| c.apply(p.map(|v| v as f32)).map(f64::from));
+ let sky = luma(displayed(p, &tone));
+ assert!(sky > 0.8, "{case}: an accepted look must not darken what the camera renders at 0.93: {sky}");
+ }
+ }
+
+ /// Third Codex review of #631: for a Sony photo shot with DRO, the fitted curve is lowered to
+ /// Sony's without DRO after the fit, so it must be checked as lowered. On this frame the
+ /// fitted curve keeps the sky (0.81 against the fallback's 0.79), and lowered it rendered the
+ /// sky at 0.61 where the camera JPEG has 0.93.
+ #[test]
+ fn a_narrow_curve_is_checked_as_lowered_for_dro() {
+ let known = Mat3([[1.8, -0.4, -0.1], [-0.2, 1.5, -0.1], [-0.05, -0.3, 1.7]]);
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ for (i, (src, dst)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ if i < 5600 {
+ *src = [0.9; 3];
+ *dst = [0.93; 3];
+ continue;
+ }
+ let ev = 0.06 + (i % 31) as f32 * 0.0008;
+ *src = [ev * (0.8 + (i % 11) as f32 * 0.025), ev, ev * (0.8 + (i % 17) as f32 * 0.014)];
+ let p = known.apply_f32(*src);
+ let y = luminance_2020(p);
+ *dst = p.map(|v| v * (0.6 + (y - 0.07) * 0.25) / y);
+ }
+ let neutral = luma(displayed([0.9; 3], &ToneMap::new(0.0, 0.0, 0.0)));
+ if let Some(look) = fit_look_with(&sensor, &reference, &vec![false; sensor.data.len()], None, true) {
+ let look = with_dro_off_tone(look);
+ let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ let correction = look.hue_sat.as_ref().and_then(HueSat::new);
+ let p = look.matrix.apply([0.9; 3]);
+ let p = correction.as_ref().map_or(p, |c| c.apply(p.map(|v| v as f32)).map(f64::from));
+ let sky = luma(displayed(p, &tone));
+ assert!(sky > neutral - 0.02, "the DRO-lowered curve must not darken the sky past the fallback ({neutral}): {sky}");
+ }
+ }
+
+ /// A black-and-white JPEG of a low-contrast scene (issues #577 and #631): grey pixels, scene luminance spanning
+ /// under 1.5×, which the old range limit refused before any gate. Its tone curve is fitted.
+ #[test]
+ fn a_low_contrast_black_and_white_jpeg_gives_its_tone_curve() {
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ for (i, (src, dst)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ let ev = 0.06 + (i % 31) as f32 * 0.0008;
+ *src = [ev * (0.8 + (i % 11) as f32 * 0.025), ev, ev * (0.8 + (i % 17) as f32 * 0.014)];
+ *dst = [0.2 + (luminance_2020(*src) - 0.06) * 3.0; 3];
+ }
+ let range = knot_range(sensor.data.iter().map(|x| luma(x.map(f64::from))).collect());
+ assert!(range < 1.5, "the scene sits below the old limit of 1.5: {range}");
+ let look = fit_tone_only(&sensor, &reference, None).expect("the JPEG's tone curve");
+ let tone = ToneMap::camera(&look.tone, 0.0, 0.0, 0.0);
+ let error = sensor.data.iter().zip(&reference.data).map(|(x, y)| (luma(displayed(x.map(f64::from), &tone)) - f64::from(y[0])).powi(2));
+ let rms = (error.sum::() / sensor.data.len() as f64).sqrt();
+ assert!(rms < 0.02, "{rms}");
+ }
+
+ /// [`a_narrow_curve_that_darkens_the_bright_areas_is_refused`] for a black-and-white JPEG: its tone curve is
+ /// fitted to nearly flat midtones under 1.5×, and the bright sky (camera JPEG 0.93) is left out of the fit.
+ #[test]
+ fn a_narrow_black_and_white_curve_that_darkens_the_bright_areas_is_refused() {
+ let mut sensor = Rgb32f::new(96, 64);
+ let mut reference = sensor.clone();
+ for (i, (src, dst)) in sensor.data.iter_mut().zip(&mut reference.data).enumerate() {
+ if i < 5600 {
+ *src = [0.9; 3];
+ *dst = [0.93; 3];
+ continue;
+ }
+ let ev = 0.06 + (i % 31) as f32 * 0.0008;
+ *src = [ev * (0.8 + (i % 11) as f32 * 0.025), ev, ev * (0.8 + (i % 17) as f32 * 0.014)];
+ *dst = [0.2 + (luminance_2020(*src) - 0.06) * 0.05; 3];
+ }
+ if let Some(look) = fit_tone_only(&sensor, &reference, None) {
+ let sky = luma(displayed(look.matrix.apply([0.9; 3]), &ToneMap::camera(&look.tone, 0.0, 0.0, 0.0)));
+ assert!(sky > 0.8, "an accepted curve must not darken what the camera renders at 0.93: {sky}");
+ }
+ }
}
diff --git a/crates/engine/src/camera_profiles.rs b/crates/engine/src/camera_profiles.rs
index d13023b6e..c7b6c437b 100644
--- a/crates/engine/src/camera_profiles.rs
+++ b/crates/engine/src/camera_profiles.rs
@@ -159,29 +159,31 @@ pub fn get(model: &str) -> Option> {
/// keys, so thumbnails rendered before a profile existed are not reused after.
pub fn cache_key() -> u64 {
static KEY: OnceLock = OnceLock::new();
- *KEY.get_or_init(|| {
- let entries = dir().and_then(|d| std::fs::read_dir(d).ok());
- let mut files: Vec<(String, u64, u64)> = entries
- .into_iter()
- .flatten()
- .flatten()
- .filter(|e| e.path().extension().is_some_and(|x| x == "json"))
- .filter_map(|e| {
- let meta = e.metadata().ok()?;
- let modified = meta.modified().ok()?.duration_since(std::time::UNIX_EPOCH).ok()?.as_secs();
- Some((e.file_name().to_string_lossy().into_owned(), meta.len(), modified))
- })
- .collect();
- files.sort();
- let mut h = lightcraft_preview::Hasher128::new();
- for (name, len, modified) in &files {
- h.str(name).u64(*len).u64(*modified);
- }
- for (model, json) in BUNDLED {
- h.str(model).str(json);
- }
- h.finish().0 as u64
- })
+ *KEY.get_or_init(|| cache_key_for(dir().as_deref()))
+}
+
+fn cache_key_for(directory: Option<&Path>) -> u64 {
+ let entries = directory.and_then(|d| std::fs::read_dir(d).ok());
+ let mut files: Vec<(String, u64, std::time::Duration)> = entries
+ .into_iter()
+ .flatten()
+ .flatten()
+ .filter(|e| e.path().extension().is_some_and(|x| x == "json"))
+ .filter_map(|e| {
+ let meta = e.metadata().ok()?;
+ let modified = meta.modified().ok()?.duration_since(std::time::UNIX_EPOCH).ok()?;
+ Some((e.file_name().to_string_lossy().into_owned(), meta.len(), modified))
+ })
+ .collect();
+ files.sort();
+ let mut h = lightcraft_preview::Hasher128::new();
+ for (name, len, modified) in &files {
+ h.str(name).u64(*len).u64(modified.as_secs()).u64(u64::from(modified.subsec_nanos()));
+ }
+ for (model, json) in BUNDLED {
+ h.str(model).str(json);
+ }
+ h.finish().0 as u64
}
/// Per camera model: the photos read and their pooled colour pairs.
@@ -294,6 +296,38 @@ mod tests {
assert!(bundled("No Such Camera").is_none());
}
+ #[test]
+ fn same_second_profile_replacement_changes_render_cache_key() {
+ let dir = std::env::temp_dir().join(format!("lc-camera-profile-cache-{}", std::process::id()));
+ let mut first = profile();
+ first.model = "ILCE-7CR".into();
+ let path = save(&first, &dir).unwrap();
+ let set_modified = |millis| {
+ let time = std::time::UNIX_EPOCH + std::time::Duration::from_secs(1_700_000_000) + std::time::Duration::from_millis(millis);
+ let file = std::fs::OpenOptions::new().write(true).open(&path).unwrap();
+ file.set_times(std::fs::FileTimes::new().set_modified(time)).unwrap();
+ file.metadata().unwrap()
+ };
+ let before = set_modified(100);
+ assert_eq!(load(&path).unwrap(), first);
+ let before_key = cache_key_for(Some(&dir));
+
+ let mut second = first;
+ second.matrix[0][0] = 1.7;
+ save(&second, &dir).unwrap();
+ let after = set_modified(350);
+ assert_eq!(load(&path).unwrap(), second);
+ assert_eq!(before.len(), after.len());
+ let before_time = before.modified().unwrap().duration_since(std::time::UNIX_EPOCH).unwrap();
+ let after_time = after.modified().unwrap().duration_since(std::time::UNIX_EPOCH).unwrap();
+ assert_eq!(before_time.as_secs(), after_time.as_secs());
+ assert_ne!(before_time.subsec_nanos(), after_time.subsec_nanos());
+ let after_key = cache_key_for(Some(&dir));
+ let _ = std::fs::remove_dir_all(dir);
+
+ assert_ne!(before_key, after_key, "a changed profile must not reuse the previous render cache");
+ }
+
#[test]
fn file_names_are_safe() {
assert_eq!(file_name("ILCE-7M4"), "ILCE-7M4.json");
diff --git a/crates/engine/src/cmd/browse.rs b/crates/engine/src/cmd/browse.rs
index 655965688..01c67c267 100644
--- a/crates/engine/src/cmd/browse.rs
+++ b/crates/engine/src/cmd/browse.rs
@@ -114,6 +114,16 @@ fn forget_gone(s: &mut Session, dir: &str, subfolders: bool, files: &[String]) -
forgotten
}
+impl Session {
+ /// Record that the folder `root` was browsed now, with the folders of `files` (the photos it showed): what
+ /// `library.browse` does after reading a folder, for a UI that reads it on a worker thread instead. Untouched
+ /// Local photos are forgotten only from folders not browsed for the set number of days, so a browse that
+ /// isn't recorded lets a folder in daily use be forgotten.
+ pub fn note_browsed(&mut self, root: &str, files: &[String]) {
+ stamp_browsed(self, root, files);
+ }
+}
+
/// Folders whose browse time is refreshed at most this often (keeps repeated browsing from
/// growing the log; far finer than the days the eviction counts in).
const RESTAMP_SECS: i64 = 3600;
@@ -148,7 +158,11 @@ fn stamp_browsed(s: &mut Session, root: &str, files: &[String]) {
/// referred to by an undo / redo step.
fn in_use(s: &mut Session) -> std::collections::HashSet {
let mut keep = held(s);
- keep.extend(s.visible().iter().copied());
+ // Missing Photos lists library photos only, never Local records, so it keeps nothing here; and
+ // working it out checks every original (minutes on a sleeping NAS when the library opens on it)
+ if s.source != crate::LibrarySource::Missing {
+ keep.extend(s.visible().iter().copied());
+ }
keep
}
diff --git a/crates/engine/src/cmd/cull.rs b/crates/engine/src/cmd/cull.rs
index 030cb6e93..142accd5a 100644
--- a/crates/engine/src/cmd/cull.rs
+++ b/crates/engine/src/cmd/cull.rs
@@ -21,6 +21,9 @@ fn secs(iso: &str) -> Option {
fn analyze(s: &mut Session, p: &Value) -> Result {
let ids: Vec = if p.get("ids").is_some() || s.selection.ids.len() > 1 { s.targets(p)? } else { s.visible_cloned() };
+ // a photo listed twice is one photo, not a burst of two look-alikes (first occurrence kept)
+ let mut seen = std::collections::HashSet::new();
+ let ids: Vec = ids.into_iter().filter(|id| seen.insert(*id)).collect();
let reject_below = p.get("rejectBelow").and_then(Value::as_f64).map(|v| v as f32);
let pick_best = p.get("pickBest").and_then(Value::as_bool).unwrap_or(false);
// measure (thumbnail-level sources: fast, and enough for focus at 512 px)
@@ -87,7 +90,7 @@ fn analyze(s: &mut Session, p: &Value) -> Result {
/// content), most similar first; the view is filtered to them.
fn find_similar(s: &mut Session, p: &Value) -> Result {
const C: &str = "library.findSimilar";
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| super::bad(C, "no photo"))?;
+ let id = super::photo_id(p, C)?.or(s.active()).ok_or_else(|| super::bad(C, "no photo"))?;
let min = p.get("similarity").and_then(Value::as_f64).unwrap_or(0.8) as f32;
let all: Vec = s.catalog.photos().filter(|q| q.in_library()).map(|q| q.id).collect();
let sig = |s: &mut Session, id: PhotoId| -> Option<[f32; 64]> {
diff --git a/crates/engine/src/cmd/denoise.rs b/crates/engine/src/cmd/denoise.rs
index f93a2434a..644d3b89e 100644
--- a/crates/engine/src/cmd/denoise.rs
+++ b/crates/engine/src/cmd/denoise.rs
@@ -513,10 +513,6 @@ fn settings(s: &mut Session, p: &Value) -> Result {
Ok(json!({"auto": st.auto(), "cacheGb": st.cache_bytes() >> 30, "threads": st.threads, "runOn": st.run_on().name()}))
}
-fn ids_param(p: &Value) -> Option> {
- p.get("ids").and_then(Value::as_array).map(|a| a.iter().filter_map(Value::as_u64).map(PhotoId).collect())
-}
-
fn status_json(s: &Session, photo: Option) -> Value {
let (files, bytes) = s.denoise_cache_usage();
let st = &s.denoise.settings;
@@ -594,7 +590,7 @@ fn queue(s: &mut Session, p: &Value) -> Result {
if s.denoise_products_dir().is_none() {
return Err(bad(C, "denoise keeps its pictures in the library's folder: open a library on disk first"));
}
- let ids = match ids_param(p) {
+ let ids = match super::photo_ids(p, C)? {
Some(ids) => ids,
None => match str_param(p, "scope").unwrap_or("selected") {
"selected" => s.selection.active.iter().chain(s.selection.ids.iter()).copied().collect(),
@@ -612,14 +608,14 @@ fn queue(s: &mut Session, p: &Value) -> Result {
}
fn cancel(s: &mut Session, p: &Value) -> Result {
- let photo = p.get("id").and_then(Value::as_u64).map(PhotoId);
+ let photo = super::photo_id(p, "denoise.cancel")?;
let n = s.denoise_cancel(photo, bool_or(p, "all", photo.is_none()));
Ok(json!({"cancelled": n}))
}
fn status(s: &mut Session, p: &Value) -> Result {
s.denoise_refresh_active(false);
- Ok(status_json(s, p.get("id").and_then(Value::as_u64).map(PhotoId)))
+ Ok(status_json(s, super::photo_id(p, "denoise.status")?))
}
/// `denoise.pump {pace?}`: cheap to call every frame. Takes in what the background job has finished and keeps one going.
diff --git a/crates/engine/src/cmd/develop.rs b/crates/engine/src/cmd/develop.rs
index ce7bf4a65..fbc3d4041 100644
--- a/crates/engine/src/cmd/develop.rs
+++ b/crates/engine/src/cmd/develop.rs
@@ -2,7 +2,7 @@
use lightcraft_catalog::{Op, PhotoId, Version};
use lightcraft_develop::{DevelopSettings, Preset, ProcessVersion, Section, SettingsGroup, Treatment, Upright, WbMode, controls};
-use lightcraft_geom::{CropGeometry, CropHandle, Point, Rect, crop_fit_angle, drag_crop};
+use lightcraft_geom::{CropGeometry, CropHandle, MIN_CROP_FRACTION, Point, Rect, crop_fit_angle, drag_crop};
use serde_json::{Value, json};
use super::{CommandSpec, always, bad, bool_or, cmd, f64_or, f64_req, has_active, has_clipboard, has_selection, index_req, ok, str_param};
@@ -208,8 +208,7 @@ pub fn specs() -> Vec {
}
refit_crop_angle(angle, before, d, dims);
};
- if let Some(ids) = p.get("ids").and_then(Value::as_array) {
- let ids: Vec = ids.iter().filter_map(Value::as_u64).map(PhotoId).collect();
+ if let Some(ids) = super::photo_ids(p, "develop.set")? {
let ops = ids
.iter()
.filter_map(|id| s.develop_of(*id).map(|d| (*id, d)))
@@ -533,13 +532,24 @@ pub fn specs() -> Vec {
cmd!("crop.set", "Set Crop", [], None, "{rect?: [x0,y0,x1,y1] normalized in the straightened frame, angle?: degrees}", has_active, |s, p| {
let id = active(s, "crop.set")?;
let (w, h) = crop_dims(s, id);
+ // the smallest crop a drag of the crop tool can make: below it an export comes out 1×1 (#1952)
+ let min_side = MIN_CROP_FRACTION * w.min(h) * (1.0 - 1e-9);
+ let too_small = |r: Rect| {
+ (r.width() * w < min_side || r.height() * h < min_side)
+ .then(|| bad("crop.set", format!("rect is smaller than the smallest crop ({} % of the shorter side)", MIN_CROP_FRACTION * 100.0)))
+ };
edit(s, "crop.set", "Crop", |d| {
- if let Some(a) = p.get("rect").and_then(Value::as_array) {
+ let explicit = p.get("rect").and_then(Value::as_array);
+ if let Some(a) = explicit {
let v: Vec = a.iter().filter_map(Value::as_f64).collect();
if v.len() != 4 {
return Err(bad("crop.set", "rect needs 4 numbers"));
}
- d.crop.geometry.rect = Rect::new(v[0].min(v[2]), v[1].min(v[3]), v[0].max(v[2]), v[1].max(v[3]));
+ let r = Rect::new(v[0].min(v[2]), v[1].min(v[3]), v[0].max(v[2]), v[1].max(v[3]));
+ if let Some(e) = too_small(r) {
+ return Err(e);
+ }
+ d.crop.geometry.rect = r;
}
let angle = p.get("angle").and_then(Value::as_f64).map(|a| a.clamp(-45.0, 45.0));
d.crop.geometry = match (p.get("rect"), angle) {
@@ -547,6 +557,12 @@ pub fn specs() -> Vec {
(None, Some(a)) => d.crop.geometry.with_angle(a, w, h),
(_, a) => CropGeometry { angle: a.unwrap_or(d.crop.geometry.angle), ..d.crop.geometry }.constrained(w, h),
};
+ // a rect far larger than the photo is shrunk to fit it, and can come out a sliver
+ if explicit.is_some()
+ && let Some(e) = too_small(d.crop.geometry.rect)
+ {
+ return Err(e);
+ }
Ok(())
})
}),
diff --git a/crates/engine/src/cmd/face_recognize.rs b/crates/engine/src/cmd/face_recognize.rs
index 228a1ce3d..e66bb56f3 100644
--- a/crates/engine/src/cmd/face_recognize.rs
+++ b/crates/engine/src/cmd/face_recognize.rs
@@ -82,7 +82,7 @@ fn name_faces(s: &mut Session, p: &Value) -> Result {
/// makes the face yours: a later "Detect Faces" run no longer replaces it.
fn set_name(s: &mut Session, p: &Value) -> Result {
const C: &str = "faces.setName";
- let id = p.get("id").and_then(Value::as_u64).map(lightcraft_catalog::PhotoId).or_else(|| s.active()).ok_or_else(|| bad(C, "no photo"))?;
+ let id = super::photo_id(p, C)?.or_else(|| s.active()).ok_or_else(|| bad(C, "no photo"))?;
let index = p.get("index").and_then(Value::as_u64).and_then(|i| usize::try_from(i).ok()).ok_or_else(|| bad(C, "missing or invalid `index`"))?;
let name = name_param(p, C)?;
let mut meta = s.catalog.photo(id).ok_or_else(|| bad(C, "no such photo"))?.meta.clone();
@@ -470,8 +470,7 @@ mod imp {
let embedder = current(s, C)?;
collect(s);
let budget = Duration::from_millis(p.get("budgetMs").and_then(Value::as_u64).unwrap_or(200).min(600_000));
- let first: Vec =
- p.get("ids").and_then(Value::as_array).map(|a| a.iter().filter_map(Value::as_u64).map(PhotoId).collect()).unwrap_or_default();
+ let first: Vec = super::super::photo_ids(p, C)?.unwrap_or_default();
let todo = pending(s, &first, false);
let started = Instant::now();
let (mut embedded, mut failed, mut done) = (0, 0, 0);
@@ -509,13 +508,12 @@ mod imp {
if !(1..=12).contains(&m) || !(1..=31).contains(&d) {
return None;
}
- // days from civil (proleptic Gregorian)
- let y = if m <= 2 { y - 1 } else { y };
- let era = y.div_euclid(400);
- let yoe = y - era * 400;
- let doy = (153 * (if m > 2 { m - 3 } else { m + 9 }) + 2) / 5 + d - 1;
- let doe = yoe * 365 + yoe / 4 - yoe / 100 + doy;
- Some((era * 146_097 + doe - 719_468) * 86_400 + hh * 3600 + mm * 60 + ss)
+ // Days since 1970-01-01 (proleptic Gregorian); a day past the month's length rolls over as
+ // the old Hinnant arithmetic did.
+ let first = chrono::NaiveDate::from_ymd_opt(i32::try_from(y).ok()?, u32::try_from(m).ok()?, 1)?;
+ let date = first.checked_add_days(chrono::Days::new(u64::try_from(d - 1).ok()?))?;
+ let days = (date - chrono::NaiveDate::from_ymd_opt(1970, 1, 1)?).num_days();
+ Some(days * 86_400 + hh * 3600 + mm * 60 + ss)
}
/// `faces.evaluate`: leave-one-out over the library's named faces, to see how well recognition works on *your*
diff --git a/crates/engine/src/cmd/library.rs b/crates/engine/src/cmd/library.rs
index 5567e0abf..e437dccc2 100644
--- a/crates/engine/src/cmd/library.rs
+++ b/crates/engine/src/cmd/library.rs
@@ -145,10 +145,6 @@ fn strs(p: &Value, key: &str) -> Vec {
p.get(key).and_then(Value::as_array).map(|a| a.iter().filter_map(Value::as_str).map(str::to_string).collect()).unwrap_or_default()
}
-fn ids_param(p: &Value) -> Option> {
- p.get("ids").and_then(Value::as_array).map(|a| a.iter().filter_map(Value::as_u64).map(PhotoId).collect())
-}
-
/// The targets an album can hold and how many were browsed (Local) photos, which album views
/// never show (issue #684): those are skipped, and reported, instead of becoming invisible members.
fn album_targets(s: &Session, targets: Vec) -> (Vec, usize) {
@@ -623,7 +619,7 @@ pub fn specs() -> Vec {
"{ids: [id], active?: id, mode?: replace|add|toggle|range} — every id must be a photo of the library",
always,
|s, p| {
- let ids = ids_param(p).unwrap_or_default();
+ let ids = super::photo_ids(p, "library.select")?.unwrap_or_default();
let active = p.get("active").and_then(Value::as_u64).map(PhotoId);
let mode = str_param(p, "mode").unwrap_or("replace");
// An id that is not in the library is an error, and the selection stays as it was:
@@ -808,9 +804,13 @@ pub fn specs() -> Vec {
"{label: red|yellow|green|blue|purple|none, ids?}",
has_selection,
|s, p| {
- let l = match str_param(p, "label") {
- None | Some("none") => None,
- Some(x) => Some(ColorLabel::parse(x).ok_or_else(|| bad("photo.label", "unknown label"))?),
+ // `none` (or null) clears; a missing label or one that isn't text is an error, not a clear
+ let l = match p.get("label") {
+ Some(Value::Null) => None,
+ Some(Value::String(x)) if x == "none" => None,
+ Some(Value::String(x)) => Some(ColorLabel::parse(x).ok_or_else(|| bad("photo.label", "unknown label"))?),
+ None => return Err(bad("photo.label", "missing `label` (red|yellow|green|blue|purple|none)")),
+ Some(_) => return Err(bad("photo.label", "label must be red|yellow|green|blue|purple|none")),
};
for_targets(s, p, "Set Color Label", |id| Some(Op::SetLabel { id, label: l }))
}
@@ -829,8 +829,7 @@ pub fn specs() -> Vec {
"{id?, index} — remove one face / pet region (by its position in the photo's regions) from the photo in the catalog; undoable. The XMP sidecar is never rewritten for this, even with auto-write on, so reading the metadata from the file brings the region back",
always,
|s, p| {
- let id =
- p.get("id").and_then(Value::as_u64).map(PhotoId).or_else(|| s.active()).ok_or_else(|| bad("photo.removeRegion", "no photo"))?;
+ let id = super::photo_id(p, "photo.removeRegion")?.or_else(|| s.active()).ok_or_else(|| bad("photo.removeRegion", "no photo"))?;
let index = p
.get("index")
.and_then(Value::as_u64)
@@ -856,7 +855,7 @@ pub fn specs() -> Vec {
|s, p| {
const C: &str = "photo.setRegion";
// a drag is one undo step however many frames it took: the caller commits once, on release
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or_else(|| s.active()).ok_or_else(|| bad(C, "no photo"))?;
+ let id = super::photo_id(p, C)?.or_else(|| s.active()).ok_or_else(|| bad(C, "no photo"))?;
let index = p
.get("index")
.and_then(Value::as_u64)
@@ -1267,7 +1266,7 @@ pub fn specs() -> Vec {
has_library_selection,
|s, p| {
let id = album_param(p, "id", "album.addPhotos")?;
- let targets = ids_param(p).unwrap_or_else(|| s.selected());
+ let targets = super::photo_ids(p, "album.addPhotos")?.unwrap_or_else(|| s.selected());
let al = s.catalog.album(id).ok_or_else(|| bad("album.addPhotos", "no such album"))?;
if al.is_smart() || al.folder {
return Err(bad("album.addPhotos", "smart albums and folders can't hold photos"));
@@ -1296,7 +1295,8 @@ pub fn specs() -> Vec {
"{ids?} — B: adds the photos to the target album (the Quick Collection unless one is set), or removes them when they're all in it → {album, added, skipped}; Local photos are skipped",
has_library_selection,
|s, p| {
- let targets = album_targets_or_err(s, "album.toggleTarget", ids_param(p).unwrap_or_else(|| s.selected()))?;
+ let targets =
+ album_targets_or_err(s, "album.toggleTarget", super::photo_ids(p, "album.toggleTarget")?.unwrap_or_else(|| s.selected()))?;
let (targets, skipped) = targets;
let target = s.target_album.filter(|a| s.catalog.album(*a).is_some_and(|al| !al.is_smart() && !al.folder));
let id = match target.or_else(|| s.catalog.quick_collection()) {
@@ -1458,7 +1458,7 @@ pub fn specs() -> Vec {
_ => return Err(bad("album.removePhotos", "no album: pass `id` or show an album")),
},
};
- let targets = ids_param(p).unwrap_or_else(|| s.selected());
+ let targets = super::photo_ids(p, "album.removePhotos")?.unwrap_or_else(|| s.selected());
let al = s.catalog.album(id).ok_or_else(|| bad("album.removePhotos", "no such album"))?;
if al.is_smart() {
return Err(bad("album.removePhotos", "smart albums update automatically: change their rules"));
@@ -1709,12 +1709,21 @@ fn has_library(s: &Session) -> std::result::Result<(), String> {
/// Coordinates typed by a person: "51.5072, -0.1276", "51.5072 N 0.1276 W",
/// "51°30'26\"N 0°7'39\"W" (degrees, minutes, seconds; N/S/E/W or signs).
pub(crate) fn parse_gps(t: &str) -> Option<(f64, f64)> {
+ // typographic minus signs and dashes mean a negative value, like ASCII '-'
+ let t = t.replace(['\u{2212}', '\u{2012}', '\u{2013}', '\u{FE63}', '\u{FF0D}'], "-");
let t = t.trim();
// split into the two coordinates: at a comma, else after the first N/S hemisphere letter
let (a, b) = match t.split_once(',') {
Some((a, b)) => (a.trim().to_string(), b.trim().to_string()),
None => {
- let i = t.find(['N', 'S', 'n', 's']).map(|i| i + 1).or_else(|| t.find(char::is_whitespace))?;
+ let lead = t.starts_with(['N', 'S', 'n', 's']);
+ let i = if lead {
+ // hemisphere letter first: "N 51.5 W 0.1" splits at the E/W letter
+ t.char_indices().skip(1).find(|(_, c)| matches!(c, 'E' | 'W' | 'e' | 'w')).map(|(i, _)| i)
+ } else {
+ t.find(['N', 'S', 'n', 's']).map(|i| i + 1)
+ }
+ .or_else(|| t.find(char::is_whitespace))?;
(t[..i].trim().to_string(), t[i..].trim().to_string())
}
};
@@ -1746,6 +1755,10 @@ mod gps_tests {
assert!((la - 51.50722).abs() < 1e-4 && (lo + 0.1275).abs() < 1e-4, "{la} {lo}");
let (la, lo) = p("33.8688 S, 151.2093 E").unwrap();
assert!((la + 33.8688).abs() < 1e-9 && (lo - 151.2093).abs() < 1e-9);
+ assert_eq!(p("51.5 N 0.1 W"), Some((51.5, -0.1)));
+ assert_eq!(p("N 51.5072 W 0.1276"), Some((51.5072, -0.1276)));
+ assert_eq!(p("S 33.8688 E 151.2093"), Some((-33.8688, 151.2093)));
+ assert_eq!(p("\u{2212}33.8688, 151.2093"), Some((-33.8688, 151.2093)));
assert_eq!(p("95, 10"), None);
assert_eq!(p("hello"), None);
}
diff --git a/crates/engine/src/cmd/lut_profiles.rs b/crates/engine/src/cmd/lut_profiles.rs
index f03809b62..b7a0d4992 100644
--- a/crates/engine/src/cmd/lut_profiles.rs
+++ b/crates/engine/src/cmd/lut_profiles.rs
@@ -17,7 +17,7 @@ pub struct LutProfile {
pub id: String,
pub name: String,
pub group: String,
- /// The `.cube` file (the library's copy when there is a library on disk).
+ /// The library's copy of the `.cube` file (empty without a library on disk).
pub file: String,
}
@@ -123,12 +123,9 @@ fn import(s: &mut Session, p: &Value) -> Result {
std::fs::write(&f, &text).map_err(|e| bad(C, format!("{}: {e}", f.display())))?;
f.to_string_lossy().to_string()
}
- None => {
- // no library on disk: remember the original (the in-memory session ends with the app)
- let f = std::env::temp_dir().join(format!("lightcraft-{}.cube", id.trim_start_matches("lut:")));
- std::fs::write(&f, &text).map_err(|e| bad(C, e.to_string()))?;
- f.to_string_lossy().to_string()
- }
+ // no library on disk: the registered LUT is all this session needs (a copy would only
+ // be read back when a library opens, and that takes its own list from its prefs)
+ None => String::new(),
};
lightcraft_pipeline::lut::register(&id, lut);
s.lut_profiles.push(LutProfile { id: id.clone(), name: display.clone(), group: group.clone(), file });
diff --git a/crates/engine/src/cmd/missing.rs b/crates/engine/src/cmd/missing.rs
index 6f194c652..1bff30d2b 100644
--- a/crates/engine/src/cmd/missing.rs
+++ b/crates/engine/src/cmd/missing.rs
@@ -58,7 +58,7 @@ pub(crate) fn relink_op(id: PhotoId, path: &str) -> Op {
fn relink(s: &mut Session, p: &Value) -> Result {
const C: &str = "photo.relink";
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| bad(C, "no photo (give `id`)"))?;
+ let id = super::photo_id(p, C)?.or(s.active()).ok_or_else(|| bad(C, "no photo (give `id`)"))?;
let path = str_param(p, "path").ok_or_else(|| bad(C, "missing `path`"))?;
let abs = std::path::absolute(path).map_err(|e| bad(C, e.to_string()))?;
if !abs.is_file() {
diff --git a/crates/engine/src/cmd/mod.rs b/crates/engine/src/cmd/mod.rs
index 22af48f44..9b8dc3dbd 100644
--- a/crates/engine/src/cmd/mod.rs
+++ b/crates/engine/src/cmd/mod.rs
@@ -193,6 +193,32 @@ pub(crate) fn names_photos(p: &Value) -> bool {
["ids", "id"].iter().any(|k| p.get(k).is_some_and(|v| !v.is_null()))
}
+/// The photos `ids` names: `None` when it is missing or null (the command then falls back to the
+/// selection, or its own default), else every entry as a photo id. An `ids` that isn't a list of
+/// whole numbers is an error, never `None`: falling back would act on the selection instead of
+/// the photos the call meant (`{"ids": 3}`, `{"ids": ["3"]}`).
+pub(crate) fn photo_ids(p: &Value, cmd: &str) -> Result>> {
+ match p.get("ids") {
+ None | Some(Value::Null) => Ok(None),
+ Some(Value::Array(a)) => a
+ .iter()
+ .map(|v| v.as_u64().map(lightcraft_catalog::PhotoId).ok_or_else(|| bad(cmd, "`ids` must be photo ids (whole numbers)")))
+ .collect::>>()
+ .map(Some),
+ Some(_) => Err(bad(cmd, "`ids` must be a list of photo ids")),
+ }
+}
+
+/// The photo `id` names: `None` when it is missing or null (the command then uses the active
+/// photo), else that id. An `id` that isn't a whole number is an error, never `None`: falling back
+/// would act on the active photo instead of the one the call meant (`{"id": "5"}`).
+pub(crate) fn photo_id(p: &Value, cmd: &str) -> Result> {
+ match p.get("id") {
+ None | Some(Value::Null) => Ok(None),
+ Some(v) => v.as_u64().map(|n| Some(lightcraft_catalog::PhotoId(n))).ok_or_else(|| bad(cmd, "`id` must be a photo id (a whole number)")),
+ }
+}
+
pub(crate) fn bad(cmd: &str, msg: impl Into) -> EngineError {
EngineError::BadParams { cmd: cmd.into(), msg: msg.into() }
}
diff --git a/crates/engine/src/cmd/organize.rs b/crates/engine/src/cmd/organize.rs
index 24cc2061c..dbd0aa842 100644
--- a/crates/engine/src/cmd/organize.rs
+++ b/crates/engine/src/cmd/organize.rs
@@ -161,17 +161,17 @@ pub fn specs() -> Vec {
Ok(json!({"changed": commit_ops(s, "Remove from Stack", ops)?}))
}),
cmd!("stack.setTop", "Set as Top of Stack", ["Photo", "Stack"], Some("Shift+S"), "{id?} (default: the active photo)", in_stack, |s, p| {
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| bad("stack.setTop", "no photo"))?;
+ let id = super::photo_id(p, "stack.setTop")?.or(s.active()).ok_or_else(|| bad("stack.setTop", "no photo"))?;
let op = s.catalog.set_top_ops(id);
Ok(json!({"changed": commit_ops(s, "Set Top of Stack", op.into_iter().collect())?}))
}),
cmd!("stack.moveUp", "Move Up in Stack", ["Photo", "Stack"], None, "{id?} — one place towards the top", in_stack, |s, p| {
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| bad("stack.moveUp", "no photo"))?;
+ let id = super::photo_id(p, "stack.moveUp")?.or(s.active()).ok_or_else(|| bad("stack.moveUp", "no photo"))?;
let op = s.catalog.move_in_stack_ops(id, -1);
Ok(json!({"changed": commit_ops(s, "Move in Stack", op.into_iter().collect())?}))
}),
cmd!("stack.moveDown", "Move Down in Stack", ["Photo", "Stack"], None, "{id?} — one place away from the top", in_stack, |s, p| {
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| bad("stack.moveDown", "no photo"))?;
+ let id = super::photo_id(p, "stack.moveDown")?.or(s.active()).ok_or_else(|| bad("stack.moveDown", "no photo"))?;
let op = s.catalog.move_in_stack_ops(id, 1);
Ok(json!({"changed": commit_ops(s, "Move in Stack", op.into_iter().collect())?}))
}),
@@ -183,17 +183,32 @@ pub fn specs() -> Vec {
"{id?} — this photo and the ones after it become their own stack",
in_stack,
|s, p| {
- let id = p.get("id").and_then(Value::as_u64).map(PhotoId).or(s.active()).ok_or_else(|| bad("stack.split", "no photo"))?;
+ let id = super::photo_id(p, "stack.split")?.or(s.active()).ok_or_else(|| bad("stack.split", "no photo"))?;
let op = s.catalog.split_stack_ops(id).ok_or_else(|| bad("stack.split", "pick a photo below the top of a stack"))?;
Ok(json!({"changed": commit_ops(s, "Split Stack", vec![op])?}))
}
),
- cmd!("stack.toggle", "Expand/Collapse Stack", ["Photo", "Stack"], Some("S"), "{ids?, collapsed?: bool}", in_stack, |s, p| {
- let stacks = stacks_of(s, &s.targets(p)?);
- let first = stacks.first().and_then(|id| s.catalog.stack(*id)).map(|st| st.collapsed).unwrap_or(false);
- let collapsed = bool_or(p, "collapsed", !first);
- set_collapsed(s, stacks, collapsed, if collapsed { "Collapse Stack" } else { "Expand Stack" })
- }),
+ // `ids` names the stacks' photos without selecting them (a click on a stack badge)
+ CommandSpec {
+ explicit_targets: true,
+ ..cmd!(
+ "stack.toggle",
+ "Expand/Collapse Stack",
+ ["Photo", "Stack"],
+ Some("S"),
+ "{ids?, collapsed?: bool} — the stacks of the named photos (else of the selection)",
+ in_stack,
+ |s, p| {
+ let stacks = stacks_of(s, &s.targets(p)?);
+ if stacks.is_empty() {
+ return Err(bad("stack.toggle", "none of the photos is in a stack"));
+ }
+ let first = stacks.first().and_then(|id| s.catalog.stack(*id)).map(|st| st.collapsed).unwrap_or(false);
+ let collapsed = bool_or(p, "collapsed", !first);
+ set_collapsed(s, stacks, collapsed, if collapsed { "Collapse Stack" } else { "Expand Stack" })
+ }
+ )
+ },
cmd!("stack.expandAll", "Expand All Stacks", ["View", "Stacks"], None, "{}", has_stacks, |s, _| {
let all: Vec = s.catalog.stacks().map(|st| st.id).collect();
set_collapsed(s, all, false, "Expand All Stacks")
diff --git a/crates/engine/src/cmd/previews.rs b/crates/engine/src/cmd/previews.rs
index b63ccc2b4..bef292f8f 100644
--- a/crates/engine/src/cmd/previews.rs
+++ b/crates/engine/src/cmd/previews.rs
@@ -176,12 +176,18 @@ fn build(s: &mut Session, p: &Value) -> Result {
}
/// One photo's smart preview to build or discard: (photo, its file in the smart previews folder,
-/// how to load the original at preview size, whether the photo takes the per-file camera look —
-/// `camera_preview::file_local_look`, [`lightcraft_catalog::Photo::fitted_look`]: only those
-/// proxies go stale when the fit changes).
+/// how to load the original at preview size, whether the photo can take a preview-fitted look:
+/// vendor raws and DNGs (whose tone can come from their preview); only those proxies go stale when
+/// the fit changes; an older encoding makes any proxy stale).
#[cfg(not(target_arch = "wasm32"))]
type SmartJob = (lightcraft_catalog::PhotoId, std::path::PathBuf, Option, bool);
+/// DNG tone fits also go stale, although DNGs keep their own matrix and Kelvin white-balance scale.
+#[cfg(not(target_arch = "wasm32"))]
+fn preview_fitted_look(photo: &lightcraft_catalog::Photo) -> bool {
+ photo.fitted_look() || (photo.develops_raw() && photo.format.eq_ignore_ascii_case("DNG"))
+}
+
/// Held while one proxy is checked and (re)written, so Build Smart Previews and the opening look
/// refresh ([`refresh_stale_smart_previews`]), on their own threads, never write the same file at once.
#[cfg(not(target_arch = "wasm32"))]
@@ -205,15 +211,18 @@ struct SmartCounts {
failed: Vec,
}
-/// `source` if it reads the photo's original, else `None`: a cached source decoded from a smart
-/// preview (it has no decoder facts), a proxy standing in for an offline original, and the proxy
-/// fallback of a file source are not the original.
+/// `source` if it reads the photo's original, else `None`. A source decoded from a smart preview
+/// (it now carries the proxy's stored facts), a proxy standing in for an offline original, and the
+/// proxy fallback of a file source are not the original: refreshing a stale proxy from one of them
+/// would stamp its older look as current.
#[cfg(not(target_arch = "wasm32"))]
fn original_only(source: crate::media::SourceRef) -> Option {
use crate::media::SourceRef;
match source {
- SourceRef::File { path, max_edge, loader, denoise, .. } => Some(SourceRef::File { path, max_edge, loader, fallback: None, denoise }),
- SourceRef::Loaded(d) if d.info.is_some() => Some(SourceRef::Loaded(d)),
+ SourceRef::File { path, max_edge, loader, denoise, .. } => {
+ Some(SourceRef::File { path, max_edge, loader, fallback: None, denoise, reduced: None })
+ }
+ SourceRef::Loaded(d) if d.info.is_some() && !d.from_proxy && !d.reduced => Some(SourceRef::Loaded(d)),
_ => None,
}
}
@@ -252,10 +261,11 @@ fn smart_run(
}
} else {
// a complete, current proxy is kept; a missing or damaged one (cut short by a crash or a
- // full drive) is (re)built, and so is one written by an older camera-look fit (see
- // `camera_preview::LOOK_VERSION`) when its original can be read
+ // full drive) is (re)built, and so is one written by an older encoding or camera-look
+ // fit (see `smart::ENCODE_VERSION` and `camera_preview::LOOK_VERSION`) when its
+ // original can be read
let damaged = path.exists();
- let stale = look && damaged && crate::smart::is_stale(&path);
+ let stale = damaged && crate::smart::is_stale_for(&path, look);
if damaged && !stale && crate::smart::is_valid(&path) {
n.built += 1;
} else {
@@ -268,7 +278,10 @@ fn smart_run(
let r = source
.ok_or_else(|| "nothing to build from".to_string())
.and_then(|s| s.load_source())
- .and_then(|src| crate::smart::encode(&src.image, src.info_or(Default::default()).camera_tone.as_ref()))
+ .and_then(|src| {
+ let info = src.info_or(Default::default());
+ crate::smart::encode(&src.image, Some(&info))
+ })
.and_then(|b| {
let parent = path.parent().ok_or_else(|| format!("{}: no parent folder", path.display()))?;
// Only create the leaf shard: do not recreate a missing external drive.
@@ -333,7 +346,7 @@ fn smart(s: &mut Session, p: &Value) -> Result {
}
let path = crate::smart::sharded_file_path(&dir, &ph);
let source = (!discard).then(|| s.media.source_ref(&ph, crate::media::SourceLevel::Preview));
- jobs.push((id, path, source, ph.fitted_look()));
+ jobs.push((id, path, source, preview_fitted_look(&ph)));
}
let custom = s.smart_previews_dir.is_some();
if background {
@@ -360,14 +373,14 @@ fn smart(s: &mut Session, p: &Value) -> Result {
)
}
-/// Bring smart previews written by an older camera-look fit up to date, once per fit version: when
-/// the smart previews folder has not been checked at this `LOOK_VERSION` (its marker,
-/// [`crate::smart::look_checked`]), a worker thread (the UI never waits on the drives) looks at the
-/// proxies of the raws that take the per-file camera look, the only ones the fit reaches (JPEG,
-/// PNG… proxies are never rebuilt), and rebuilds the stale ones from their originals. One whose
-/// original can't be read (offline) is kept as it is, still marked stale in its header: Build
-/// Smart Previews rebuilds it once the original is back. Only existing proxies are touched: none
-/// is built, and a missing folder is never created. Returns the thread, if started.
+/// Bring smart previews up to date, once per fit-and-encoding version: when the smart previews
+/// folder has not been checked at this build's versions (its marker, [`crate::smart::look_checked`]),
+/// a worker thread (the UI never waits on the drives) looks at the proxies of the photos on disk
+/// and rebuilds the stale ones from their originals — one whose stored pixels are an older encoding
+/// (every photo), or, for a raw that takes the per-file camera look or a DNG, one written by an older fit.
+/// One whose original can't be read (offline) is kept as it is, still marked stale in its header:
+/// Build Smart Previews rebuilds it once the original is back. Only existing proxies are touched:
+/// none is built, and a missing folder is never created. Returns the thread, if started.
#[cfg(not(target_arch = "wasm32"))]
pub(crate) fn refresh_stale_smart_previews(s: &mut Session) -> Option> {
let dir = s.media.smart_dir.clone()?;
@@ -375,9 +388,11 @@ pub(crate) fn refresh_stale_smart_previews(s: &mut Session) -> Option = s.catalog.photos().filter(|p| matches!(p.source, lightcraft_catalog::Source::File { .. }) && p.fitted_look()).collect();
- let jobs: Vec =
- photos.iter().map(|p| (p.id, crate::smart::sharded_file_path(&dir, p), Some(s.media.origin_ref(&p.source, max_edge)), true)).collect();
+ let photos: Vec<_> = s.catalog.photos().filter(|p| matches!(p.source, lightcraft_catalog::Source::File { .. })).collect();
+ let jobs: Vec = photos
+ .iter()
+ .map(|p| (p.id, crate::smart::sharded_file_path(&dir, p), Some(s.media.origin_ref(&p.source, max_edge)), preview_fitted_look(p)))
+ .collect();
std::thread::Builder::new()
.name("lc-smart-look".into())
.spawn(move || refresh_stale(&dir, jobs))
@@ -391,7 +406,7 @@ fn refresh_stale(dir: &std::path::Path, jobs: Vec) {
let stale: Vec = jobs
.into_iter()
.map(|(id, path, source, look)| (id, crate::smart::existing_file_path(dir, path), source, look))
- .filter(|(_, path, _, _)| crate::smart::is_stale(path))
+ .filter(|(_, path, _, look)| crate::smart::is_stale_for(path, *look))
.collect();
if !stale.is_empty() {
// `custom`: the folder is there already, and must not be recreated if it went away since
@@ -548,7 +563,8 @@ mod tests {
let mut jobs = jobs_for(&mut s, id, Some(512));
assert_eq!(jobs.len(), 2, "view and thumbnail");
assert!(jobs[0].view_cache.is_some(), "the view renders first");
- jobs[1].source = SourceRef::File { path: "/nonexistent/photo.arw".into(), max_edge: 512, loader: None, fallback: None, denoise: None };
+ jobs[1].source =
+ SourceRef::File { path: "/nonexistent/photo.arw".into(), max_edge: 512, loader: None, fallback: None, denoise: None, reduced: None };
assert!(run_photo(jobs), "the thumbnail rendered from the view's decoded source");
}
diff --git a/crates/engine/src/cmd/query.rs b/crates/engine/src/cmd/query.rs
index fbe4608f0..dfbf4bfc5 100644
--- a/crates/engine/src/cmd/query.rs
+++ b/crates/engine/src/cmd/query.rs
@@ -62,7 +62,7 @@ fn album_json(a: &Album, all: &[Album], cat: &lightcraft_catalog::Catalog, depth
/// The photo a query is about: `id` when given (which must be in the library), else the active one.
fn photo_arg(s: &Session, p: &Value, c: &str) -> crate::Result {
- match p.get("id").and_then(Value::as_u64).map(PhotoId) {
+ match super::photo_id(p, c)? {
Some(id) if s.catalog.photo(id).is_some() => Ok(id),
Some(id) => Err(bad(c, format!("no such photo {}", id.0))),
None => s.active().ok_or_else(|| bad(c, "no photo")),
@@ -139,8 +139,11 @@ pub fn specs() -> Vec {
.into_iter()
.map(|r| json!({"group": r.group, "tag": r.tag, "name": r.name, "value": r.value}))
.collect();
- // XMP: the sidecar if there is one, else the file's own packet
- let packet = crate::sidecar::read_packet(path, ph.kind, s.sidecar_naming(ph.id)).map(|(x, _)| x).or_else(|| lightcraft_meta::embedded(&bytes).xmp);
+ // Keep sidecar precedence; reuse the loaded bytes for embedded XMP.
+ let packet = match crate::sidecar::find_sidecar(path, s.sidecar_naming(ph.id)) {
+ Some(sc) => std::fs::read_to_string(sc).ok(),
+ None => lightcraft_meta::embedded(&bytes).xmp,
+ };
let xmp: Vec = packet
.and_then(|x| lightcraft_meta::parse_xmp(&x).ok())
.map(|d| d.properties.into_iter().filter(|(k, _)| !k.starts_with("lc:")).map(|(k, v)| json!({"name": k, "value": v.join("; ")})).collect())
diff --git a/crates/engine/src/cmd/xmp.rs b/crates/engine/src/cmd/xmp.rs
index fb0ec9883..d48ca3cd2 100644
--- a/crates/engine/src/cmd/xmp.rs
+++ b/crates/engine/src/cmd/xmp.rs
@@ -95,7 +95,7 @@ pub fn specs() -> Vec {
"Read Metadata from File",
["Photo"],
None,
- "{ids?} — reads each photo's XMP sidecar (or a raw/DNG's embedded XMP): metadata and develop settings, one undo step; never writes the sidecar, even with auto-write on → {read, failed, warnings?: [{path, code, profile?, mode?, fields?}]}",
+ "{ids?} — reads each photo's XMP sidecar, or embedded XMP in raw/DNG and JPEG files when no sidecar exists: metadata and develop settings, one undo step; never writes the sidecar, even with auto-write on; JPEG uses the first complete standard XMP APP1 before SOS/EOI, within 16 MiB of headers and 4096 marker/fill steps; an unreadable sidecar fails without embedded fallback → {read, failed, warnings?: [{path, code, profile?, mode?, fields?}]}",
has_selection,
read
),
diff --git a/crates/engine/src/crs.rs b/crates/engine/src/crs.rs
index 9de8c3d64..093f3a84f 100644
--- a/crates/engine/src/crs.rs
+++ b/crates/engine/src/crs.rs
@@ -93,6 +93,17 @@ const NON_ADJUSTMENT: &[&str] = &[
// the file's as-shot white, recorded next to the edit (ours comes from the file itself)
"crs:AsShotTemperature",
"crs:AsShotTint",
+ // which Lightroom version may read the edit, and checksums of the profiles it names
+ "crs:CompatibleVersion",
+ "crs:CameraProfileDigest",
+ "crs:LensProfileDigest",
+ // the lens profile Lightroom picked: ours is the file's own, only `LensProfileEnable` carries over
+ "crs:LensProfileName",
+ "crs:LensProfileFilename",
+ "crs:LensProfileIsEmbedded",
+ "crs:LensProfileSetup",
+ // a crop tool option (keep the crop inside the photo), not the crop itself
+ "crs:CropConstrainToUnitSquare",
];
/// True if the packet carries any `crs:` adjustment (not just bookkeeping fields).
@@ -492,6 +503,8 @@ pub fn to_partial_report(props: &Props, values: Option<&crate::crs_masks::Values
|| k == "AutoTone"
|| k == "AutoGrayscaleMix"
|| (k == "PointColors" && value_is(k, &empty_points))
+ // the lens profile's strength, written at its default (100 %) next to every profile
+ || (matches!(k, "LensProfileDistortionScale" | "LensProfileVignettingScale") && value_is(k, &|v| v.iter().all(|s| s.trim() == "100")))
};
let mut unmapped: Vec = props
.keys()
@@ -869,6 +882,21 @@ mod tests {
assert_eq!(got, ["FutureSlider", "PointColors"]);
}
+ #[test]
+ fn lightroom_profile_bookkeeping_is_not_reported() {
+ // what Lightroom Classic writes next to every raw's edit: none of it changes the rendering
+ let bookkeeping = r#"crs:CompatibleVersion="268435456" crs:CameraProfileDigest="0A1B" crs:LensProfileDigest="2C3D"
+ crs:LensProfileName="Sony FE 24-70mm" crs:LensProfileFilename="x.lcp" crs:LensProfileIsEmbedded="False"
+ crs:LensProfileSetup="LensDefaults" crs:LensProfileDistortionScale="100" crs:LensProfileVignettingScale="100"
+ crs:CropConstrainToUnitSquare="1""#;
+ let look = r#"Vivid ::new());
+ assert_eq!(unmapped(&preset_packet(bookkeeping, look)), ["Look"], "the Look is a real gap");
+ // a lens profile's strength away from 100 % is an adjustment we don't carry over
+ let scaled = preset_packet(r#"crs:LensProfileDistortionScale="60""#, "");
+ assert_eq!(unmapped(&scaled), ["LensProfileDistortionScale"]);
+ }
+
#[test]
fn disabled_lens_profile_switch_keeps_embedded_corrections() {
// Lightroom applies a file's built-in lens corrections regardless of its profile switch,
diff --git a/crates/engine/src/export.rs b/crates/engine/src/export.rs
index a9e3dd21b..bfeade59c 100644
--- a/crates/engine/src/export.rs
+++ b/crates/engine/src/export.rs
@@ -82,7 +82,11 @@ pub enum ResizeMode {
Width,
/// `value` = height in pixels.
Height,
- /// Fit inside `value × height` pixels, whichever way round the photo is (long edge ≤ the larger).
+ /// Fit inside `value` wide × `height` tall as the photo stands: width ≤ `value`, height ≤
+ /// `height` (Lightroom's "Width & Height").
+ WidthHeight,
+ /// Fit inside `value × height` pixels, whichever way round the photo is (long edge ≤ the
+ /// larger; Lightroom's "Dimensions").
Dimensions,
/// `value` = megapixels.
Megapixels,
@@ -96,7 +100,7 @@ pub enum ResizeMode {
pub struct Resize {
pub mode: ResizeMode,
pub value: f32,
- /// Second dimension for [`ResizeMode::Dimensions`].
+ /// Second dimension for [`ResizeMode::Dimensions`] and [`ResizeMode::WidthHeight`].
pub height: u32,
/// Never upscale past the photo's own (cropped) size.
pub dont_enlarge: bool,
@@ -127,6 +131,7 @@ impl Resize {
ResizeMode::ShortEdge => v / short,
ResizeMode::Width => v / w,
ResizeMode::Height => v / h,
+ ResizeMode::WidthHeight => (v / w).min(self.height as f64 / h),
ResizeMode::Dimensions => {
let (a, b) = (v, self.height as f64);
(a.max(b) / long).min(a.min(b) / short)
@@ -721,6 +726,7 @@ pub const OPTION_PARAMS: &[&str] = &[
"height",
"megapixels",
"percent",
+ "fit",
"dontEnlarge",
"ppi",
"limitKb",
@@ -940,6 +946,7 @@ impl ExportOptions {
"longEdge" | "shortEdge" | "width" | "height" | "megapixels" | "percent" => {
num(k, v, 0.0, 1.0e9)?;
}
+ "fit" => one_of(k, v, &["dimensions", "widthHeight"])?,
"resize" => {
let Some(r) = v.as_object() else { return Err(bad(format!("`{k}` must be an object {{mode, value, height?, dontEnlarge?}}"))) };
if let Some(x) = r.keys().find(|x| !matches!(x.as_str(), "mode" | "value" | "height" | "dontEnlarge")) {
@@ -1133,8 +1140,12 @@ impl ExportOptions {
return (r.value > 0.0).then_some(Resize { dont_enlarge: p.get("dontEnlarge").and_then(Value::as_bool).unwrap_or(r.dont_enlarge), ..r });
}
let r = |mode, value: f64| Resize { mode, value: value.min(65_535.0) as f32, height: 0, dont_enlarge };
+ // `fit: widthHeight` binds each edge to its own number; the default fits either orientation
+ let bound = p.get("fit").and_then(Value::as_str).is_some_and(|fit| fit.eq_ignore_ascii_case("widthHeight"));
Some(match (f("width"), f("height")) {
- (Some(w), Some(h)) => Resize { height: h.min(65_535.0) as u32, ..r(ResizeMode::Dimensions, w) },
+ (Some(w), Some(h)) => {
+ Resize { height: h.min(65_535.0) as u32, ..r(if bound { ResizeMode::WidthHeight } else { ResizeMode::Dimensions }, w) }
+ }
(Some(w), None) => r(ResizeMode::Width, w),
(None, Some(h)) => r(ResizeMode::Height, h),
(None, None) => {
@@ -2881,6 +2892,13 @@ mod tests {
assert_eq!(size(json!({"width": 1000, "height": 800}), 6000.0, 4000.0), Some((1000, 667)));
assert_eq!(size(json!({"width": 1000, "height": 800}), 4000.0, 6000.0), Some((667, 1000)));
assert_eq!(size(json!({"width": 1000, "height": 500}), 6000.0, 4000.0), Some((750, 500)));
+ assert_eq!(size(json!({"width": 270, "height": 337, "fit": "dimensions"}), 480.0, 320.0), Some((337, 225)));
+ // Width & Height (`fit: widthHeight`) binds each edge to its own number: W limits the width, H the height (#1620)
+ assert_eq!(size(json!({"width": 270, "height": 337, "fit": "widthHeight"}), 480.0, 320.0), Some((270, 180)));
+ assert_eq!(size(json!({"width": 270, "height": 337, "fit": "widthHeight"}), 320.0, 480.0), Some((225, 337)));
+ assert_eq!(size(json!({"width": 240, "height": 300, "fit": "widthHeight"}), 480.0, 320.0), Some((240, 160)));
+ // `fit` only matters with both numbers
+ assert_eq!(size(json!({"width": 1000, "fit": "widthHeight"}), 6000.0, 4000.0), Some((1000, 667)));
let (w, h) = size(json!({"megapixels": 6}), 6000.0, 4000.0).unwrap();
assert!(((w * h) as f64 - 6e6).abs() < 6e6 * 0.002, "{w}×{h}");
assert_eq!(size(json!({"percent": 25}), 6000.0, 4000.0), Some((1500, 1000)));
@@ -2895,6 +2913,8 @@ mod tests {
let r = Resize { mode: ResizeMode::ShortEdge, value: 720.0, height: 0, dont_enlarge: false };
let back = ExportOptions::from_json(&ExportOptions::resize_json(Some(&r))).resize;
assert_eq!(back, Some(r));
+ let r = Resize { mode: ResizeMode::WidthHeight, value: 270.0, height: 337, dont_enlarge: true };
+ assert_eq!(ExportOptions::from_json(&ExportOptions::resize_json(Some(&r))).resize, Some(r));
assert_eq!(ExportOptions::from_json(&ExportOptions::resize_json(None)).resize, None);
assert_eq!(ExportOptions::from_json(&json!({"ppi": 300})).ppi, 300);
// never larger than the encoders' limit, never empty
@@ -2966,6 +2986,7 @@ mod tests {
mode(ResizeMode::Width, value, 0),
mode(ResizeMode::Height, value, 0),
mode(ResizeMode::Dimensions, value, 1365),
+ mode(ResizeMode::WidthHeight, value, 1365),
mode(ResizeMode::Megapixels, value / 1000.0, 0),
mode(ResizeMode::Percent, value / 100.0, 0),
] {
@@ -3262,6 +3283,7 @@ mod tests {
assert!(err(json!({"bitDepth": 12})).contains("`bitDepth` must be 8, 10, 16 or 32"));
assert!(err(json!({"colorSpace": "cmyk"})).contains("`colorSpace` must be one of"));
assert!(err(json!({"dontEnlarge": "no"})).contains("`dontEnlarge` must be true or false"));
+ assert!(err(json!({"fit": "sideways"})).contains("`fit` must be one of dimensions|widthHeight"));
assert!(err(json!({"resize": {"mode": "longEdge", "valeu": 10}})).contains("did you mean `value`"));
assert!(err(json!({"resize": {"mode": "diagonal", "value": 10}})).contains("`resize`:"));
assert!(err(json!({"ids": [1, "x"]})).contains("`ids` must be an array of photo ids"));
diff --git a/crates/engine/src/files.rs b/crates/engine/src/files.rs
index 31bb930fb..0670fb763 100644
--- a/crates/engine/src/files.rs
+++ b/crates/engine/src/files.rs
@@ -11,7 +11,7 @@ use lightcraft_pipeline::SourceInfo;
use lightcraft_raster::Rgb32f;
use lightcraft_raster::resample::{Filter, fit};
-use crate::media::{DenoiseSpec, FileLoader, FileProbe, PairLoader, PreviewLoader, ProbeInfo};
+use crate::media::{DenoiseSpec, FileLoader, FileProbe, PairLoader, PreviewLoader, ProbeInfo, ReducedLoader};
fn meta_of(m: &lightcraft_meta::Metadata) -> (Meta, Option) {
let shutter = m.exposure_time.map(|t| if t >= 1.0 { format!("{t:.0}") } else { format!("1/{:.0}", 1.0 / t) }).unwrap_or_default();
@@ -366,20 +366,27 @@ pub fn bin_factor(raw: &lightcraft_raw::RawImage, max_edge: usize) -> Option Result<(Rgb32f, SourceInfo), String> {
- rayon::scope(|_| load_bytes_now(std::borrow::Cow::Borrowed(bytes), max_edge, None).map(|(img, _, info)| (img, info)))
+ rayon::scope(|_| load_bytes_now(std::borrow::Cow::Borrowed(bytes), max_edge, None, false).map(|(img, _, info, _)| (img, info)))
}
/// [`load_bytes`] taking the file's bytes: a raw file's bytes are freed as soon as it is decoded
/// (less memory held while it is developed).
pub fn load_vec(bytes: Vec, max_edge: usize) -> Result<(Rgb32f, SourceInfo), String> {
- rayon::scope(move |_| load_bytes_now(std::borrow::Cow::Owned(bytes), max_edge, None).map(|(img, _, info)| (img, info)))
+ rayon::scope(move |_| load_bytes_now(std::borrow::Cow::Owned(bytes), max_edge, None, false).map(|(img, _, info, _)| (img, info)))
+}
+
+/// [`load_vec`] for a thumbnail: a DNG that keeps reduced-resolution copies of its raw image (Lightroom's HDR and
+/// panorama merges) develops the smallest that covers `max_edge` instead of the whole image. The flag says whether
+/// it did: such a picture is not the full image, and an export never renders from it.
+pub fn load_vec_reduced(bytes: Vec, max_edge: usize) -> Result<(Rgb32f, SourceInfo, bool), String> {
+ rayon::scope(move |_| load_bytes_now(std::borrow::Cow::Owned(bytes), max_edge, None, true).map(|(img, _, info, reduced)| (img, info, reduced)))
}
/// [`load_vec`] that also develops the photo's cached denoised picture (`spec`) from the same decode: the plain
/// picture, the denoised one (`None` when it cannot be read or does not fit this raw: the plain one is then all
/// there is) and the source facts. Both pictures are the same size.
pub fn load_vec_pair(bytes: Vec, max_edge: usize, spec: &DenoiseSpec) -> Result<(Rgb32f, Option, SourceInfo), String> {
- rayon::scope(move |_| load_bytes_now(std::borrow::Cow::Owned(bytes), max_edge, Some(spec)))
+ rayon::scope(move |_| load_bytes_now(std::borrow::Cow::Owned(bytes), max_edge, Some(spec), false).map(|(img, twin, info, _)| (img, twin, info)))
}
/// The denoised camera RGB of `raw` from its cached product, as the plain development would have it: the default
@@ -408,14 +415,25 @@ fn load_bytes_now(
bytes: std::borrow::Cow<'_, [u8]>,
max_edge: usize,
denoise: Option<&DenoiseSpec>,
-) -> Result<(Rgb32f, Option, SourceInfo), String> {
+ allow_reduced: bool,
+) -> Result<(Rgb32f, Option, SourceInfo, bool), String> {
if lightcraft_raw::probe(&bytes).is_some() {
- let mut raw = match lightcraft_raw::decode(&bytes).map_err(|e| preview_reason(&bytes, e)) {
+ // a thumbnail (`allow_reduced`, never an export) of a DNG that keeps smaller copies of its raw image
+ // (Lightroom's merges) develops the smallest that covers it; a denoised photo's twin needs the full mosaic
+ let reduced = (allow_reduced && denoise.is_none() && max_edge < usize::MAX)
+ .then(|| lightcraft_raw::decode_reduced(&bytes, max_edge).ok().flatten())
+ .flatten();
+ let used_reduced = reduced.is_some();
+ let decoded = match reduced {
+ Some(r) => Ok(r),
+ None => lightcraft_raw::decode(&bytes),
+ };
+ let mut raw = match decoded.map_err(|e| preview_reason(&bytes, e)) {
Ok(r) => r,
Err(Ok(why)) => {
// show the camera's embedded JPEG (rendered, not raw) until the variant is supported
return load_embedded_preview(&bytes, max_edge)
- .map(|(img, info)| (img, None, info))
+ .map(|(img, info)| (img, None, info, false))
.ok_or(format!("unsupported raw ({why}) without an embedded preview"));
}
Err(Err(e)) => return Err(e),
@@ -426,13 +444,26 @@ fn load_bytes_now(
let lens = crate::lens_profiles::for_raw(&info, || lightcraft_meta::extract(&bytes));
// (the camera look still pairs the sensor with the camera JPEG through the warp the camera applied to it)
let lens_geometry = crate::camera_preview::lens_geometry(&raw.opcodes.list3);
+ // A DNG's preview already has its lens opcodes applied. Keep them for its single tone fit,
+ // then remove them again: the rendered source leaves those corrections to the pipeline.
+ let dng_lens_ops = (raw.format == lightcraft_raw::RawFormat::Dng && raw.opcodes.list3.iter().any(|op| op.is_lens_correction()))
+ .then(|| raw.opcodes.list3.clone());
raw.opcodes.list3.retain(|op| !op.is_lens_correction());
// Which scale white balance is edited on, and the as-shot white on it, from the file's own colour tags or
// the camera's measured matrices (`Photo::relative_wb` decides the same from the catalog's camera)
let scale = WbScaleOf::new(raw.format, &raw.color, raw.wb_multipliers, &raw.metadata);
// the source's segmentation mattes (DNG semantic masks), read while the starting colour is fitted
let ((xy, t, camera_look), mattes) = rayon::join(
- || crate::camera_preview::starting_colour(&mut raw, &bytes, lens_geometry.as_ref(), lens.as_ref()),
+ || {
+ let removed = dng_lens_ops.map(|ops| std::mem::replace(&mut raw.opcodes.list3, ops));
+ // With the opcodes restored, the proxy already includes vignetting; do not apply it twice.
+ let embedded = if removed.is_some() { None } else { lens.as_ref() };
+ let colour = crate::camera_preview::starting_colour(&mut raw, &bytes, lens_geometry.as_ref(), embedded);
+ if let Some(ops) = removed {
+ raw.opcodes.list3 = ops;
+ }
+ colour
+ },
|| dng_mattes(&bytes, &info),
);
drop(bytes);
@@ -529,13 +560,14 @@ fn load_bytes_now(
// (the catalog knows the original's size: `media::source_info`)
native_long: None,
},
+ used_reduced,
));
}
let d = lightcraft_codecs::decode(&bytes, fit_box(max_edge)).map_err(|e| e.to_string())?;
drop(bytes);
let img = d.to_working();
let img = if img.width.max(img.height) > max_edge { fit(&img, max_edge, max_edge, Filter::Mitchell) } else { img };
- Ok((img.into_oriented(Orientation::from_exif(d.orientation)), None, SourceInfo::default()))
+ Ok((img.into_oriented(Orientation::from_exif(d.orientation)), None, SourceInfo::default(), false))
}
/// Which white-balance scale a raw is edited on, decided from the file alone, the way the catalog decides it from
@@ -1060,17 +1092,7 @@ pub fn fs_pair_loader() -> PairLoader {
/// interactive loads (the loupe, exports) never wait — they are counted, so background work
/// yields to them.
pub fn fs_hooks() -> (FileLoader, FileProbe) {
- let loader: FileLoader = Arc::new(|path: &str, max_edge: usize| {
- let len = std::fs::metadata(path).map(|m| usize::try_from(m.len()).unwrap_or(usize::MAX)).unwrap_or(0);
- let weight = len * if max_edge <= crate::media::SourceLevel::Thumb.max_edge() { 3 } else { 6 };
- let gate = crate::memory::work_gate();
- let _permit = if crate::memory::is_background() { gate.acquire(weight) } else { gate.acquire_urgent(weight) };
- let bytes = std::fs::read(path).map_err(|e| format!("{path}: {e}"))?;
- let r = load_vec(bytes, max_edge);
- // the file, the samples and the intermediate images are gone: give their pages back
- crate::memory::release();
- r
- });
+ let loader: FileLoader = Arc::new(|path: &str, max_edge: usize| fs_load(path, max_edge, |bytes| load_vec(bytes, max_edge)));
let probe: FileProbe = Arc::new(|path: &str| {
let len = std::fs::metadata(path).map(|m| usize::try_from(m.len()).unwrap_or(usize::MAX)).unwrap_or(0);
let _permit = crate::memory::work_gate().acquire(len);
@@ -1082,6 +1104,24 @@ pub fn fs_hooks() -> (FileLoader, FileProbe) {
(loader, probe)
}
+/// The filesystem [`ReducedLoader`]: [`load_vec_reduced`] of the file, gated like [`fs_hooks`]' loader.
+pub fn fs_reduced_loader() -> ReducedLoader {
+ Arc::new(|path: &str, max_edge: usize| fs_load(path, max_edge, |bytes| load_vec_reduced(bytes, max_edge)))
+}
+
+/// Read `path` and `load` it, waiting on [`crate::memory::work_gate`] as [`fs_hooks`] explains.
+fn fs_load(path: &str, max_edge: usize, load: impl FnOnce(Vec) -> Result) -> Result {
+ let len = std::fs::metadata(path).map(|m| usize::try_from(m.len()).unwrap_or(usize::MAX)).unwrap_or(0);
+ let weight = len.saturating_mul(if max_edge <= crate::media::SourceLevel::Thumb.max_edge() { 3 } else { 6 });
+ let gate = crate::memory::work_gate();
+ let _permit = if crate::memory::is_background() { gate.acquire(weight) } else { gate.acquire_urgent(weight) };
+ let bytes = std::fs::read(path).map_err(|e| format!("{path}: {e}"))?;
+ let r = load(bytes);
+ // the file, the samples and the intermediate images are gone: give their pages back
+ crate::memory::release();
+ r
+}
+
/// `path`'s modification time as ISO 8601 (see [`ProbeInfo::file_modified`]); `None` when the
/// filesystem doesn't say or the time is before 1970.
fn file_modified(path: &str) -> Option {
@@ -1096,6 +1136,7 @@ impl crate::Session {
pub fn with_fs(mut self) -> Self {
let (l, p) = fs_hooks();
self.media.file_loader = Some(l);
+ self.media.reduced_loader = Some(fs_reduced_loader());
self.media.file_probe = Some(p);
self.media.preview_loader = Some(fs_preview_loader());
self.media.denoise.loader = Some(fs_pair_loader());
@@ -1183,6 +1224,21 @@ pub(crate) mod tests {
let (t, tint) = a99m2.as_shot(d65);
assert!((5000.0..6000.0).contains(&t) && tint.abs() < 10.0 && t.fract() == 0.0, "{t} {tint}");
assert!(!lightcraft_catalog::relative_wb_camera("ARW", "SONY ILCA-99M2"));
+ // a Canon body without matrices, through the presets its ColorData lists (PowerShot G1 X Mark III, a
+ // Daylight shot with the camera's white balance shifted towards blue: below Daylight's 5651 K)
+ let canon = lightcraft_raw::kelvin_presets::KelvinPresets::from_unordered([
+ (5651.0, g(1418.0, 1357.0)),
+ (7505.0, g(1653.0, 1171.0)),
+ (6594.0, g(1533.0, 1259.0)),
+ (3174.0, g(963.0, 2016.0)),
+ (8529.0, g(1807.0, 1080.0)),
+ ]);
+ let with_canon = ColorData { kelvin_presets: canon, ..Default::default() };
+ let g1x3 = WbScaleOf::new(RawFormat::Cr2, &with_canon, Some(g(1264.0, 1537.0)), &meta("Canon", "Canon PowerShot G1 X Mark III"));
+ assert!(!g1x3.relative && g1x3.scale_white.is_some());
+ let (t, tint) = g1x3.as_shot(d65);
+ assert!((4300.0..5200.0).contains(&t) && tint.abs() < 10.0, "{t} {tint}");
+ assert!(!lightcraft_catalog::relative_wb_camera("CR2", "Canon Canon PowerShot G1 X Mark III"));
let bare = WbScaleOf::new(RawFormat::Arw, &ColorData::default(), mul, &meta("SONY", "ILCA-99M2"));
assert!(bare.legacy_relative && bare.scale_white.is_none());
// presets in a file of a camera not listed: relative, as the catalog decides from the camera alone
@@ -1659,6 +1715,49 @@ pub(crate) mod tests {
Some((best.1, best.0))
}
+ #[test]
+ fn corpus_a7cr_warp_keeps_coordinates_after_orientation_and_resizing() {
+ use lightcraft_geom::{Orientation, Point};
+ use lightcraft_pipeline::optics::Warp;
+ let root = std::env::var_os("LIGHTCRAFT_CORPUS")
+ .map(std::path::PathBuf::from)
+ .unwrap_or_else(|| std::path::Path::new(env!("CARGO_MANIFEST_DIR")).join("../../corpus"));
+ for name in ["arw-sony-a7cr-compressed.arw", "arw-sony-a7cr-lossless-l.arw"] {
+ let Ok(mut bytes) = std::fs::read(root.join("raw").join(name)) else { continue };
+ let off = lightcraft_raw::probe_info(&bytes).unwrap();
+ assert!(embedded_lens(&off).is_none());
+ let tiff = lightcraft_tiff::Tiff::parse(&bytes).unwrap();
+ let at = tiff.find(0x7036).unwrap().offset as usize;
+ let mut enabled = Vec::new();
+ tiff.order.put_u16(&mut enabled, 17);
+ bytes[at..at + 2].copy_from_slice(&enabled);
+ let mut raw = lightcraft_raw::probe_info(&bytes).unwrap();
+ raw.orientation = Orientation::Normal;
+ let mut settings = lightcraft_develop::DevelopSettings::default();
+ settings.optics.lens_profile = true;
+ let base_lens = embedded_lens(&raw).unwrap();
+ let base = Warp::from_settings(9504.0, 6336.0, &settings, Some(&base_lens));
+ for orientation in 1..=8 {
+ let o = Orientation::from_exif(orientation);
+ raw.orientation = o;
+ let lens = embedded_lens(&raw).unwrap();
+ for edge in [1200.0, 2560.0, 9504.0] {
+ let scale = edge / 9504.0;
+ let (w, h) = if o.swaps_axes() { (6336.0 * scale, edge) } else { (edge, 6336.0 * scale) };
+ let oriented = Warp::from_settings(w, h, &settings, Some(&lens));
+ for (x, y) in [(0.05, 0.1), (0.5, 0.5), (0.9, 0.8)] {
+ let point = Point::new(x * 9504.0, y * 6336.0);
+ let source = base.corrected_to_source(point, 1);
+ let (px, py) = o.map(point.x, point.y, 9504.0, 6336.0);
+ let (sx, sy) = o.map(source.x, source.y, 9504.0, 6336.0);
+ let got = oriented.corrected_to_source(Point::new(px * scale, py * scale), 1);
+ assert!((got.x - sx * scale).hypot(got.y - sy * scale) < 1e-8, "{name} orientation {orientation} edge {edge}");
+ }
+ }
+ }
+ }
+ }
+
/// Issue #256: public Panasonic / Leica raws (skipped without the corpus) are corrected for distortion the way the
/// camera corrected its own JPEG (tag 0x0119): at the corners of the frame, the render with "Enable Profile
/// Corrections" lines up with the embedded JPEG within 2 px at 640 px, while the uncorrected render of the wide
@@ -1831,6 +1930,98 @@ pub(crate) mod tests {
assert!((mean(&dim) / mean(&before) - 0.5).abs() < 0.02, "{} vs {}", mean(&dim), mean(&before));
}
+ /// Corrections used while fitting a DNG's preview must not be baked into its editable source.
+ /// The pipeline applies them once from SourceInfo, and a file-defined tone stays authoritative.
+ #[test]
+ fn dng_preview_corrections_leave_the_render_source_uncorrected() {
+ let plain = crate::tests_xmp::synthetic_dng_with(None, Default::default());
+ let mut raw = lightcraft_raw::decode(&plain).unwrap();
+ raw.color.profile.tone_curve = lightcraft_raw::profile::ToneCurve::from_tag(&[0.0, 0.0, 0.18, 0.4, 1.0, 1.0]);
+ let before = lightcraft_raw::write_dng(&raw, &Default::default()).unwrap();
+ raw.opcodes.list3 = vec![lightcraft_raw::Opcode::FixVignetteRadial { k: [1.0, 0.0, 0.0, 0.0, 0.0], center: [0.5, 0.5] }];
+ let corrected = lightcraft_raw::write_dng(&raw, &Default::default()).unwrap();
+ let (before, expected) = load_bytes(&before, 64).unwrap();
+ let (after, info) = load_bytes(&corrected, 64).unwrap();
+ assert_eq!(before.data, after.data, "lens correction belongs to the pipeline");
+ assert!(info.lens.as_ref().is_some_and(|l| l.vignette.is_some()));
+ assert_eq!(info.camera_tone, expected.camera_tone, "the file's own tone is preserved");
+ }
+
+ /// A camera JPEG made from the corrected scene teaches one tone to the DNG's existing fit.
+ /// The source pixels stay uncorrected, including when the file is rotated.
+ #[test]
+ fn dng_lens_corrected_preview_teaches_one_tone_without_baking_in_the_lens() {
+ use lightcraft_color::{REC2020, SRGB, luminance_2020, transfer::linear_to_srgb};
+ use lightcraft_raw::{Opcode, Orientation};
+ let (w, h) = (384usize, 256usize);
+ let data = (0..w * h)
+ .map(|i| {
+ let (x, y) = ((i % w) as f32, (i / w) as f32);
+ let v = 0.02 + 0.2 * (0.5 + 0.5 * (x * 0.045).sin() * (y * 0.06).cos()) + 0.1 * x / w as f32;
+ let colour = match (i / w % 2, i % w % 2) {
+ (0, 0) => 1.2,
+ (1, 1) => 0.8,
+ _ => 1.0,
+ };
+ 256 + (v * colour * 15744.0) as u16
+ })
+ .collect();
+ let bytes = crate::tests_xmp::synthetic_dng_of(w, h, "RGGB", data, None, Default::default());
+ let mut raw = lightcraft_raw::decode(&bytes).unwrap();
+ raw.color = lightcraft_raw::ColorData {
+ illuminant: [21, 0],
+ color_matrix: [Some(REC2020.from_xyz()), None],
+ as_shot_neutral: Some([1.0; 3]),
+ ..Default::default()
+ };
+ let plain = lightcraft_raw::write_dng(&raw, &Default::default()).unwrap();
+ raw.opcodes.list3 = vec![
+ Opcode::FixVignetteRadial { k: [0.8, 0.0, 0.0, 0.0, 0.0], center: [0.5, 0.5] },
+ Opcode::WarpRectilinear { planes: vec![[0.7, 0.2, 0.0, 0.0, 0.0, 0.0]], center: [0.5, 0.5] },
+ ];
+ let t = lightcraft_raw::color::camera_transform(&raw, lightcraft_raw::color::as_shot_white_xy(&raw));
+ let corrected = raw.develop(lightcraft_raw::Method::Bilinear).unwrap();
+ let to_srgb = REC2020.to_space(&SRGB);
+ let pixels: Vec = corrected
+ .data
+ .iter()
+ .flat_map(|p| {
+ let p = t.matrix.apply_f32(std::array::from_fn(|i| p[i] * t.wb[i]));
+ let y = luminance_2020(p).max(1e-6);
+ let gain = (1.0 - (-3.0 * y).exp()) / y;
+ to_srgb.apply_f32(p.map(|v| v * gain)).map(|v| (255.0 * linear_to_srgb(v).clamp(0.0, 1.0)).round() as u8)
+ })
+ .collect();
+ let image = lightcraft_codecs::EncodeImage::new(w as u32, h as u32, 3, lightcraft_codecs::Samples::U8(&pixels));
+ let jpeg = lightcraft_codecs::encode_jpeg(&image, 98, lightcraft_codecs::ChromaSubsampling::S444, &Default::default()).unwrap();
+ for orientation in [Orientation::Normal, Orientation::Rotate90] {
+ raw.orientation = orientation;
+ let mut file = lightcraft_raw::write_dng(&raw, &Default::default()).unwrap();
+ // Append a preview IFD to the little-endian DNG written above.
+ let root = u32::from_le_bytes(file[4..8].try_into().unwrap()) as usize;
+ let count = u16::from_le_bytes(file[root..root + 2].try_into().unwrap()) as usize;
+ let next = root + 2 + 12 * count;
+ let start = file.len() as u32;
+ file[next..next + 4].copy_from_slice(&start.to_le_bytes());
+ let jpeg_at = start + 2 + 4 * 12 + 4;
+ file.extend(4u16.to_le_bytes());
+ for (tag, value) in [(256u16, w as u32), (257, h as u32), (0x201, jpeg_at), (0x202, jpeg.len() as u32)] {
+ file.extend(tag.to_le_bytes());
+ file.extend(4u16.to_le_bytes());
+ file.extend(1u32.to_le_bytes());
+ file.extend(value.to_le_bytes());
+ }
+ file.extend(0u32.to_le_bytes());
+ file.extend(&jpeg);
+ let (source, info) = load_bytes(&file, 96).unwrap();
+ let tone = info.camera_tone.expect("one DNG look fitted to the lens-corrected preview");
+ let target = 1.0 - (-3.0f32 * 0.18).exp();
+ assert!((tone.apply(0.18) - target).abs() < 0.04, "one tone: {} vs {target}", tone.apply(0.18));
+ let expected = load_bytes(&plain, 96).unwrap().0.into_oriented(orientation);
+ assert_eq!(source.data, expected.data, "the editable source is not lens-corrected");
+ }
+ }
+
/// A look fitted to a camera's JPEG, as `camera_preview` makes them: its rows don't sum to one, so the camera's
/// own white-balanced neutral comes out yellow (blue 12 % low).
fn yellowing_look() -> lightcraft_color::Mat3 {
@@ -2090,6 +2281,84 @@ pub(crate) mod tests {
}
}
+ /// A Lightroom merge (a LinearRaw DNG keeping a reduced copy of its raw image): its grid thumbnail develops the
+ /// copy, but an export never does, whatever its size, and not from the thumbnail's source in memory either. The
+ /// copy's samples are much brighter than the image's here, so a picture says which one it came from.
+ #[test]
+ fn exports_never_develop_a_dngs_reduced_copy() {
+ use lightcraft_tiff::tags::{self as t, photometric};
+ use lightcraft_tiff::{ByteOrder, IfdBuilder, ImageData, TiffWriter, Value};
+ use serde_json::json;
+ let linear = |subfile: u32, w: u32, h: u32, sample: u16| {
+ let mut ifd = IfdBuilder::new();
+ ifd.set(t::NEW_SUBFILE_TYPE, Value::Long(vec![subfile]));
+ ifd.set(t::IMAGE_WIDTH, Value::Long(vec![w]));
+ ifd.set(t::IMAGE_LENGTH, Value::Long(vec![h]));
+ ifd.set(t::BITS_PER_SAMPLE, Value::Short(vec![16, 16, 16]));
+ ifd.set(t::SAMPLES_PER_PIXEL, Value::Short(vec![3]));
+ ifd.set(t::PHOTOMETRIC, Value::Short(vec![photometric::LINEAR_RAW]));
+ ifd.set(t::COMPRESSION, Value::Short(vec![1]));
+ ifd.set(t::WHITE_LEVEL, Value::Long(vec![32768]));
+ ifd.set_image(ImageData::Strips { rows_per_strip: h, strips: vec![sample.to_le_bytes().repeat((w * h * 3) as usize)] });
+ ifd
+ };
+ // (the copy must cover a thumbnail source's 512 px)
+ let (w, h) = (1200u32, 600u32);
+ let mut main = linear(0, w, h, 1500);
+ main.set(t::DEFAULT_CROP_ORIGIN, Value::Long(vec![4, 2]));
+ main.set(t::DEFAULT_CROP_SIZE, Value::Long(vec![w - 8, h - 4]));
+ let mut ifd0 = IfdBuilder::new();
+ ifd0.set(t::NEW_SUBFILE_TYPE, Value::Long(vec![1]));
+ ifd0.set(t::DNG_VERSION, Value::Byte(vec![1, 7, 0, 0]));
+ ifd0.set(t::MAKE, Value::Ascii("DJI".into()));
+ ifd0.set(t::COLOR_MATRIX_1, Value::SRational(vec![(1, 1), (0, 1), (0, 1), (0, 1), (1, 1), (0, 1), (0, 1), (0, 1), (1, 1)]));
+ ifd0.set(t::CALIBRATION_ILLUMINANT_1, Value::Short(vec![21]));
+ ifd0.set(t::PHOTOMETRIC, Value::Short(vec![photometric::RGB]));
+ ifd0.set(t::IMAGE_WIDTH, Value::Long(vec![4]));
+ ifd0.set(t::IMAGE_LENGTH, Value::Long(vec![2]));
+ ifd0.set(t::BITS_PER_SAMPLE, Value::Short(vec![8, 8, 8]));
+ ifd0.set(t::SAMPLES_PER_PIXEL, Value::Short(vec![3]));
+ ifd0.set(t::COMPRESSION, Value::Short(vec![1]));
+ ifd0.set_image(ImageData::Strips { rows_per_strip: 2, strips: vec![vec![128; 24]] });
+ ifd0.add_sub_ifd(main);
+ ifd0.add_sub_ifd(linear(1, w / 2, h / 2, 24000));
+ let bytes = TiffWriter::new(ByteOrder::Little, false).write(&[ifd0]).unwrap();
+ let g = |img: &Rgb32f| img.data.iter().map(|p| p[1] as f64).sum::() / img.data.len().max(1) as f64;
+ let mean = |img: &lightcraft_raster::Rgba8| img.data.iter().map(|p| p[1] as f64).sum::() / img.data.len().max(1) as f64;
+
+ // the loaders: only the thumbnail's develops the copy, and only when it covers the size
+ let (copy, _, used) = load_vec_reduced(bytes.clone(), 512).unwrap();
+ assert!(used, "a thumbnail develops the copy");
+ assert!(!load_vec_reduced(bytes.clone(), 1024).unwrap().2, "no copy covers 1024 px");
+ let (full, _) = load_vec(bytes.clone(), 512).unwrap();
+ assert!(g(©) > 4.0 * g(&full), "the fixture's copy is much brighter: {} vs {}", g(©), g(&full));
+
+ let dir = std::env::temp_dir().join(format!("lc-reduced-export-{}", std::process::id()));
+ std::fs::create_dir_all(&dir).unwrap();
+ let path = dir.join("merge-pano.dng");
+ std::fs::write(&path, &bytes).unwrap();
+ let mut s = crate::Session::new().with_fs();
+ let r = s.execute("library.import", &json!({"paths": [path.to_string_lossy()]})).unwrap();
+ let id = lightcraft_catalog::PhotoId(r["imported"][0].as_u64().unwrap());
+ let (space, depth) = (lightcraft_pipeline::OutputSpace::Srgb, lightcraft_pipeline::OutputDepth::U8);
+ // an export at a thumbnail's size, before any thumbnail
+ assert_eq!(s.export_job(id, 64, 64, space, depth).unwrap().level, crate::media::SourceLevel::Thumb);
+ let export = mean(&s.render_export(id, 64, 64, space, depth).unwrap().image);
+ // the thumbnail develops the copy and its source stays in memory…
+ s.media.clear_sources();
+ let thumb = s.thumb_job(id, 64).unwrap().run();
+ assert!(thumb.loaded.as_ref().is_some_and(|l| l.reduced));
+ let thumb_mean = mean(&thumb.rendered.as_ref().unwrap().image);
+ s.accept(&thumb);
+ assert!(thumb_mean > export + 20.0, "the thumbnail shows the copy: {thumb_mean} vs {export}");
+ // …and an export after it still reads the full image
+ let job = s.export_job(id, 64, 64, space, depth).unwrap();
+ assert!(matches!(&job.source, crate::media::SourceRef::File { reduced: None, .. }), "the file, not the copy");
+ let again = mean(&s.render_export(id, 64, 64, space, depth).unwrap().image);
+ assert!((again - export).abs() < 1.0, "{again} vs {export}");
+ let _ = std::fs::remove_dir_all(&dir);
+ }
+
/// iPhone ProRAW-style semantic masks drive the Sky mask: Apple's sky matte (here the right
/// half of the sensor, i.e. the bottom of the photo once turned 90° clockwise — where the sky
/// heuristic would never look) is used; a matte with an unknown name is ignored.
@@ -2393,8 +2662,8 @@ pub(crate) mod tests {
}
}
- /// Recognised raw containers we don't decode (Minolta MRW here: the preview's first byte is
- /// overwritten in the file) import as preview only with the JPEG's size, instead of failing.
+ /// Recognised raw containers we can't decode (an MRW whose block header is damaged here; its preview's first
+ /// byte is overwritten, as in real MRW files) import as preview only with the JPEG's size, instead of failing.
#[test]
fn undecodable_container_with_a_preview_imports_as_preview_only() {
let px: Vec = (0..40 * 30).flat_map(|i| [(i % 251) as u8, 128, 200]).collect();
diff --git a/crates/engine/src/import.rs b/crates/engine/src/import.rs
index 7a3bc1f05..bc8c1c962 100644
--- a/crates/engine/src/import.rs
+++ b/crates/engine/src/import.rs
@@ -32,10 +32,11 @@ use serde::{Deserialize, Serialize};
use crate::Session;
use crate::media::ProbeInfo;
-/// File extensions LightCraft imports (lower case).
+/// File extensions offered by import discovery and file pickers (lower case).
+/// This includes preview-only raws; the file probe decides whether sensor decoding is available.
pub const EXTENSIONS: &[&str] = &[
- "jpg", "jpeg", "png", "tif", "tiff", "webp", "dng", "cr2", "cr3", "nef", "nrw", "arw", "raf", "orf", "rw2", "rwl", "raw", "pef", "srw", "psd",
- "jxl", "gif", "bmp",
+ "jpg", "jpeg", "png", "tif", "tiff", "webp", "dng", "cr2", "cr3", "nef", "nrw", "arw", "sr2", "srf", "raf", "orf", "rw2", "rwl", "raw", "pef",
+ "srw", "psd", "jxl", "gif", "bmp",
// Decoded when built with the codecs' `heif` feature; otherwise the import reports them as
// failed with the reason ("HEIC/HEIF support isn't included in this build").
"heic", "heif", "avif", // no AV1 decoder yet: reported as failed, like a HEIC without the feature
@@ -691,6 +692,11 @@ pub(crate) fn scan_files(mut input: ScanInput, files: Vec, progress: &Sc
.iter()
.map(|f| {
let info = input.cache.remove(f)?;
+ // (✕ set while the files' cached probes are checked: no more round trips to the disk; what is
+ // not reached counts as not probed, like the files after it)
+ if progress.cancel.load(Relaxed) {
+ return None;
+ }
let size = std::fs::metadata(f).map(|m| m.len()).ok();
(size.is_none() || size == Some(info.file_size)).then_some(info)
})
diff --git a/crates/engine/src/lens_profiles.rs b/crates/engine/src/lens_profiles.rs
index 6338b3b40..6e7f28120 100644
--- a/crates/engine/src/lens_profiles.rs
+++ b/crates/engine/src/lens_profiles.rs
@@ -40,7 +40,15 @@ pub fn database() -> Option<&'static LensDb> {
pub fn lookup(db: &LensDb, m: &lightcraft_meta::Metadata, w: f64, h: f64, orientation: lightcraft_geom::Orientation) -> Option {
let focal = m.focal_length.filter(|f| f.is_finite() && *f > 0.0)?;
let camera = db.find_camera(m.make.as_deref().unwrap_or_default(), m.model.as_deref().unwrap_or_default());
- let lens = db.find_lens(m.lens_make.as_deref(), m.lens_model.as_deref()?, camera)?;
+ let lens = match m.lens_model.as_deref() {
+ Some(model) => db.find_lens(m.lens_make.as_deref(), model, camera)?,
+ // Nikon DSLRs record only the lens specification ("24-70mm f/2.8"); a profile must be named exactly that
+ // (a user's alias), since the specification fits other makers' lenses too
+ None => {
+ let name = lightcraft_lensdb::spec_name(m.lens_spec?);
+ db.find_lens_named(m.lens_make.as_deref(), &name, camera)?
+ }
+ };
let crop = frame_crop_factor(camera.map(|c| c.crop_factor), focal, m.focal_length_35mm);
let shot = Shot { focal, aperture: m.f_number, distance: None, crop_factor: crop, width: w, height: h };
let corr = lens.correction(&shot)?;
@@ -108,6 +116,27 @@ mod tests {
assert!(lookup(&db, &other, 6000.0, 4000.0, Orientation::Normal).is_none());
}
+ /// A Nikon DSLR raw names no lens, only its specification (maker note `0x0084`): it is looked up by the name
+ /// built from it, and only a profile named exactly that is used, never another maker's lens that merely shares
+ /// the focal range and aperture.
+ #[test]
+ fn lens_specification_needs_a_profile_named_by_it() {
+ let nikon = lightcraft_meta::Metadata { lens_model: None, lens_spec: Some([18.0, 55.0, 3.5, 5.6]), ..meta() };
+ let at = |db: &LensDb| lookup(db, &nikon, 6000.0, 4000.0, Orientation::Normal);
+ // "Testcam 18-55mm f/3.5-5.6" fits the specification, but so would any maker's 18-55 f/3.5-5.6: refused
+ assert!(at(&LensDb::parse(DB).unwrap()).is_none());
+ let aliased = LensDb::parse(
+ &DB.replace("Testcam 18-55mm f/3.5-5.6 ", "Testcam 18-55mm f/3.5-5.6 18-55mm f/3.5-5.6 "),
+ )
+ .unwrap();
+ let lens = at(&aliased).unwrap();
+ assert!(lens.warp.is_some() && lens.vignette.is_some());
+ assert_eq!(Some(lens), lookup(&aliased, &meta(), 6000.0, 4000.0, Orientation::Normal), "same profile as by its name");
+ // a lens model, when the file has one, still decides
+ let named_other = lightcraft_meta::Metadata { lens_model: Some("70-200mm F4".into()), ..nikon.clone() };
+ assert!(lookup(&aliased, &named_other, 6000.0, 4000.0, Orientation::Normal).is_none());
+ }
+
/// A full-frame body in APS-C / Super 35 mode (an ILCE-1M2 at 70 mm records 105 mm equivalent) frames only the
/// middle of the image circle: the profile is applied at the frame's crop factor, not the body's, so the crop's
/// corners don't get the full frame's corner correction.
diff --git a/crates/engine/src/lib.rs b/crates/engine/src/lib.rs
index ec7c9f7e7..323ed90ef 100644
--- a/crates/engine/src/lib.rs
+++ b/crates/engine/src/lib.rs
@@ -950,7 +950,16 @@ impl Session {
return Vec::new();
}
let Some(old) = self.develop_of(id) else { return Vec::new() };
- let Some(mut delta) = json_delta(&old.to_json(), &new.to_json()) else { return Vec::new() };
+ let mut old_json = old.to_json();
+ let mut new_json = new.to_json();
+ // False is omitted from stored profile JSON. Keep it explicit for this comparison so
+ // switching camera local tone mapping off is a change without copying untouched values.
+ old_json["profile"]["camera_local_tone"] = Value::Bool(old.profile.camera_local_tone);
+ new_json["profile"]["camera_local_tone"] = Value::Bool(new.profile.camera_local_tone);
+ // Compare actual HDR leaves even when persisted defaults omit the whole HDR object.
+ old_json["hdr"] = serde_json::json!(old.hdr);
+ new_json["hdr"] = serde_json::json!(new.hdr);
+ let Some(mut delta) = json_delta(&old_json, &new_json) else { return Vec::new() };
if let Some(o) = delta.as_object_mut() {
for k in ["spots", "red_eye", "version", "process"] {
o.remove(k);
@@ -1328,6 +1337,8 @@ mod tests_history_cursor;
#[cfg(test)]
mod tests_hold_view;
#[cfg(test)]
+mod tests_ids_params;
+#[cfg(test)]
mod tests_import;
#[cfg(test)]
mod tests_import_move;
diff --git a/crates/engine/src/library.rs b/crates/engine/src/library.rs
index 32ad1da53..a5071b4b3 100644
--- a/crates/engine/src/library.rs
+++ b/crates/engine/src/library.rs
@@ -558,7 +558,10 @@ impl Session {
self.selection.ids.retain(|id| self.catalog.photo(*id).is_some());
self.selection.active = self.selection.active.filter(|id| self.catalog.photo(*id).is_some());
}
+ // not on Missing Photos: working that view out checks every original (minutes on a
+ // sleeping NAS), and the app checks them in the background once it runs
if self.selection.active.is_none()
+ && self.source != LibrarySource::Missing
&& let Some(first) = self.visible_cloned().first()
{
self.selection = Selection::single(*first);
diff --git a/crates/engine/src/media.rs b/crates/engine/src/media.rs
index 6805f8537..292a9fb1e 100644
--- a/crates/engine/src/media.rs
+++ b/crates/engine/src/media.rs
@@ -62,7 +62,7 @@ impl SettingsHashes {
}
/// Bump when the pipeline's output changes, to invalidate cached thumbnails.
-pub const RENDER_CACHE_VERSION: u64 = 65;
+pub const RENDER_CACHE_VERSION: u64 = 69;
/// Thumbnails render at one of these long edges (so window/cell size changes reuse the cache).
pub const THUMB_SIZES: [usize; 4] = [128, 256, 384, 512];
@@ -132,6 +132,11 @@ fn source_edge_needed(p: &Photo, settings: &DevelopSettings, apply_crop: bool, o
/// Decodes a file into a linear Rec.2020 image no larger than `max_edge` (set by the app).
pub type FileLoader = Arc Result<(Rgb32f, SourceInfo), String> + Send + Sync>;
+/// [`FileLoader`] for a thumbnail: a raw file that keeps smaller copies of its raw image (Lightroom's merged DNGs)
+/// develops the smallest that covers `max_edge` (set by the app); the flag says it did. Never used for an export,
+/// which must render the full image.
+pub type ReducedLoader = Arc Result<(Rgb32f, SourceInfo, bool), String> + Send + Sync>;
+
/// A raw file's embedded (camera-rendered) preview as display sRGB, oriented, no larger than
/// `max_edge` (set by the app). `None`: no usable preview.
pub type PreviewLoader = Arc Option + Send + Sync>;
@@ -183,11 +188,17 @@ pub struct DecodedSource {
pub camera_tone: Option,
/// The same picture developed from the AI-denoised mosaic, when the photo has one cached.
pub denoised: Option>,
+ /// These pixels came from the photo's smart preview (an offline original), not from its file.
+ /// A refresh must never rebuild a proxy from itself: that would stamp its older look as current.
+ pub from_proxy: bool,
+ /// Developed from a smaller copy of the raw image that the file keeps ([`ReducedLoader`]), not from the image
+ /// itself: good for a thumbnail, never for an export.
+ pub reduced: bool,
}
impl DecodedSource {
pub fn new(image: Arc, info: Option) -> Self {
- DecodedSource { image, info, camera_tone: None, denoised: None }
+ DecodedSource { image, info, camera_tone: None, denoised: None, from_proxy: false, reduced: false }
}
/// The picture to develop for a Denoise `amount` (0 to 1, see [`DevelopSettings::denoise_amount`]): the plain one,
@@ -258,6 +269,8 @@ pub enum SourceRef {
fallback: Option,
/// The photo has a cached denoised picture: load it with the plain one (see [`PairLoader`]).
denoise: Option<(DenoiseSpec, PairLoader)>,
+ /// A thumbnail's loader, used instead of `loader` (see [`ReducedLoader`]); `None` for every other job.
+ reduced: Option,
},
/// A smart preview standing in for a missing original.
Smart {
@@ -283,10 +296,13 @@ impl SourceRef {
return Ok(DecodedSource { image: Arc::new(image), denoised: None, ..(**from).clone() });
}
SourceRef::Demo { scene, max_edge } => crate::demo::scene_pixels(scene, *max_edge)?,
- SourceRef::File { path, max_edge, loader, fallback, denoise } => {
- let plain = || match loader {
- Some(l) => l(path, *max_edge).map(|(image, info)| DecodedSource::new(Arc::new(image), Some(info))),
- None => Err(format!("no decoder available for {path}")),
+ SourceRef::File { path, max_edge, loader, fallback, denoise, reduced } => {
+ let plain = || match (reduced, loader) {
+ (Some(l), _) => {
+ l(path, *max_edge).map(|(image, info, reduced)| DecodedSource { reduced, ..DecodedSource::new(Arc::new(image), Some(info)) })
+ }
+ (None, Some(l)) => l(path, *max_edge).map(|(image, info)| DecodedSource::new(Arc::new(image), Some(info))),
+ (None, None) => Err(format!("no decoder available for {path}")),
};
// the denoised picture comes with the plain one from a single decode; when it cannot be read the
// pair loader gives the plain picture alone (the cached file is never a reason to fail a render)
@@ -308,6 +324,8 @@ impl SourceRef {
info: Some(info),
camera_tone: None,
denoised: twin.map(|t| Arc::new(Twin::new(Arc::new(t)))),
+ from_proxy: false,
+ reduced: false,
})
})
} else {
@@ -353,6 +371,8 @@ pub struct MediaCache {
/// share of [`crate::memory::budget`]); the least recently used entry of any of them goes first.
budget: usize,
pub file_loader: Option,
+ /// What grid thumbnails load files with (see [`ReducedLoader`]); `None`: [`Self::file_loader`].
+ pub reduced_loader: Option,
pub file_probe: Option,
pub preview_loader: Option,
/// Reads a photo file's bytes (Photo Merge); `None` = the local file system.
@@ -428,6 +448,7 @@ impl Default for MediaCache {
preview_capacity: 0,
budget,
file_loader: None,
+ reduced_loader: None,
file_probe: None,
preview_loader: None,
file_bytes: None,
@@ -720,11 +741,11 @@ impl MediaCache {
}
match self.scenes.iter().find(|s| s.id == *scene) {
Some(s) => SourceRef::Demo { scene: Box::new(s.clone()), max_edge },
- None => SourceRef::File { path: format!("demo:{scene}"), max_edge, loader: None, fallback: None, denoise: None },
+ None => SourceRef::File { path: format!("demo:{scene}"), max_edge, loader: None, fallback: None, denoise: None, reduced: None },
}
}
Source::File { path } => {
- SourceRef::File { path: path.clone(), max_edge, loader: self.file_loader.clone(), fallback: None, denoise: None }
+ SourceRef::File { path: path.clone(), max_edge, loader: self.file_loader.clone(), fallback: None, denoise: None, reduced: None }
}
}
}
@@ -1238,7 +1259,12 @@ impl crate::Session {
/// (≥ `long_edge`) and the result comes from / goes to the thumbnail cache (memory + disk).
pub fn thumb_job(&mut self, id: PhotoId, long_edge: usize) -> Option {
let b = thumb_bucket(long_edge);
- self.build_job(id, b, b, false, true, Some(b))
+ let mut job = self.build_job(id, b, b, false, true, Some(b))?;
+ // (a thumbnail may develop a smaller copy of the raw image that the file keeps)
+ if let SourceRef::File { reduced, .. } = &mut job.source {
+ reduced.clone_from(&self.media.reduced_loader);
+ }
+ Some(job)
}
fn build_job(
@@ -1650,6 +1676,17 @@ impl crate::Session {
depth: lightcraft_pipeline::OutputDepth,
) -> Result {
let mut job = self.render_job(id, max_w, max_h, false, true).ok_or("no such photo")?;
+ // An export renders the full image: never a thumbnail's source developed from a smaller copy of the raw
+ // image that the file keeps (Lightroom's merged DNGs)
+ let reduced = match &job.source {
+ SourceRef::Loaded(s) => s.reduced,
+ SourceRef::Fit { from, .. } => from.reduced,
+ _ => false,
+ };
+ if reduced {
+ let p = self.catalog.photo(id).ok_or("no such photo")?.clone();
+ job.source = self.media.source_ref_uncached(&p, job.level);
+ }
// An export is made from the denoised picture its Denoise amount asks for, made when the job runs if the
// background queue has not got to it. (A source kept in memory may lack the picture, so the job reads the file.)
if let Some(wanted) = self.denoise_for_export(id, &job.settings)? {
@@ -1928,6 +1965,7 @@ mod tests {
})),
fallback: None,
denoise: None,
+ reduced: None,
};
job.info = SourceInfo::default(); // Header facts cannot override decoder facts.
job.settings = Arc::new(DevelopSettings::default());
@@ -1983,6 +2021,7 @@ mod tests {
loader: Some(Arc::new(move |_, _| Ok((loaded_pixels.clone(), loaded_info.clone())))),
fallback: None,
denoise: None,
+ reduced: None,
};
let undo_before = s.undo.len();
let request = job.request;
diff --git a/crates/engine/src/merge.rs b/crates/engine/src/merge.rs
index 26c69c63d..76bcfd7f2 100644
--- a/crates/engine/src/merge.rs
+++ b/crates/engine/src/merge.rs
@@ -404,10 +404,12 @@ pub fn parse(id: &str, p: &Value) -> Result<(MergeKind, MergeFinish)> {
}
impl Session {
- /// Plan a merge of `ids` (catalog order of the given ids is kept).
+ /// Plan a merge of `ids` (catalog order of the given ids is kept). A photo named more than once is merged once
+ /// (issue #1947): it adds nothing to the merge, and each copy would be decoded and held in memory.
pub fn plan_merge(&self, kind: MergeKind, finish: MergeFinish, ids: &[PhotoId], preview: bool) -> Result {
let mut sources = Vec::new();
- for id in ids {
+ let mut seen = std::collections::HashSet::new();
+ for id in ids.iter().filter(|id| seen.insert(**id)) {
let p = self.catalog.photo(*id).ok_or(lightcraft_catalog::CatalogError::NoPhoto(*id))?;
match &p.source {
Source::File { path } => sources.push((*id, path.clone())),
diff --git a/crates/engine/src/sidecar.rs b/crates/engine/src/sidecar.rs
index 2e1092140..d13b95125 100644
--- a/crates/engine/src/sidecar.rs
+++ b/crates/engine/src/sidecar.rs
@@ -27,8 +27,10 @@
//! else `photoshop:DateCreated`, else `xmp:CreateDate`) fills in only when the file has none; develop
//! settings are restored from `lc:settings` when present, else mapped from interoperable `crs:`
//! fields ([`crate::crs`]). For raw/DNG files without a sidecar the file's embedded XMP is used.
+//! Manual reads also accept the first complete standard XMP APP1 in a bounded JPEG header (see `read_jpeg_xmp`).
use std::collections::{HashMap, HashSet};
+use std::io::{Read, Seek, SeekFrom};
use std::path::{Path, PathBuf};
use std::sync::Arc;
@@ -520,18 +522,77 @@ fn file_path(p: &Photo) -> Option<&str> {
}
}
-/// The XMP packet that describes a photo on disk: its sidecar, else (raw/DNG) the embedded XMP.
+/// The XMP packet that describes a photo on disk: its sidecar, else embedded raw/DNG or JPEG XMP.
pub fn read_packet(original: &str, kind: MediaKind, naming: SidecarNaming) -> Option<(String, PathBuf)> {
- if let Some(sc) = find_sidecar(original, naming)
- && let Ok(s) = std::fs::read_to_string(&sc)
- {
- return Some((s, sc));
+ if let Some(sc) = find_sidecar(original, naming) {
+ // A discovered sidecar keeps precedence even when reading it fails.
+ return std::fs::read_to_string(&sc).ok().map(|s| (s, sc));
}
if kind == MediaKind::Raw {
let bytes = std::fs::read(original).ok()?;
let x = lightcraft_meta::embedded(&bytes).xmp?;
return Some((x, PathBuf::from(original)));
}
+ if kind == MediaKind::Image {
+ let mut file = std::fs::File::open(original).ok()?;
+ let x = read_jpeg_xmp(&mut file, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS)?;
+ return Some((x, PathBuf::from(original)));
+ }
+ None
+}
+
+const JPEG_XMP_HEADER_SPAN: u64 = 16 * 1024 * 1024;
+const JPEG_XMP_HEADER_STEPS: usize = 4096;
+
+/// Read from SOI at the current position, stopping at the first standard XMP packet or SOS/EOI.
+/// The span includes SOI, segment headers and skipped payloads; each marker/fill step after SOI
+/// consumes one iteration. Only a complete APP1 payload (at most 65533 bytes) reaches the shared
+/// parser, in a single SOI+APP1 wrapper (at most 65539 bytes). This does not validate the whole JPEG.
+fn read_jpeg_xmp(reader: &mut (impl Read + Seek), header_span: u64, marker_steps: usize) -> Option {
+ let mut header = reader.take(header_span);
+ let mut soi = [0; 2];
+ header.read_exact(&mut soi).ok()?;
+ if soi != [0xff, 0xd8] {
+ return None;
+ }
+ let mut filled = false;
+ for _ in 0..marker_steps {
+ if !filled {
+ let mut prefix = [0];
+ header.read_exact(&mut prefix).ok()?;
+ if prefix != [0xff] {
+ return None;
+ }
+ }
+ let mut code = [0];
+ header.read_exact(&mut code).ok()?;
+ let [marker] = code;
+ filled = marker == 0xff;
+ match marker {
+ 0xff | 0xd8 | 0xd0..=0xd7 | 0x01 => continue,
+ 0xd9 | 0xda => return None,
+ _ => {}
+ }
+ let mut length = [0; 2];
+ header.read_exact(&mut length).ok()?;
+ let payload_len = u16::from_be_bytes(length).checked_sub(2)?;
+ let remaining = header.limit().checked_sub(u64::from(payload_len))?;
+ if marker != 0xe1 {
+ // Seeking must spend the same span budget as reading, before the seek is attempted.
+ header.set_limit(remaining);
+ header.get_mut().seek(SeekFrom::Current(i64::from(payload_len))).ok()?;
+ continue;
+ }
+ let segment_len = 6usize.checked_add(usize::from(payload_len))?;
+ let [hi, lo] = length;
+ let mut segment = Vec::with_capacity(segment_len);
+ segment.extend_from_slice(&[0xff, 0xd8, 0xff, 0xe1, hi, lo]);
+ segment.resize(segment_len, 0);
+ header.read_exact(segment.get_mut(6..)?).ok()?;
+ if let Some(xmp) = lightcraft_meta::jpeg_segments(&segment).xmp {
+ return Some(xmp);
+ }
+ }
None
}
@@ -1019,3 +1080,220 @@ mod tests_repair_provenance;
#[cfg(test)]
#[path = "sidecar/tests_stem_owners.rs"]
mod tests_stem_owners;
+
+#[cfg(test)]
+mod jpeg_header_tests {
+ use super::{JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS, read_jpeg_xmp};
+ use std::io::{self, Cursor, Read, Seek, SeekFrom};
+
+ struct CountedReader {
+ cursor: Cursor>,
+ bytes_read: usize,
+ largest_read: usize,
+ seeks: usize,
+ chunk: usize,
+ read_error_at: Option,
+ seek_error: bool,
+ }
+
+ impl CountedReader {
+ fn new(bytes: Vec) -> Self {
+ Self { cursor: Cursor::new(bytes), bytes_read: 0, largest_read: 0, seeks: 0, chunk: usize::MAX, read_error_at: None, seek_error: false }
+ }
+ }
+
+ impl Read for CountedReader {
+ fn read(&mut self, buf: &mut [u8]) -> io::Result {
+ self.largest_read = self.largest_read.max(buf.len());
+ if self.read_error_at.is_some_and(|at| self.cursor.position() >= at) {
+ return Err(io::Error::other("injected header read failure"));
+ }
+ let len = buf.len().min(self.chunk);
+ let read = self.cursor.read(&mut buf[..len])?;
+ self.bytes_read += read;
+ Ok(read)
+ }
+ }
+
+ impl Seek for CountedReader {
+ fn seek(&mut self, pos: SeekFrom) -> io::Result {
+ self.seeks += 1;
+ if self.seek_error {
+ return Err(io::Error::other("injected header seek failure"));
+ }
+ self.cursor.seek(pos)
+ }
+ }
+
+ fn segment(marker: u8, payload: &[u8]) -> Vec {
+ let len = u16::try_from(payload.len() + 2).unwrap();
+ let mut bytes = vec![0xff, marker];
+ bytes.extend_from_slice(&len.to_be_bytes());
+ bytes.extend_from_slice(payload);
+ bytes
+ }
+
+ fn packet(rating: i8) -> String {
+ lightcraft_meta::write_xmp(&lightcraft_meta::Metadata { rating: Some(rating), ..Default::default() }, None)
+ }
+
+ fn xmp_segment(packet: &str) -> Vec {
+ let mut payload = b"http://ns.adobe.com/xap/1.0/\0".to_vec();
+ payload.extend_from_slice(packet.as_bytes());
+ segment(0xe1, &payload)
+ }
+
+ fn jpeg(packet: &str) -> Vec {
+ let mut bytes = vec![0xff, 0xd8];
+ bytes.extend(xmp_segment(packet));
+ bytes
+ }
+
+ #[test]
+ fn first_standard_packet_skips_other_segments_and_stops_before_tail() {
+ let first = packet(2);
+ let first_payload_len = xmp_segment(&first).len() - 4;
+ let mut bytes = vec![0xff, 0xd8];
+ bytes.extend(segment(0xe0, &[7; 17]));
+ bytes.extend(segment(0xe1, b"Exif\0\0tiny"));
+ let mut extended = b"http://ns.adobe.com/xmp/extension/\0".to_vec();
+ extended.extend_from_slice(&[0; 40]);
+ extended.extend_from_slice(b"not a standard packet");
+ bytes.extend(segment(0xe1, &extended));
+ bytes.extend(xmp_segment(&first));
+ let end = bytes.len();
+ bytes.extend(xmp_segment(&packet(5)));
+ bytes.extend_from_slice(&[0xff, 0xda, 0, 2]);
+ bytes.extend_from_slice(&[3; 128]);
+ let mut reader = CountedReader::new(bytes);
+ reader.read_error_at = Some(end as u64);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), Some(first));
+ assert_eq!(reader.cursor.position(), end as u64, "later packets and image bytes are not read");
+ assert_eq!(reader.bytes_read, end - 17, "APP0 payload is skipped, not buffered");
+ assert_eq!(reader.seeks, 1);
+ assert_eq!(reader.largest_read, first_payload_len, "reads at most one complete APP1 payload at a time");
+ }
+
+ #[test]
+ fn stops_at_sos_or_eoi_without_reading_later_xmp() {
+ for stop in [0xda, 0xd9] {
+ let mut bytes = vec![0xff, 0xd8, 0xff, stop];
+ bytes.extend(xmp_segment(&packet(3)));
+ let mut reader = CountedReader::new(bytes);
+ reader.read_error_at = Some(4);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!((reader.bytes_read, reader.cursor.position(), reader.seeks), (4, 4, 0));
+ }
+ }
+
+ #[test]
+ fn rejects_incomplete_app1_even_when_partial_xmp_parses() {
+ let expected = packet(4);
+ let mut bytes = jpeg(&expected);
+ let declared = u16::from_be_bytes([bytes[4], bytes[5]]) + 7;
+ bytes[4..6].copy_from_slice(&declared.to_be_bytes());
+ let partial = lightcraft_meta::jpeg_segments(&bytes).xmp.unwrap();
+ assert_eq!(partial, expected, "the shared extractor tolerates a truncated declared payload");
+ assert_eq!(super::parse_sidecar(&partial, crate::crs::Target::Rendered).unwrap().rating, Some(4));
+ let len = bytes.len();
+ let mut reader = CountedReader::new(bytes);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!(reader.bytes_read, len);
+ }
+
+ #[test]
+ fn span_budget_counts_soi_headers_and_skipped_payloads() {
+ let expected = packet(3);
+ let mut bytes = vec![0xff, 0xd8];
+ bytes.extend(segment(0xe0, &[9; 23]));
+ bytes.extend(xmp_segment(&expected));
+ let end = bytes.len();
+ let mut exact = CountedReader::new(bytes.clone());
+ assert_eq!(read_jpeg_xmp(&mut exact, end as u64, JPEG_XMP_HEADER_STEPS), Some(expected));
+ assert_eq!(exact.cursor.position(), end as u64, "a complete early APP1 does not require EOI");
+ assert_eq!(exact.bytes_read, end - 23);
+ let mut short = CountedReader::new(bytes);
+ assert_eq!(read_jpeg_xmp(&mut short, (end - 1) as u64, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!((short.bytes_read, short.cursor.position(), short.seeks), (10, 33, 1), "reject before APP1 payload read");
+ assert_eq!(short.largest_read, 2);
+ }
+
+ #[test]
+ fn span_budget_rejects_skip_before_seeking() {
+ let mut bytes = vec![0xff, 0xd8];
+ bytes.extend(segment(0xe0, &[8; 18]));
+ bytes.extend(xmp_segment(&packet(1)));
+ let mut reader = CountedReader::new(bytes);
+ assert_eq!(read_jpeg_xmp(&mut reader, 6, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!((reader.bytes_read, reader.cursor.position(), reader.seeks), (6, 6, 0));
+ }
+
+ #[test]
+ fn marker_budget_counts_fill_and_standalone_markers() {
+ let expected = packet(1);
+ // Two fill steps, SOI, TEM, RST3, then APP1: six steps after the initial SOI.
+ let mut bytes = vec![0xff, 0xd8, 0xff, 0xff, 0xff, 0xd8, 0xff, 0x01, 0xff, 0xd3];
+ bytes.extend(xmp_segment(&expected));
+ for (steps, end) in [(0, 2), (5, 10)] {
+ let mut reader = CountedReader::new(bytes.clone());
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, steps), None);
+ assert_eq!((reader.bytes_read, reader.cursor.position()), (end, end as u64));
+ }
+ let mut reader = CountedReader::new(bytes);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, 6), Some(expected));
+ }
+
+ #[test]
+ fn rejects_invalid_headers_and_segment_lengths() {
+ for bytes in [
+ vec![],
+ vec![0xff],
+ b"\x89PNG\r\n\x1a\n".to_vec(),
+ vec![0xff, 0xd8, 0, 0xe1, 0, 2],
+ vec![0xff, 0xd8, 0xff, 0xe1, 0],
+ vec![0xff, 0xd8, 0xff, 0xe1, 0, 0],
+ vec![0xff, 0xd8, 0xff, 0xe1, 0, 1],
+ vec![0xff, 0xd8, 0xff, 0xe1, 0, 3],
+ ] {
+ let len = bytes.len();
+ let mut reader = CountedReader::new(bytes);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), None);
+ assert!(reader.bytes_read <= len);
+ }
+ }
+
+ #[test]
+ fn propagates_read_and_seek_failures() {
+ for at in [0, 6] {
+ let mut reader = CountedReader::new(jpeg(&packet(4)));
+ reader.read_error_at = Some(at);
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!(reader.bytes_read as u64, at);
+ }
+ let mut bytes = vec![0xff, 0xd8];
+ bytes.extend(segment(0xe0, &[1]));
+ bytes.extend(xmp_segment(&packet(4)));
+ let mut reader = CountedReader::new(bytes);
+ reader.seek_error = true;
+ assert_eq!(read_jpeg_xmp(&mut reader, JPEG_XMP_HEADER_SPAN, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!((reader.bytes_read, reader.seeks), (6, 1));
+ }
+
+ #[test]
+ fn handles_short_reads_without_bypassing_span_limit() {
+ let expected = packet(2);
+ let bytes = jpeg(&expected);
+ let end = bytes.len();
+ let mut exact = CountedReader::new(bytes.clone());
+ exact.chunk = 1;
+ assert_eq!(read_jpeg_xmp(&mut exact, end as u64, JPEG_XMP_HEADER_STEPS), Some(expected));
+ assert_eq!(exact.bytes_read, end);
+ for (span, read) in [(0, 0), (1, 1), (end - 1, 6)] {
+ let mut reader = CountedReader::new(bytes.clone());
+ reader.chunk = 1;
+ assert_eq!(read_jpeg_xmp(&mut reader, span as u64, JPEG_XMP_HEADER_STEPS), None);
+ assert_eq!(reader.bytes_read, read);
+ assert!(reader.cursor.position() <= span as u64);
+ }
+ }
+}
diff --git a/crates/engine/src/smart.rs b/crates/engine/src/smart.rs
index 46b18e0c9..9f72e0f48 100644
--- a/crates/engine/src/smart.rs
+++ b/crates/engine/src/smart.rs
@@ -3,15 +3,19 @@
//! originals are offline (an unplugged drive). The proxy is the scene-linear source scaled into
//! 0..1 by a stored factor, sRGB-encoded and saved as a JPEG after a one-line header. The header
//! also keeps the decoder's file-local camera tone curve (Sony ARW camera look), which is applied
-//! at render time and is not baked into the pixels.
+//! at render time and is not baked into the pixels, and the file's other decoder facts (its colour
+//! model, gain table map and semantic mattes) ride in a tail after the JPEG, so offline edits
+//! interpret the stored pixels the same way the online source did.
use std::path::{Path, PathBuf};
use std::sync::Arc;
use lightcraft_catalog::Photo;
use lightcraft_color::transfer::linear_to_srgb;
+use lightcraft_pipeline::SourceInfo;
+use lightcraft_pipeline::masks::{MatteKind, Mattes};
use lightcraft_pipeline::tone::CameraTone;
-use lightcraft_raster::{Rgb32f, Rgba8};
+use lightcraft_raster::{Image, Rgb32f, Rgba8};
const MAGIC: &[u8] = b"LCSP1\n";
@@ -70,15 +74,73 @@ const JPEG_QUALITY: u8 = 97;
/// tracks the camera-look fit that is baked into those pixels.
const ENC_FIELD: &str = "enc";
-/// The value of [`ENC_FIELD`] this build writes. Bump it whenever [`encode`]'s mapping or JPEG
-/// settings change, so proxies an older build wrote are rebuilt: a missing field reads as 0, which
-/// makes every proxy from before this version stale. Version 2 is the first to record the field at
-/// all (a version 1 proxy is stored at JPEG quality 92, which this build raises to [`JPEG_QUALITY`]).
+/// The value of [`ENC_FIELD`] this build writes. Bump it whenever [`encode`]'s mapping, JPEG
+/// settings or stored facts change, so proxies an older build wrote are rebuilt: a missing field
+/// reads as 0, which makes every proxy from before this version stale. Version 2 is the first to
+/// record the field at all (a version 1 proxy is stored at JPEG quality 92, which this build
+/// raises to [`JPEG_QUALITY`]); version 3 is the first to store the decoder facts in the tail. A
+/// stale proxy whose original is offline is kept as it is (see [`is_stale`]).
/// Crate-visible so the look-marker test pins the marker format to it instead of to a literal.
-pub(crate) const ENCODE_VERSION: u64 = 2;
+pub(crate) const ENCODE_VERSION: u64 = 3;
-/// Encode a source image (and the decoder's camera tone curve, if any) as a smart preview.
-pub fn encode(img: &Rgb32f, tone: Option<&CameraTone>) -> Result, String> {
+/// The decoder facts a render interprets its settings against, stored with the proxy's pixels so
+/// an offline original edits like it did online (the catalog's header facts cannot carry them).
+/// In the proxy's tail, not its header: a real file's gain table map runs far past any header
+/// budget (up to 12 336 gains).
+#[derive(serde::Serialize, serde::Deserialize)]
+struct SmartFacts {
+ raw: bool,
+ as_shot_temp: f64,
+ as_shot_tint: f64,
+ relative_wb: bool,
+ legacy_relative_wb: bool,
+ lens: Option,
+ camera_color: Option,
+ local_tone: Option,
+ /// The semantic mattes whose bytes follow the facts, in this order.
+ #[serde(default)]
+ mattes: Vec,
+}
+
+/// One stored matte's shape; its `len` bytes of 0..255 alpha follow the facts.
+#[derive(serde::Serialize, serde::Deserialize)]
+struct StoredMatte {
+ kind: u8,
+ w: usize,
+ h: usize,
+ len: usize,
+}
+
+/// The facts and mattes a proxy's tail holds: the length-prefixed JSON, then one byte plane per
+/// stored matte. `None` for an old proxy or a malformed tail; like a missing curve, the offline
+/// render then keeps its header facts.
+fn stored_facts(head: &serde_json::Value, bytes: &[u8]) -> Option<(SmartFacts, Mattes)> {
+ let tail = usize::try_from(head.get("tail")?.as_u64()?).ok()?;
+ if tail == 0 || tail > bytes.len() {
+ return None;
+ }
+ let t = bytes.get(bytes.len() - tail..)?;
+ let n = u32::from_le_bytes(t.get(..4)?.try_into().ok()?) as usize;
+ let facts: SmartFacts = serde_json::from_slice(t.get(4..4 + n)?).ok()?;
+ let mut mattes = Mattes::default();
+ let mut at = 4 + n;
+ for m in &facts.mattes {
+ let kind = MatteKind::from_code(m.kind)?;
+ if m.w == 0 || m.h == 0 || m.w.checked_mul(m.h)? != m.len {
+ return None;
+ }
+ mattes.push(kind, Image { width: m.w, height: m.h, data: t.get(at..at.checked_add(m.len)?)?.to_vec() });
+ at += m.len;
+ }
+ if at != t.len() {
+ return None;
+ }
+ Some((facts, mattes))
+}
+
+/// Encode a source image and its decoder facts (the camera tone curve and the [`SourceInfo`] the
+/// render interprets settings against, if given) as a smart preview.
+pub fn encode(img: &Rgb32f, info: Option<&SourceInfo>) -> Result, String> {
// scale so all but the brightest 0.05 % fit into 0..1
let mut lum: Vec = img.data.iter().map(|c| c[0].max(c[1]).max(c[2])).filter(|v| v.is_finite()).collect();
let scale = if lum.is_empty() {
@@ -113,28 +175,80 @@ pub fn encode(img: &Rgb32f, tone: Option<&CameraTone>) -> Result, String
LOOK_FIELD: crate::camera_preview::LOOK_VERSION,
ENC_FIELD: ENCODE_VERSION,
});
- if let Some(t) = tone {
- head["tone"] = serde_json::to_value(t).map_err(|e| e.to_string())?;
+ // The tail: the decoder facts (and the file's semantic mattes) after the JPEG, so the header
+ // stays small. `tail` records its byte count from the end of the file, so a header rewritten
+ // in place (an edited look version) keeps pointing at it.
+ let mut tail: Vec = Vec::new();
+ if let Some(i) = info {
+ if let Some(t) = &i.camera_tone {
+ head["tone"] = serde_json::to_value(t).map_err(|e| e.to_string())?;
+ }
+ let matte_list: Vec = i
+ .mattes
+ .as_deref()
+ .map(|m| m.iter().map(|(kind, a)| StoredMatte { kind: kind.code(), w: a.width, h: a.height, len: a.data.len() }).collect())
+ .unwrap_or_default();
+ let facts = SmartFacts {
+ raw: i.raw,
+ as_shot_temp: i.as_shot_temp,
+ as_shot_tint: i.as_shot_tint,
+ relative_wb: i.relative_wb,
+ legacy_relative_wb: i.legacy_relative_wb,
+ lens: i.lens,
+ camera_color: i.camera_color.as_deref().cloned(),
+ local_tone: i.local_tone.as_deref().cloned(),
+ mattes: matte_list,
+ };
+ let facts = serde_json::to_vec(&facts).map_err(|e| e.to_string())?;
+ let n = u32::try_from(facts.len()).map_err(|_| "smart preview facts too large")?;
+ tail.extend_from_slice(&n.to_le_bytes());
+ tail.extend_from_slice(&facts);
+ if let Some(m) = i.mattes.as_deref() {
+ for (_, a) in m.iter() {
+ tail.extend_from_slice(&a.data);
+ }
+ }
+ head["tail"] = serde_json::json!(tail.len());
}
out.extend_from_slice(head.to_string().as_bytes());
out.push(b'\n');
out.extend_from_slice(&jpg);
+ out.extend_from_slice(&tail);
Ok(out)
}
-/// Decode a smart preview back into a source image and its stored camera tone curve (an invalid
-/// curve is ignored, like a missing one).
-pub fn decode(bytes: &[u8]) -> Result<(Rgb32f, Option), String> {
+/// Decode a smart preview back into a source image, its stored camera tone curve and the stored
+/// decoder facts (an invalid curve or tail is ignored, like a missing one).
+pub fn decode(bytes: &[u8]) -> Result<(Rgb32f, Option, Option), String> {
let rest = bytes.strip_prefix(MAGIC).ok_or("not a smart preview")?;
let nl = rest.iter().position(|b| *b == b'\n').ok_or("bad smart preview")?;
let head: serde_json::Value = serde_json::from_slice(&rest[..nl]).map_err(|e| e.to_string())?;
let scale = head["scale"].as_f64().unwrap_or(1.0) as f32;
let tone = head.get("tone").and_then(|t| serde_json::from_value::(t.clone()).ok());
- let d = lightcraft_codecs::decode(&rest[nl + 1..], Default::default()).map_err(|e| e.to_string())?;
+ let tail = head.get("tail").and_then(serde_json::Value::as_u64).and_then(|t| usize::try_from(t).ok()).unwrap_or(0);
+ let start = MAGIC.len() + nl + 1;
+ let end = bytes.len().saturating_sub(tail);
+ if end <= start {
+ return Err("bad smart preview".into());
+ }
+ let d = lightcraft_codecs::decode(bytes.get(start..end).ok_or("bad smart preview")?, Default::default()).map_err(|e| e.to_string())?;
// the decoder undoes the sRGB encoding; the values are the source's own primaries
let mut img = d.image;
img.data.iter_mut().for_each(|c| *c = c.map(|v| v * scale));
- Ok((img, tone))
+ let info = stored_facts(&head, bytes).map(|(f, mattes)| SourceInfo {
+ raw: f.raw,
+ as_shot_temp: f.as_shot_temp,
+ as_shot_tint: f.as_shot_tint,
+ relative_wb: f.relative_wb,
+ legacy_relative_wb: f.legacy_relative_wb,
+ lens: f.lens,
+ camera_color: f.camera_color.map(Arc::new),
+ camera_tone: tone,
+ mattes: (!mattes.is_empty()).then(|| Arc::new(mattes)),
+ local_tone: f.local_tone.map(Arc::new),
+ native_long: None,
+ });
+ Ok((img, tone, info))
}
/// Where a library keeps its smart previews.
@@ -276,15 +390,26 @@ pub fn is_valid(path: &Path) -> bool {
}
let Some(rest) = head.strip_prefix(MAGIC) else { return false };
let Some(nl) = rest.iter().position(|b| *b == b'\n') else { return false };
- let size_ok = rest
- .get(..nl)
- .and_then(|h| serde_json::from_slice::(h).ok())
- .is_some_and(|h| h["w"].as_u64().is_some_and(|w| w > 0) && h["h"].as_u64().is_some_and(|h| h > 0));
+ let json = rest.get(..nl).and_then(|h| serde_json::from_slice::(h).ok());
+ let size_ok = json.as_ref().is_some_and(|h| h["w"].as_u64().is_some_and(|w| w > 0) && h["h"].as_u64().is_some_and(|h| h > 0));
if !size_ok || rest.get(nl + 1..nl + 3) != Some(&[0xFF, 0xD8][..]) {
return false;
}
+ let tail = json.and_then(|h| h.get("tail").and_then(serde_json::Value::as_u64)).and_then(|t| usize::try_from(t).ok()).unwrap_or(0);
+ if tail == 0 {
+ // no tail: the file ends at the JPEG's end marker
+ let mut end = [0u8; 2];
+ return f.seek(SeekFrom::End(-2)).is_ok() && f.read_exact(&mut end).is_ok() && end == [0xFF, 0xD9];
+ }
+ // with a tail, the JPEG must end right before it and the tail must be there in full
+ let Ok(meta) = f.metadata() else { return false };
+ let Ok(file_len) = usize::try_from(meta.len()) else { return false };
+ let Some(jpeg_end) = file_len.checked_sub(tail) else { return false };
+ if jpeg_end <= MAGIC.len() + nl + 3 {
+ return false;
+ }
let mut end = [0u8; 2];
- f.seek(SeekFrom::End(-2)).is_ok() && f.read_exact(&mut end).is_ok() && end == [0xFF, 0xD9]
+ f.seek(SeekFrom::Start((jpeg_end - 2) as u64)).is_ok() && f.read_exact(&mut end).is_ok() && end == [0xFF, 0xD9]
}
/// The fit version a header records: a missing, negative, fractional or otherwise malformed value
@@ -299,12 +424,15 @@ fn header_encode_version(head: &serde_json::Value) -> u64 {
head.get(ENC_FIELD).and_then(serde_json::Value::as_u64).unwrap_or(0)
}
-/// Whether the complete proxy at `path` is out of date for this build: written by an older
-/// camera-look fit than this build's (so its stored curve, and the colour baked into its pixels, are
-/// out of date), or by an older encoding of its own pixels ([`ENCODE_VERSION`], i.e. a lower JPEG
-/// quality). A proxy from a newer build is left alone (rebuilding it here would only undo that
-/// build's work), as is one that can't be read: those are [`is_valid`]'s business.
-pub fn is_stale(path: &Path) -> bool {
+/// Whether the complete proxy at `path` is out of date for a photo and must be rebuilt: written by
+/// an older encoding of its own pixels ([`ENCODE_VERSION`], i.e. a lower JPEG quality) — this
+/// reaches every proxy — or, when the photo takes the per-file camera look (`look`,
+/// [`lightcraft_catalog::Photo::fitted_look`]), by an older camera-look fit than this build's (so
+/// its stored curve, and the colour baked into its pixels, are out of date; the fit only reaches
+/// those raws, so a JPEG's or DNG's proxy is never stale for it). A proxy from a newer build is
+/// left alone (rebuilding it here would only undo that build's work), as is one that can't be
+/// read: those are [`is_valid`]'s business.
+pub fn is_stale_for(path: &Path, look: bool) -> bool {
use std::io::Read;
if !is_valid(path) {
return false;
@@ -316,9 +444,14 @@ pub fn is_stale(path: &Path) -> bool {
}
let Some(rest) = head.strip_prefix(MAGIC) else { return false };
let Some(nl) = rest.iter().position(|b| *b == b'\n') else { return false };
- rest.get(..nl)
- .and_then(|h| serde_json::from_slice::(h).ok())
- .is_some_and(|h| header_look_version(&h) < u64::from(crate::camera_preview::LOOK_VERSION) || header_encode_version(&h) < ENCODE_VERSION)
+ rest.get(..nl).and_then(|h| serde_json::from_slice::(h).ok()).is_some_and(|h| {
+ header_encode_version(&h) < ENCODE_VERSION || (look && header_look_version(&h) < u64::from(crate::camera_preview::LOOK_VERSION))
+ })
+}
+
+/// [`is_stale_for`] for a photo that takes the per-file camera look: both conditions apply.
+pub fn is_stale(path: &Path) -> bool {
+ is_stale_for(path, true)
}
/// The marker file in a smart previews folder: the camera-look fit version and encode version its
@@ -356,7 +489,14 @@ pub fn mark_look_checked(dir: &Path) -> Result<(), String> {
/// Load the proxy at `path`.
pub fn load(path: &Path) -> Result {
let b = std::fs::read(path).map_err(|e| format!("{}: {e}", path.display()))?;
- decode(&b).map(|(image, camera_tone)| crate::media::DecodedSource { image: Arc::new(image), info: None, camera_tone, denoised: None })
+ decode(&b).map(|(image, camera_tone, info)| crate::media::DecodedSource {
+ image: Arc::new(image),
+ info,
+ camera_tone,
+ denoised: None,
+ from_proxy: true,
+ reduced: false,
+ })
}
#[cfg(test)]
@@ -453,7 +593,8 @@ mod tests {
}))
.unwrap();
let img = lightcraft_scenes::demo_library()[0].render(64, 40);
- let bytes = encode(&img, Some(&tone)).unwrap();
+ let info = lightcraft_pipeline::SourceInfo { raw: true, camera_tone: Some(tone), ..Default::default() };
+ let bytes = encode(&img, Some(&info)).unwrap();
assert_eq!(decode(&bytes).unwrap().1, Some(tone));
let dir = temp("tone");
let path = dir.join("t.lcsp");
@@ -473,15 +614,50 @@ mod tests {
let mut hostile = MAGIC.to_vec();
hostile.extend_from_slice(head.to_string().as_bytes());
hostile.extend_from_slice(&bytes[nl..]);
- let (pixels, tone) = decode(&hostile).unwrap();
+ let (pixels, tone, _) = decode(&hostile).unwrap();
assert_eq!((pixels.width, tone), (img.width, None));
let _ = std::fs::remove_dir_all(&dir);
}
+ #[test]
+ fn facts_and_mattes_travel_with_the_proxy() {
+ let img = lightcraft_scenes::demo_library()[0].render(32, 20);
+ let mut mattes = Mattes::default();
+ mattes.push(MatteKind::Sky, Image { width: 16, height: 10, data: vec![255; 160] });
+ let info = SourceInfo {
+ raw: true,
+ as_shot_temp: 4200.0,
+ as_shot_tint: -5.0,
+ legacy_relative_wb: true,
+ mattes: Some(std::sync::Arc::new(mattes)),
+ ..Default::default()
+ };
+ let bytes = encode(&img, Some(&info)).unwrap();
+ let (_, _, back) = decode(&bytes).unwrap();
+ let back = back.expect("the facts are read back");
+ assert_eq!((back.as_shot_temp, back.as_shot_tint, back.legacy_relative_wb), (4200.0, -5.0, true));
+ assert_eq!(back.mattes.expect("the mattes are read back").bytes(), 160);
+ // a proxy cut inside its tail is incomplete (rebuilt, not taken for a source of facts)
+ let dir = temp("facts");
+ let path = dir.join("f.lcsp");
+ std::fs::write(&path, &bytes[..bytes.len() - 8]).unwrap();
+ assert!(!is_valid(&path));
+ let _ = std::fs::remove_dir_all(&dir);
+ // an old proxy (no tail) has no facts, and neither has one with a malformed tail
+ assert!(decode(&encode(&img, None).unwrap()).unwrap().2.is_none());
+ let nl = MAGIC.len() + bytes[MAGIC.len()..].iter().position(|b| *b == b'\n').unwrap();
+ let mut head: serde_json::Value = serde_json::from_slice(&bytes[MAGIC.len()..nl]).unwrap();
+ head["tail"] = serde_json::json!(bytes.len());
+ let mut lying = MAGIC.to_vec();
+ lying.extend_from_slice(head.to_string().as_bytes());
+ lying.extend_from_slice(&bytes[nl..]);
+ assert!(decode(&lying).map(|(_, _, i)| i.is_none()).unwrap_or(true), "an over-large tail is not trusted");
+ }
+
#[test]
fn roundtrip_keeps_the_picture() {
let img = lightcraft_scenes::demo_library()[0].render(160, 100);
- let (back, tone) = decode(&encode(&img, None).unwrap()).unwrap();
+ let (back, tone, _) = decode(&encode(&img, None).unwrap()).unwrap();
assert_eq!((back.width, back.height), (img.width, img.height));
assert!(tone.is_none());
let mut err = 0.0f64;
diff --git a/crates/engine/src/sync.rs b/crates/engine/src/sync.rs
index 6f236796e..713c697a7 100644
--- a/crates/engine/src/sync.rs
+++ b/crates/engine/src/sync.rs
@@ -34,8 +34,8 @@
//! - a sidecar is found as Read Metadata from File finds it, including the other naming
//! scheme's file (`IMG_1.xmp` for `IMG_1.JPG` beside `IMG_1.CR3`).
//!
-//! The walk for new files stops at the import's limits on depth and entries (logged), and is
-//! not cancelled midway.
+//! The walk for new files stops at the import's limits on depth and entries (logged), or when the
+//! scan is cancelled.
use std::collections::HashMap;
use std::path::{Path, PathBuf};
@@ -52,13 +52,19 @@ use crate::{EngineError, Result, Session};
/// The largest XMP sidecar read when looking for metadata updates; a bigger one is skipped.
const MAX_SIDECAR_BYTES: u64 = 16 * 1024 * 1024;
-/// How far a scan is: the folder's files probed ([`ScanProgress`], whose `cancel` stops the
-/// whole scan) and the library's photos checked.
+/// How far a scan is: the folders and files listed so far (the walk, which comes first and on a
+/// network share can take minutes), the folder's files probed ([`ScanProgress`], whose `cancel`
+/// stops the whole scan, walk included) and the library's photos checked.
#[derive(Default)]
pub struct SyncProgress {
pub files: ScanProgress,
pub checked: std::sync::atomic::AtomicUsize,
pub to_check: std::sync::atomic::AtomicUsize,
+ /// Folders and files (photos or not) the walk has listed.
+ pub folders_listed: std::sync::atomic::AtomicUsize,
+ pub files_listed: std::sync::atomic::AtomicUsize,
+ /// The walk is over (or there was nothing to walk).
+ pub listed: std::sync::atomic::AtomicBool,
}
impl SyncProgress {
@@ -68,6 +74,15 @@ impl SyncProgress {
let done = self.files.done.load(Relaxed).saturating_add(self.checked.load(Relaxed));
(done, self.files.total.load(Relaxed).saturating_add(self.to_check.load(Relaxed)))
}
+
+ /// While a scan lists the folder (before any file can be checked): the folders and files
+ /// listed so far. `None` once the listing is over.
+ pub fn listing(&self) -> Option<(usize, usize)> {
+ use std::sync::atomic::Ordering::{Acquire, Relaxed};
+ // (Acquire pairs with the Release store of `listed`: once the listing is seen to be
+ // over, so is what was stored before it, and the counts that follow are the final ones)
+ (!self.listed.load(Acquire)).then(|| (self.folders_listed.load(Relaxed), self.files_listed.load(Relaxed)))
+ }
}
/// What a scan of a folder needs, taken from the session so it can run on a worker thread.
@@ -196,6 +211,7 @@ pub fn scan_with(input: SyncInput, progress: &SyncProgress) -> FolderChanges {
let SyncInput { folder, scan, ids, naming, labels } = input;
let seen: Vec> = ids.iter().filter_map(|id| labels.photo(*id)).map(Arc::clone).collect();
if !cfg!(target_arch = "wasm32") && !Path::new(&folder).is_dir() {
+ progress.listed.store(true, std::sync::atomic::Ordering::Release);
return FolderChanges { path: folder, seen, offline: true, ..Default::default() };
}
// (how each photo's sidecar is named: a pass over the library, made here and not while the
@@ -207,15 +223,30 @@ pub fn scan_with(input: SyncInput, progress: &SyncProgress) -> FolderChanges {
// network share that is one request for a folder's names where it was several for each
// photo. Then both halves wait on the disk at once: the new files are probed (on their own
// threads) beside the checks of the photos, which ask the disk only what the listing can't say.
- // (how many photos there are to check is known before the walk: the count shows while it runs)
+ // (how many photos there are to check is known before the walk; while the walk runs, the
+ // folders and files it listed tell how far it is)
progress.to_check.store(photos.len(), std::sync::atomic::Ordering::Relaxed);
let mut listing = Listing::default();
let (files, _) = crate::import::expand_noting(
std::slice::from_ref(&folder),
scan.skip(),
crate::walk::Limits::default(),
- Some(&mut |dir, names, complete| listing.note(dir, names, complete)),
+ Some(&mut |dir, names, complete| {
+ use std::sync::atomic::Ordering::Relaxed;
+ progress.folders_listed.fetch_add(1, Relaxed);
+ let files = names.iter().filter(|(_, kind)| *kind == crate::walk::EntryKind::File).count();
+ progress.files_listed.fetch_add(files, Relaxed);
+ listing.note(dir, names, complete);
+ // ✕ stops the walk too (a cancelled scan's result is not used)
+ !progress.files.cancel.load(Relaxed)
+ }),
);
+ progress.listed.store(true, std::sync::atomic::Ordering::Release);
+ // ✕ during the listing: its result is not used, so nothing more is asked of the disk (the files' cached probes
+ // would each be checked against the file, a round trip per file on a network share)
+ if progress.files.cancel.load(std::sync::atomic::Ordering::Relaxed) {
+ return FolderChanges { path: folder, seen, ..Default::default() };
+ }
let listing = &listing;
// (no threads on the web: one after the other there)
#[cfg(target_arch = "wasm32")]
diff --git a/crates/engine/src/sync/tests_listing.rs b/crates/engine/src/sync/tests_listing.rs
index d4664dd15..4348ca830 100644
--- a/crates/engine/src/sync/tests_listing.rs
+++ b/crates/engine/src/sync/tests_listing.rs
@@ -146,8 +146,10 @@ fn a_check_from_the_listing_is_the_check_from_the_disk() {
.collect();
// (`dir.jpg` is gone, though a sidecar of its name is there)
let mut l = Listing::default();
- let walked =
- crate::walk::files_in_noting(&dir, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| l.note(d, names, complete));
+ let walked = crate::walk::files_in_noting(&dir, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| {
+ l.note(d, names, complete);
+ true
+ });
assert_eq!(walked.files.len(), 12);
let nothing = Listing::default();
for naming in [SidecarNaming::Stem, SidecarNaming::Full] {
@@ -167,7 +169,10 @@ fn a_check_from_the_listing_is_the_check_from_the_disk() {
l.asked.load(std::sync::atomic::Ordering::Relaxed)
};
let mut with = Listing::default();
- crate::walk::files_in_noting(&dir, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| with.note(d, names, complete));
+ crate::walk::files_in_noting(&dir, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| {
+ with.note(d, names, complete);
+ true
+ });
let (with, without) = (asked(&with), asked(&Listing::default()));
// (without: each photo's file, and the names of its sidecar up to the one that is there: 20 questions where
// names are found in any case, 21 where they are not)
@@ -181,7 +186,10 @@ fn a_check_from_the_listing_is_the_check_from_the_disk() {
// a folder of plain names only: the disk is asked nothing at all
let sub = dir.join("sub");
let mut only_plain = Listing::default();
- crate::walk::files_in_noting(&sub, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| only_plain.note(d, names, complete));
+ crate::walk::files_in_noting(&sub, None, crate::walk::Limits::default(), |_| true, &mut |d, names, complete| {
+ only_plain.note(d, names, complete);
+ true
+ });
let mut c2 = Catalog::new();
for (name, expected) in [("deep.jpg", Check::News), ("gone.jpg", Check::Missing), ("gone.jpg.xmp", Check::Missing)] {
let p = photo(&mut c2, &sub.join(name));
diff --git a/crates/engine/src/tests.rs b/crates/engine/src/tests.rs
index 400135ce0..1e8f4b7e3 100644
--- a/crates/engine/src/tests.rs
+++ b/crates/engine/src/tests.rs
@@ -519,7 +519,7 @@ fn paste_selected_settings_pastes_only_chosen_copied_groups() {
assert_eq!(s.develop_of(ids[1]).unwrap().color.vibrance, 30.0);
}
-/// A crop of no size (or a hair wide), as `crop.set` or a sidecar can set it, made the render's
+/// A crop of no size (or a hair wide), as a sidecar can set it, made the render's
/// samplers read at infinite coordinates and its blurs ask for sigmas of millions of pixels: with a
/// healing spot and masks on, render workers panicked (an i32 square in the blur, a bilinear
/// neighbour past isize::MAX). Such a photo renders, quickly.
@@ -533,7 +533,7 @@ fn degenerate_crops_render_with_spots_and_masks() {
s.execute("mask.add", &json!({"kind": "linear"})).unwrap();
s.execute("develop.set", &json!({"control": "effects.clarity", "value": 80})).unwrap();
s.execute("develop.set", &json!({"control": "effects.dehaze", "value": 50})).unwrap();
- s.execute("crop.set", &json!({"rect": rect, "angle": 30})).unwrap();
+ set_crop_unchecked(&mut s, rect, 30.0);
let t = std::time::Instant::now();
let r = s.render_now(id, 700, 450).unwrap();
assert!(r.image.width >= 1 && r.image.height >= 1, "{rect:?}");
@@ -541,13 +541,23 @@ fn degenerate_crops_render_with_spots_and_masks() {
}
}
+/// Store a crop as a sidecar can, without `crop.set`'s minimum size, kept inside the turned photo.
+fn set_crop_unchecked(s: &mut Session, [x0, y0, x1, y1]: [f64; 4], angle: f64) {
+ let id = s.active().unwrap();
+ let p = s.catalog.photo(id).unwrap();
+ let (w, h) = (p.width as f64, p.height as f64);
+ let mut d = active_dev(s);
+ d.crop.geometry = lightcraft_geom::CropGeometry { rect: lightcraft_geom::Rect::new(x0, y0, x1, y1), angle }.constrained(w, h);
+ s.set_develop(id, d, "Crop").unwrap();
+}
+
/// `crop.rotateAspect` on a crop of no size took its aspect from 0/0 = NaN and stored a NaN crop
/// rectangle; it now falls back to the image's own aspect, a finite crop inside the image.
#[test]
fn rotate_aspect_of_degenerate_crop_stays_finite() {
for rect in [[0.5, 0.5, 0.5, 0.5], [0.2, 0.2, 0.2, 0.8], [0.2, 0.2, 0.8, 0.2]] {
let mut s = demo();
- s.execute("crop.set", &json!({"rect": rect})).unwrap();
+ set_crop_unchecked(&mut s, rect, 0.0);
s.execute("crop.rotateAspect", &json!({})).unwrap();
let r = active_dev(&s).crop.geometry.rect;
assert!([r.x0, r.y0, r.x1, r.y1].iter().all(|v| v.is_finite()), "{rect:?}: {r:?}");
@@ -556,17 +566,36 @@ fn rotate_aspect_of_degenerate_crop_stays_finite() {
}
}
-/// `crop.set` with a huge rect shrank it by a scale of 0 (`inf * 0`) and stored a NaN crop.
+/// `crop.set` with a huge rect shrank it by a scale of 0 (`inf * 0`) and stored a NaN crop. Their
+/// maths overflow, so they fall back to a full-size crop and pass the minimum size.
#[test]
fn crop_set_huge_rect_stays_finite() {
for rect in [[0.0, 0.0, 1e308, 1e308], [-1e308, -1e308, 1e308, 1e308]] {
let mut s = demo();
- let _ = s.execute("crop.set", &json!({"rect": rect}));
+ s.execute("crop.set", &json!({"rect": rect})).unwrap();
let r = active_dev(&s).crop.geometry.rect;
assert!([r.x0, r.y0, r.x1, r.y1].iter().all(|v| v.is_finite() && (-1e-6..=1.0 + 1e-6).contains(v)), "{rect:?}: {r:?}");
}
}
+/// `crop.set` took a crop of no size (or a sliver), and the next export wrote a 1×1 image (#1952).
+/// It now refuses a crop smaller than a drag of the crop tool can make, and keeps the one it had.
+/// A rect far wider than the photo is a sliver too once it is shrunk to fit inside it.
+#[test]
+fn crop_set_refuses_a_crop_smaller_than_the_tool_allows() {
+ let mut s = demo();
+ s.execute("crop.set", &json!({"rect": [0.1, 0.1, 0.9, 0.9]})).unwrap();
+ let before = active_dev(&s).crop.geometry;
+ for rect in [[0.5, 0.5, 0.5, 0.5], [0.2, 0.2, 0.2, 0.8], [0.2, 0.4, 0.8, 0.4], [0.0, 0.0, 1e-9, 1.0], [0.0, 0.0, 1e6, 1.0], [0.0, 0.0, 1.0, 1e6]]
+ {
+ let e = s.execute("crop.set", &json!({"rect": rect})).unwrap_err();
+ assert!(e.to_string().contains("smaller"), "{rect:?}: {e}");
+ assert_eq!(active_dev(&s).crop.geometry, before, "{rect:?}");
+ }
+ s.execute("crop.set", &json!({"rect": [0.45, 0.45, 0.55, 0.55]})).unwrap();
+ assert_eq!(active_dev(&s).crop.geometry.rect, lightcraft_geom::Rect::new(0.45, 0.45, 0.55, 0.55));
+}
+
/// `mask.move` with a delta near `i64::MAX` overflowed `index + delta` (a panic wherever overflow
/// checks are on); extreme deltas and indices now move the mask to the bottom or the top.
#[test]
@@ -917,6 +946,119 @@ fn auto_sync_carries_only_the_changed_settings() {
assert_eq!(s.develop_of(PhotoId(ids[1])).unwrap().light.exposure, 0.7);
}
+#[test]
+fn auto_sync_camera_local_tone_off_preserves_other_settings() {
+ use lightcraft_catalog::PhotoId;
+ let mut s = demo();
+ let ids: Vec = s.catalog.photos().take(3).map(|p| p.id.0).collect();
+ for (id, (profile, amount, contrast)) in ids.iter().zip([("lc.color", 100, 0), ("lc.vivid", 37, 25), ("lc.mono", 63, -20)]) {
+ s.execute("library.select", &json!({"ids": [id]})).unwrap();
+ let settings = json!({"profile": {"id": profile, "amount": amount}, "light": {"contrast": contrast}});
+ s.execute("develop.merge", &json!({"settings": settings})).unwrap();
+ }
+ let initial: Vec<_> = ids.iter().map(|id| (*s.develop_of(PhotoId(*id)).unwrap()).clone()).collect();
+ assert!(initial.iter().all(|d| !d.profile.camera_local_tone));
+ s.execute("library.select", &json!({"ids": [ids[0], ids[1]], "active": ids[0]})).unwrap();
+ s.execute("develop.autoSync", &json!({"on": true})).unwrap();
+ let on = json!({"settings": {"profile": {"camera_local_tone": true}}, "label": "Camera Local Tone Mapping"});
+ let off = json!({"settings": {"profile": {"camera_local_tone": false}}, "label": "Camera Local Tone Mapping"});
+
+ // Positive control: On reaches both selected photos, changing only this setting.
+ s.execute("develop.merge", &on).unwrap();
+ let mut synced = initial.clone();
+ for d in synced.iter_mut().take(2) {
+ d.profile.camera_local_tone = true;
+ }
+ for (id, expected) in ids.iter().zip(&synced) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), expected, "On: photo {id}");
+ }
+
+ let undo_before = s.undo.len();
+ let history_before: Vec<_> = ids.iter().map(|id| s.catalog.photo(PhotoId(*id)).unwrap().history.len()).collect();
+ s.execute("develop.merge", &off).unwrap();
+ assert!(!s.develop_of(PhotoId(ids[0])).unwrap().profile.camera_local_tone);
+ assert!(!s.develop_of(PhotoId(ids[1])).unwrap().profile.camera_local_tone, "Auto Sync must carry camera local tone Off");
+ assert_eq!(s.undo.len(), undo_before + 1, "Off is one undoable edit");
+ for (i, (id, expected)) in ids.iter().zip(&initial).enumerate() {
+ let photo = s.catalog.photo(PhotoId(*id)).unwrap();
+ assert_eq!(photo.develop.as_ref(), expected, "Off: photo {id}");
+ assert_eq!(photo.history.len(), history_before[i] + usize::from(i < 2), "Off history: photo {id}");
+ let stored = photo.develop.to_json();
+ assert!(stored["profile"].get("camera_local_tone").is_none(), "false stays omitted: photo {id}");
+ assert_eq!(&lightcraft_develop::DevelopSettings::from_json(&stored).unwrap(), expected);
+ }
+
+ // One Undo/Redo restores the complete settings of both selected photos, not the third.
+ s.execute("edit.undo", &json!({})).unwrap();
+ for (id, expected) in ids.iter().zip(&synced) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), expected, "Undo: photo {id}");
+ }
+ s.execute("edit.redo", &json!({})).unwrap();
+ for (id, expected) in ids.iter().zip(&initial) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), expected, "Redo: photo {id}");
+ }
+}
+
+#[test]
+fn auto_sync_camera_local_tone_changes_only_when_edited() {
+ use lightcraft_catalog::PhotoId;
+ let mut s = demo();
+ let ids: Vec = s.catalog.photos().take(3).map(|p| p.id.0).collect();
+ s.execute("library.select", &json!({"ids": [ids[1]]})).unwrap();
+ let settings = json!({"profile": {"id": "lc.vivid", "amount": 37, "camera_local_tone": true}, "light": {"contrast": 25}});
+ s.execute("develop.merge", &json!({"settings": settings})).unwrap();
+ let mut expected: Vec<_> = ids.iter().map(|id| (*s.develop_of(PhotoId(*id)).unwrap()).clone()).collect();
+ assert!(!expected[0].profile.camera_local_tone);
+ assert!(expected[1].profile.camera_local_tone);
+ s.execute("library.select", &json!({"ids": [ids[0], ids[1]], "active": ids[0]})).unwrap();
+ s.execute("develop.autoSync", &json!({"on": true})).unwrap();
+
+ // An unrelated edit must not copy the active photo's unchanged false over the peer's true.
+ s.execute("develop.set", &json!({"control": "light.exposure", "value": 0.7})).unwrap();
+ for d in expected.iter_mut().take(2) {
+ d.light.exposure = 0.7;
+ }
+ for (id, settings) in ids.iter().zip(&expected) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), settings, "Unrelated edit: photo {id}");
+ }
+
+ let peer_history = s.catalog.photo(PhotoId(ids[1])).unwrap().history.len();
+ s.execute("develop.merge", &json!({"settings": {"profile": {"camera_local_tone": false}}})).unwrap();
+ assert_eq!(s.catalog.photo(PhotoId(ids[1])).unwrap().history.len(), peer_history, "unchanged toggle adds no peer history");
+ for (id, settings) in ids.iter().zip(&expected) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), settings, "Unchanged toggle: photo {id}");
+ }
+
+ // Direct unchanged edits may still add an active undo step. With Auto Sync off, real
+ // Boolean changes affect only the active photo; selected and unselected peers stay exact.
+ s.execute("develop.autoSync", &json!({"on": false})).unwrap();
+ for on in [true, false] {
+ s.execute("develop.merge", &json!({"settings": {"profile": {"camera_local_tone": on}}})).unwrap();
+ expected[0].profile.camera_local_tone = on;
+ for (id, settings) in ids.iter().zip(&expected) {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().as_ref(), settings, "Auto Sync disabled: photo {id}");
+ }
+ }
+}
+
+#[test]
+fn auto_sync_hdr_off_returns_selected_photos_to_sdr() {
+ use lightcraft_catalog::PhotoId;
+ let mut s = demo();
+ let ids: Vec = s.catalog.photos().take(2).map(|p| p.id.0).collect();
+ assert_eq!(ids.len(), 2);
+ for id in &ids {
+ assert_eq!(s.develop_of(PhotoId(*id)).unwrap().hdr, lightcraft_develop::Hdr::default(), "default-HDR fixture");
+ }
+ s.execute("library.select", &json!({"ids": ids, "active": ids[0]})).unwrap();
+ s.execute("develop.autoSync", &json!({"on": true})).unwrap();
+ let enabled = |s: &Session| ids.iter().map(|id| s.develop_of(PhotoId(*id)).unwrap().hdr.enabled).collect::>();
+ s.execute("develop.hdr", &json!({"enabled": true})).unwrap();
+ assert_eq!(enabled(&s), vec![true, true], "HDR On must reach both selected photos");
+ s.execute("develop.hdr", &json!({"enabled": false})).unwrap();
+ assert_eq!(enabled(&s), vec![false, false], "HDR Off must reach both selected photos");
+}
+
#[test]
fn json_delta_keeps_only_changes() {
let a = json!({"light": {"exposure": 0, "contrast": 5}, "masks": [1], "x": 1});
@@ -1682,3 +1824,46 @@ fn malformed_photo_targets_are_refused_not_widened() {
let preset = s.presets.first().unwrap().id.clone();
s.execute("preset.apply", &json!({"id": preset})).unwrap();
}
+
+#[test]
+fn auto_sync_hdr_enabled_preserves_per_photo_tuning() {
+ use lightcraft_develop::{DevelopSettings, Hdr, ProcessVersion};
+ let mut s = demo();
+ let ids: Vec<_> = s.catalog.photos().take(2).map(|p| p.id).collect();
+ assert_eq!(ids.len(), 2);
+ s.execute("develop.autoSync", &json!({"on": false})).unwrap();
+ // Keep distinct stored processes explicit: the default is now V2; no rendering claim is made.
+ let mut expected = [DevelopSettings::default(), DevelopSettings { process: ProcessVersion(2), ..DevelopSettings::default() }];
+ expected[0].process = ProcessVersion(1);
+ expected[0].light.exposure = 0.5;
+ expected[0].light.contrast = 12.0;
+ expected[1].light.exposure = -0.25;
+ expected[1].light.contrast = -22.0;
+ expected[1].hdr = Hdr {
+ enabled: false,
+ max_ev: 4.0,
+ sdr_brightness: 11.0,
+ sdr_contrast: -12.0,
+ sdr_highlights: 13.0,
+ sdr_shadows: -14.0,
+ sdr_whites: 15.0,
+ sdr_clarity: -16.0,
+ };
+ for (id, settings) in ids.iter().zip(&expected) {
+ s.set_develop(*id, settings.clone(), "HDR tuning fixture").unwrap();
+ }
+ s.execute("library.select", &json!({"ids": ids.iter().map(|id| id.0).collect::>(), "active": ids[0].0})).unwrap();
+ s.execute("develop.autoSync", &json!({"on": true})).unwrap();
+ let selection = s.selection.clone();
+ for enabled in [true, false] {
+ s.execute("develop.hdr", &json!({"enabled": enabled})).unwrap();
+ for (id, settings) in ids.iter().zip(&mut expected) {
+ settings.hdr.enabled = enabled;
+ let actual = s.develop_of(*id).unwrap();
+ assert_eq!(actual.hdr, settings.hdr, "HDR tuning must survive enabled={enabled} for photo {id:?}");
+ assert_eq!(actual.as_ref(), &*settings, "other per-photo edits and process must survive enabled={enabled}");
+ }
+ assert_eq!(s.selection, selection, "selection and active photo must survive enabled={enabled}");
+ assert!(s.auto_sync, "Auto Sync must remain enabled");
+ }
+}
diff --git a/crates/engine/src/tests_forget_local.rs b/crates/engine/src/tests_forget_local.rs
index 229b262a0..9f5d1f572 100644
--- a/crates/engine/src/tests_forget_local.rs
+++ b/crates/engine/src/tests_forget_local.rs
@@ -259,3 +259,58 @@ fn browsing_again_forgets_untouched_records_of_deleted_files() {
assert_eq!(s.catalog.to_snapshot(), expect);
let _ = std::fs::remove_dir_all(&root);
}
+
+/// Opens `lib` with a probe that counts the originals it checks.
+fn open_counting(lib: &Path, clock: &Arc>) -> (Session, Arc) {
+ let checks = Arc::new(std::sync::atomic::AtomicUsize::new(0));
+ let mut s = Session::new().with_fs();
+ let c = clock.clone();
+ s.clock = Box::new(move || c.lock().unwrap().clone());
+ let n = checks.clone();
+ s.media.availability.set_probe(Arc::new(move |p| {
+ n.fetch_add(1, std::sync::atomic::Ordering::SeqCst);
+ Path::new(p).exists()
+ }));
+ s.open_library(lib, false).unwrap();
+ (s, checks)
+}
+
+/// A library last shown on Missing Photos opens without checking its originals: that view holds
+/// no Local records, so forgetting them needn't work it out, and no photo is picked from it (each
+/// check can wait for a sleeping NAS; a big library on one froze the window for minutes).
+#[test]
+fn opening_on_missing_photos_checks_no_originals() {
+ let root = temp_dir("missing");
+ let (a, lib) = (root.join("a"), root.join("lib"));
+ for i in 0..5 {
+ png(&a.join(format!("m{i}.png")), i);
+ }
+ let clock = Arc::new(Mutex::new("2026-08-01T10:00:00".to_string()));
+ let mut s = open(&lib, &clock);
+ s.execute("library.import", &json!({"paths": [a.to_string_lossy()], "mode": "add"})).unwrap();
+ s.execute("library.source", &json!({"kind": "missing"})).unwrap();
+ // every original is there: the view is empty and nothing is selected
+ assert!(s.visible().is_empty());
+ assert!(s.selection.active.is_none());
+ s.close_library().unwrap();
+ drop(s);
+ let (s, checks) = open_counting(&lib, &clock);
+ assert_eq!(s.source, LibrarySource::Missing, "the view is restored");
+ assert_eq!(checks.load(std::sync::atomic::Ordering::SeqCst), 0, "opening an empty Missing view checked originals");
+ assert!(s.library.as_ref().unwrap().forgot_local.is_some(), "forgetting still ran");
+ drop(s);
+
+ // the originals go: the view lists them, one is active
+ std::fs::remove_dir_all(&a).unwrap();
+ let mut s = open(&lib, &clock);
+ s.execute("library.source", &json!({"kind": "all"})).unwrap();
+ s.execute("library.source", &json!({"kind": "missing"})).unwrap();
+ assert_eq!(s.visible().len(), 5, "all five are missing");
+ assert!(s.selection.active.is_some());
+ s.close_library().unwrap();
+ drop(s);
+ let (s, checks) = open_counting(&lib, &clock);
+ assert_eq!(s.source, LibrarySource::Missing);
+ assert_eq!(checks.load(std::sync::atomic::Ordering::SeqCst), 0, "opening a full Missing view checked originals");
+ let _ = std::fs::remove_dir_all(&root);
+}
diff --git a/crates/engine/src/tests_ids_params.rs b/crates/engine/src/tests_ids_params.rs
new file mode 100644
index 000000000..8ce772ded
--- /dev/null
+++ b/crates/engine/src/tests_ids_params.rs
@@ -0,0 +1,205 @@
+//! `ids` that aren't photo ids are an error, never "the selection": a command that fell back to the
+//! selection on `{"ids": 3}` acted on photos the call didn't name.
+
+use lightcraft_catalog::{AlbumId, PhotoId};
+use serde_json::{Value, json};
+
+use crate::Session;
+
+/// A demo session with the first two photos selected, the third active elsewhere in the grid, and
+/// an album holding the selection.
+fn session() -> (Session, Vec, AlbumId) {
+ let mut s = Session::with_demo();
+ let vis = s.visible_cloned();
+ s.execute("library.select", &json!({"ids": [vis[0].0, vis[1].0], "active": vis[0].0})).unwrap();
+ let r = s.execute("album.create", &json!({"name": "Trip", "addSelected": true})).unwrap();
+ let album = AlbumId(r["id"].as_u64().unwrap());
+ (s, vis.to_vec(), album)
+}
+
+const BAD_IDS: [fn() -> Value; 5] = [|| json!(3), || json!("3"), || json!(["3"]), || json!([3, -1]), || json!({"id": 3})];
+
+#[test]
+fn album_commands_refuse_ids_that_are_not_photo_ids() {
+ let (mut s, vis, album) = session();
+ let members = |s: &Session| s.catalog.album(album).unwrap().photos.clone();
+ let before = members(&s);
+ assert_eq!(before.len(), 2);
+ for bad in BAD_IDS.map(|f| f()) {
+ for cmd in ["album.removePhotos", "album.addPhotos"] {
+ let e = s.execute(cmd, &json!({"id": album.0, "ids": bad})).unwrap_err();
+ assert!(e.to_string().contains("ids"), "{cmd} {bad}: {e}");
+ assert_eq!(members(&s), before, "{cmd} {bad} changed the album");
+ }
+ assert!(s.execute("album.toggleTarget", &json!({"ids": bad})).is_err(), "album.toggleTarget {bad}");
+ }
+ // well-formed ids still work, and no ids still means the selection
+ s.execute("album.removePhotos", &json!({"id": album.0, "ids": [vis[1].0]})).unwrap();
+ assert_eq!(members(&s), vec![vis[0]]);
+ s.execute("album.addPhotos", &json!({"id": album.0, "ids": null})).unwrap();
+ assert_eq!(members(&s).len(), 2);
+}
+
+#[test]
+fn develop_set_refuses_ids_that_are_not_photo_ids() {
+ let (mut s, vis, _) = session();
+ let exposure = |s: &Session, id: PhotoId| s.develop_of(id).unwrap().light.exposure;
+ let before: Vec = vis.iter().map(|id| exposure(&s, *id)).collect();
+ for bad in BAD_IDS.map(|f| f()) {
+ let e = s.execute("develop.set", &json!({"control": "light.exposure", "value": 2.5, "ids": bad})).unwrap_err();
+ assert!(e.to_string().contains("ids"), "{bad}: {e}");
+ assert_eq!(vis.iter().map(|id| exposure(&s, *id)).collect::>(), before, "{bad} edited a photo");
+ }
+ s.execute("develop.set", &json!({"control": "light.exposure", "value": 2.5, "ids": [vis[2].0]})).unwrap();
+ assert_eq!((exposure(&s, vis[0]), exposure(&s, vis[2])), (before[0], 2.5));
+}
+
+#[test]
+fn library_select_refuses_ids_that_are_not_photo_ids() {
+ let (mut s, vis, _) = session();
+ let before = s.selection.ids.clone();
+ for bad in BAD_IDS.map(|f| f()) {
+ assert!(s.execute("library.select", &json!({"ids": bad})).is_err(), "{bad}");
+ assert_eq!(s.selection.ids, before, "{bad} changed the selection");
+ }
+ s.execute("library.select", &json!({"ids": [vis[2].0]})).unwrap();
+ assert_eq!(s.selection.ids, vec![vis[2]]);
+}
+
+/// The same for a single `id`: a value that isn't a photo id used to mean the active photo
+/// (`photo.relink` then relinked the active photo to the file, `photo.removeRegion` removed its face
+/// box), or, for `denoise.cancel`, every photo. (The stack commands share the helper; `in_stack`
+/// keeps them disabled on a photo outside a stack, so they aren't called here.)
+#[test]
+fn single_photo_commands_refuse_an_id_that_is_not_a_photo_id() {
+ let (mut s, vis, _) = session();
+ let active = s.active().unwrap();
+ let mut meta = s.catalog.photo(active).unwrap().meta.clone();
+ meta.regions = vec![lightcraft_meta::Region {
+ rect: lightcraft_geom::Rect { x0: 0.1, y0: 0.1, x1: 0.3, y1: 0.3 },
+ kind: lightcraft_meta::RegionKind::Face,
+ name: None,
+ description: None,
+ }];
+ s.commit("setup", lightcraft_catalog::Op::SetMeta { id: active, meta: Box::new(meta) }).unwrap();
+ let source = |s: &Session| format!("{:?}", s.catalog.photo(active).unwrap().source);
+ let before = source(&s);
+ let commits = s.commits();
+ for bad in [json!("5"), json!(-1), json!(1.5), json!([vis[2].0]), json!({"id": 1})] {
+ for (cmd, mut params) in [
+ ("photo.relink", json!({"path": "/elsewhere/other.jpg"})),
+ ("photo.removeRegion", json!({"index": 0})),
+ ("photo.setRegion", json!({"index": 0, "rect": {"x0": 0.2, "y0": 0.2, "x1": 0.4, "y1": 0.4}})),
+ ("faces.setName", json!({"index": 0, "name": "Ann"})),
+ ("library.findSimilar", json!({})),
+ ("denoise.cancel", json!({})),
+ ("photo.inspect", json!({})),
+ ] {
+ params["id"] = bad.clone();
+ let e = s.execute(cmd, ¶ms).unwrap_err();
+ assert!(e.to_string().contains("`id`"), "{cmd} {bad}: {e}");
+ }
+ }
+ assert_eq!(s.commits(), commits, "nothing was changed");
+ assert_eq!(source(&s), before);
+ assert_eq!(s.catalog.photo(active).unwrap().meta.regions.len(), 1);
+}
+
+/// Mask ids and spot indexes the same way: `mask.delete {"id": "1"}` deleted the selected mask, and an
+/// id past `u32` wrapped (`4294967297 as u32` is 1) onto another mask.
+#[test]
+fn mask_and_spot_commands_refuse_ids_that_are_not_ids() {
+ let (mut s, _, _) = session();
+ s.execute("mask.add", &json!({"kind": "linear"})).unwrap();
+ s.execute("mask.add", &json!({"kind": "radial"})).unwrap();
+ s.execute("spot.add", &json!({"mode": "heal", "points": [[0.4, 0.5]], "size": 0.02, "source": [0.1, 0.0]})).unwrap();
+ let state = |s: &Session| {
+ let d = s.develop_of(s.active().unwrap()).unwrap();
+ (d.masks.iter().map(|m| (m.id, m.name.clone(), m.visible)).collect::>(), d.spots.len())
+ };
+ let before = state(&s);
+ assert_eq!((before.0.len(), before.1), (2, 1));
+ let first = before.0[0].0;
+ let commits = s.commits();
+ for bad in [json!(u64::from(u32::MAX) + 1 + u64::from(first)), json!("1"), json!(-1), json!(1.5), json!([first])] {
+ for (cmd, params) in [
+ ("mask.delete", json!({})),
+ ("mask.rename", json!({"name": "renamed"})),
+ ("mask.visible", json!({"visible": false})),
+ ("mask.select", json!({})),
+ ] {
+ let mut params = params;
+ params["id"] = bad.clone();
+ assert!(s.execute(cmd, ¶ms).is_err(), "{cmd} {bad}");
+ }
+ for cmd in ["spot.delete", "spot.select"] {
+ assert!(s.execute(cmd, &json!({"index": bad})).is_err(), "{cmd} {bad}");
+ }
+ }
+ assert_eq!(s.commits(), commits, "nothing was changed");
+ assert_eq!(state(&s), before);
+ // well-formed ids and a null still work
+ s.execute("mask.delete", &json!({"id": first})).unwrap();
+ s.execute("spot.select", &json!({"index": null})).unwrap();
+ assert_eq!(state(&s).0.len(), 1);
+}
+
+/// `photo.label` without a label, or with one that isn't text, cleared the colour label of every
+/// selected photo (a missing `label` read as `none`); now it is an error and only `none` or null clear.
+#[test]
+fn photo_label_refuses_a_missing_or_non_text_label() {
+ let (mut s, vis, _) = session();
+ s.execute("photo.label", &json!({"label": "red"})).unwrap();
+ let labels = |s: &Session| vis.iter().take(2).map(|id| s.catalog.photo(*id).unwrap().label).collect::>();
+ let before = labels(&s);
+ assert!(before.iter().all(Option::is_some));
+ for params in [json!({}), json!({"label": 3}), json!({"label": true}), json!({"label": ["red"]}), json!({"label": "crimson"})] {
+ assert!(s.execute("photo.label", ¶ms).is_err(), "{params}");
+ assert_eq!(labels(&s), before, "{params} changed the labels");
+ }
+ s.execute("photo.label", &json!({"label": null})).unwrap();
+ assert!(labels(&s).iter().all(Option::is_none));
+ s.execute("photo.label", &json!({"label": "green"})).unwrap();
+ s.execute("photo.label", &json!({"label": "none"})).unwrap();
+ assert!(labels(&s).iter().all(Option::is_none));
+}
+
+/// The mask-effect commands and a mask's `component` the same way: `mask.saveEffect {"id": "2"}`
+/// saved the selected mask's sliders, and `mask.update {"component": "1"}` reshaped component 0.
+#[test]
+fn mask_effects_and_components_refuse_values_that_are_not_ids() {
+ let (mut s, _, _) = session();
+ s.execute("mask.add", &json!({"kind": "linear"})).unwrap();
+ s.execute("mask.add", &json!({"kind": "radial"})).unwrap();
+ s.execute("mask.saveEffect", &json!({"name": "Kept"})).unwrap();
+ let state = |s: &Session| (format!("{:?}", s.develop_of(s.active().unwrap()).unwrap().masks), s.mask_effects.len());
+ let before = state(&s);
+ let commits = s.commits();
+ let d = s.develop_of(s.active().unwrap()).unwrap();
+ let shape = serde_json::to_value(&d.masks.last().unwrap().components[0].shape).unwrap();
+ for bad in [json!("1"), json!(-1), json!(1.5), json!([1]), json!(u64::from(u32::MAX) + 2)] {
+ for (cmd, params) in [
+ ("mask.applyEffect", json!({"name": "Kept"})),
+ ("mask.saveEffect", json!({"name": "New"})),
+ ("mask.updateEffect", json!({"name": "Kept"})),
+ ] {
+ let mut params = params;
+ params["id"] = bad.clone();
+ let e = s.execute(cmd, ¶ms).unwrap_err();
+ assert!(e.to_string().contains("`id`"), "{cmd} {bad}: {e}");
+ }
+ if bad.is_u64() {
+ continue; // a well-formed index past the end is "no such component", not a type error
+ }
+ for (cmd, params) in
+ [("mask.update", json!({"shape": shape})), ("mask.component", json!({"action": "invert"})), ("mask.refineDetail", json!({}))]
+ {
+ let mut params = params;
+ params["component"] = bad.clone();
+ let e = s.execute(cmd, ¶ms).unwrap_err();
+ assert!(e.to_string().contains("`component`"), "{cmd} {bad}: {e}");
+ }
+ }
+ assert_eq!(s.commits(), commits, "nothing was changed");
+ assert_eq!(state(&s), before);
+}
diff --git a/crates/engine/src/tests_import.rs b/crates/engine/src/tests_import.rs
index c5ff90456..191595ebe 100644
--- a/crates/engine/src/tests_import.rs
+++ b/crates/engine/src/tests_import.rs
@@ -30,6 +30,25 @@ fn ids(v: &Value, key: &str) -> usize {
v[key].as_array().map(Vec::len).unwrap_or(0)
}
+#[test]
+fn recursive_discovery_includes_sony_sr2_and_srf_case_insensitively() {
+ let src = temp_dir("sony-discovery");
+ std::fs::create_dir_all(src.join("trip/day2")).unwrap();
+ let names = ["r1.SR2", "f828.srf", "trip/r1.sr2", "trip/f828.SRF", "trip/day2/r1.Sr2", "trip/day2/f828.SrF", "control.JPG"];
+ let mut expected: Vec = names.iter().map(|name| src.join(name).to_string_lossy().into_owned()).collect();
+ for path in &expected {
+ std::fs::write(path, b"discovery only, not a decoded photo").unwrap();
+ }
+ std::fs::write(src.join("trip/notes.txt"), b"not a photo").unwrap();
+
+ let mut found = crate::import::expand(&[src.to_string_lossy().into_owned()], None);
+ found.sort();
+ expected.sort();
+ assert_eq!(found, expected);
+ assert_eq!(crate::import::expand(&expected, None), expected, "folder and direct discovery agree");
+ std::fs::remove_dir_all(src).unwrap();
+}
+
#[test]
fn recursive_import_with_duplicates() {
let src = temp_dir("src");
@@ -479,6 +498,129 @@ fn smart_previews_stand_in_for_offline_originals() {
let _ = std::fs::remove_dir_all(&lib);
}
+/// Issue #1534: the decoder facts a render interprets its settings against (a camera colour model,
+/// the file's local tone map, its semantic mattes) must be stored with the smart preview, so an
+/// edit made while the original is offline renders the same picture as the online source instead
+/// of the header-facts fallback.
+#[test]
+fn smart_previews_keep_the_decoder_facts_offline_edits_need() {
+ use lightcraft_develop::{DevelopSettings, LocalAdjustments, Mask, MaskComponent, MaskOp, MaskShape, WbMode};
+ use lightcraft_pipeline::SourceInfo;
+ use lightcraft_pipeline::masks::{MatteKind, Mattes};
+ use lightcraft_raster::Rgb32f;
+
+ // A smooth scene: the proxy's 8-bit sRGB round trip stays within a code step, so a mismatch
+ // left between the offline and the online render is metadata the proxy failed to keep.
+ let pixels = Rgb32f::from_fn(96, 64, |x, y| {
+ let t = ((x * 7 + y * 3) % 96) as f32 / 96.0;
+ [0.02 + t * 1.2, 0.02 + t * 0.6, 0.02 + t * 0.25]
+ });
+ let camera_color = lightcraft_pipeline::CameraColor {
+ tags: lightcraft_raw::ColorData {
+ illuminant: [21, 17],
+ color_matrix: [Some(lightcraft_color::Mat3([[0.9, 0.2, -0.15], [-0.3, 1.25, 0.08], [0.02, -0.12, 0.85]])), None],
+ as_shot_neutral: Some([0.5, 1.0, 0.7]),
+ baseline_exposure: 0.3,
+ ..Default::default()
+ },
+ developed_for: lightcraft_color::Xy { x: 0.32, y: 0.35 },
+ };
+ let mut mattes = Mattes::default();
+ mattes.push(
+ MatteKind::Sky,
+ lightcraft_raster::Image { width: 96, height: 64, data: (0..96 * 64usize).map(|i| if (i % 96) / 24 == 1 { 255 } else { 0 }).collect() },
+ );
+ let local_tone = lightcraft_pipeline::local_tone::LocalTone {
+ map: lightcraft_raw::gaintable::GainTableMap {
+ points_v: 1,
+ points_h: 2,
+ points_n: 1,
+ spacing_v: 1.0,
+ spacing_h: 1.0,
+ origin_v: 0.0,
+ origin_h: 0.0,
+ weights: [1.0 / 3.0, 1.0 / 3.0, 1.0 / 3.0, 0.0, 0.0],
+ gamma: 1.0,
+ gains: vec![1.0, 4.0],
+ },
+ placement: lightcraft_raw::gaintable::SourcePlacement { rect: [0.0, 0.0, 1.0, 1.0], orientation: lightcraft_geom::Orientation::Normal },
+ };
+ // the facts differ per case; the rest is the raw source's usual shape
+ let info = |camera_color: Option,
+ local_tone: Option,
+ mattes: Option  +



 +
 +
 +


 +
 +


 | **PhotoCraft** | 影像編輯:圖層、遮色片、文字和真正的 PSD 檔案 | [GitHub](https://github.com/storytold/photocraft) | [網站](https://getartcraft.com/apps/photocraft) |
+|
 | **VectorCraft** | 向量插畫 | [GitHub](https://github.com/storytold/vectorcraft) | [網站](https://getartcraft.com/apps/vectorcraft) |
+|
 | **FilmCraft** | 影片剪輯、調色與聲音 | [GitHub](https://github.com/storytold/filmcraft) | [網站](https://getartcraft.com/apps/filmcraft) |
+|
 | **LightCraft** | **照片庫與 raw 顯影 · 你現在在這裡** | [GitHub](https://github.com/storytold/lightcraft) | [網站](https://getartcraft.com/apps/lightcraft) |
+|
 | **PdfCraft** | 閱讀、整理與保護 PDF | [GitHub](https://github.com/storytold/pdfcraft) | [網站](https://getartcraft.com/apps/pdfcraft) |
+|
 | **EffectCraft** | 動態圖形與視覺特效 | [GitHub](https://github.com/storytold/effectcraft) | [網站](https://getartcraft.com/apps/effectcraft) |
+|
 | **DesignCraft** | 版面編排與出版 | [GitHub](https://github.com/storytold/designcraft) | [網站](https://getartcraft.com/apps/designcraft) |
+
+還有 [**ArtCraft**](https://getartcraft.com/) 本身,我們為想要真正掌控創作的人打造的 AI 影像與影片工作室。
+
+
